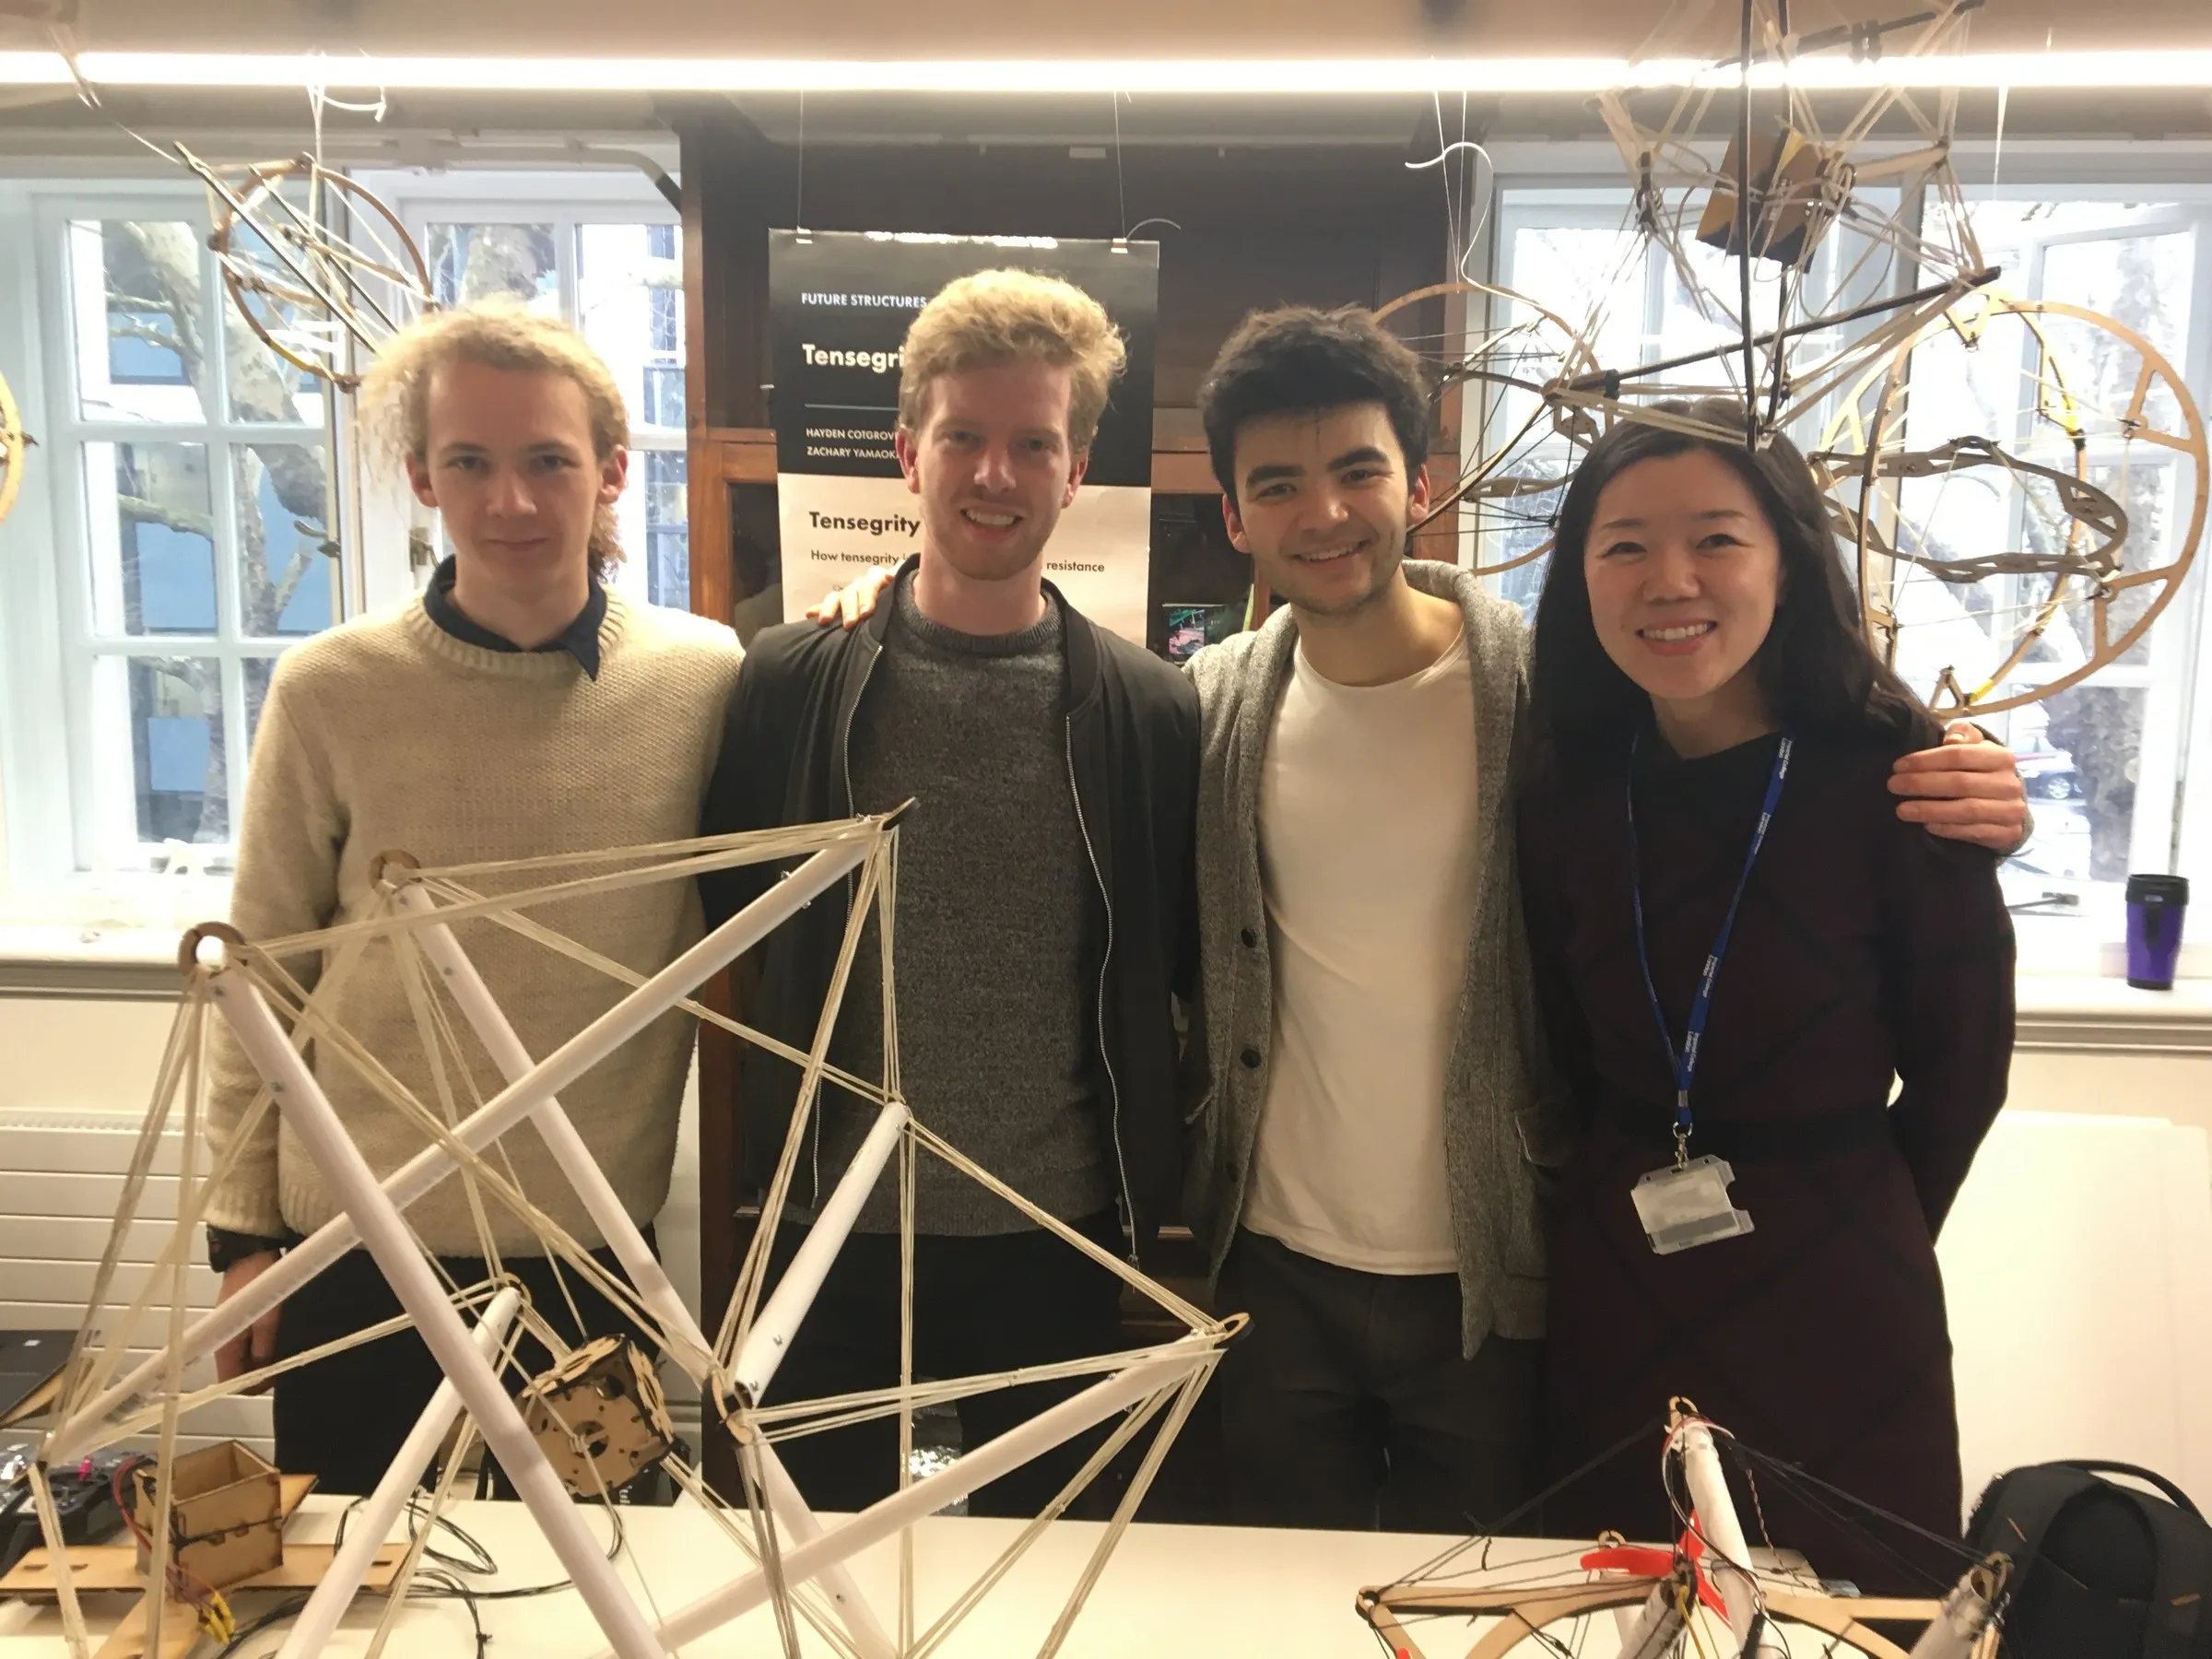
A Tensegrity Drone
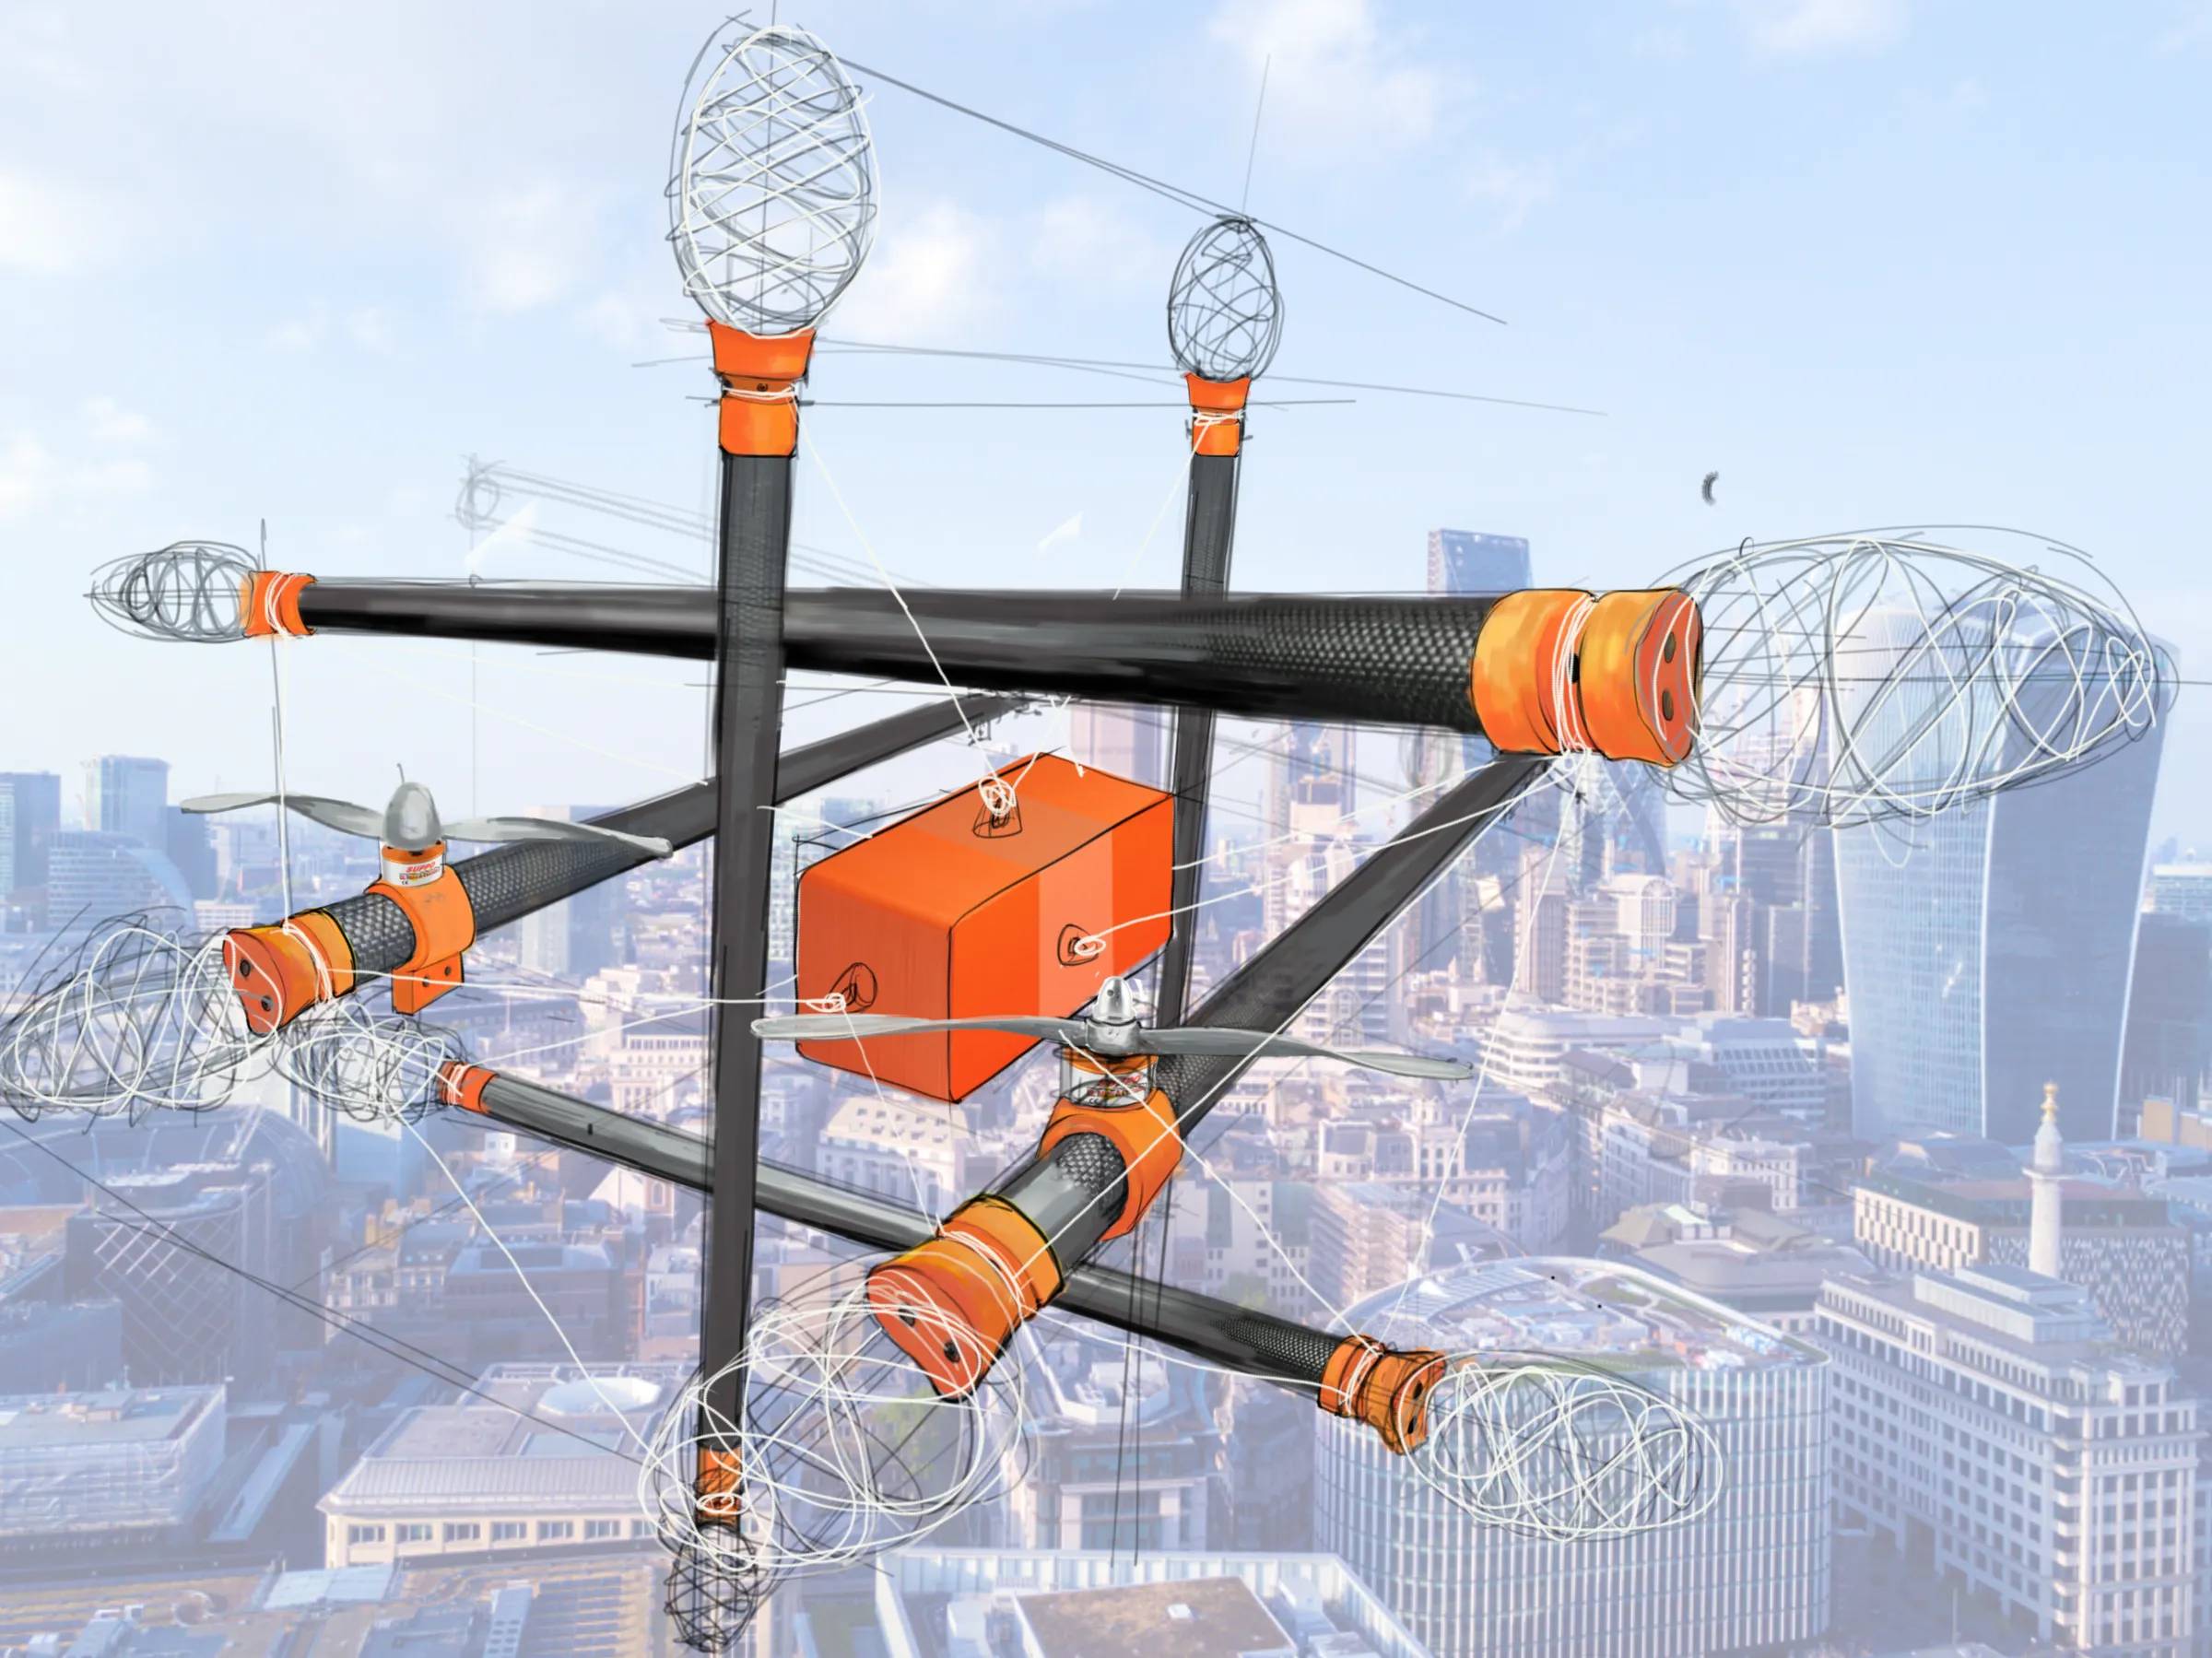
Based on analyses of the physical laws which govern collisions and research into animals that can survive massive falls (ie. cats), my team proposed a future concept for an indestructible quadcopter drone.
My contribution to this project included:
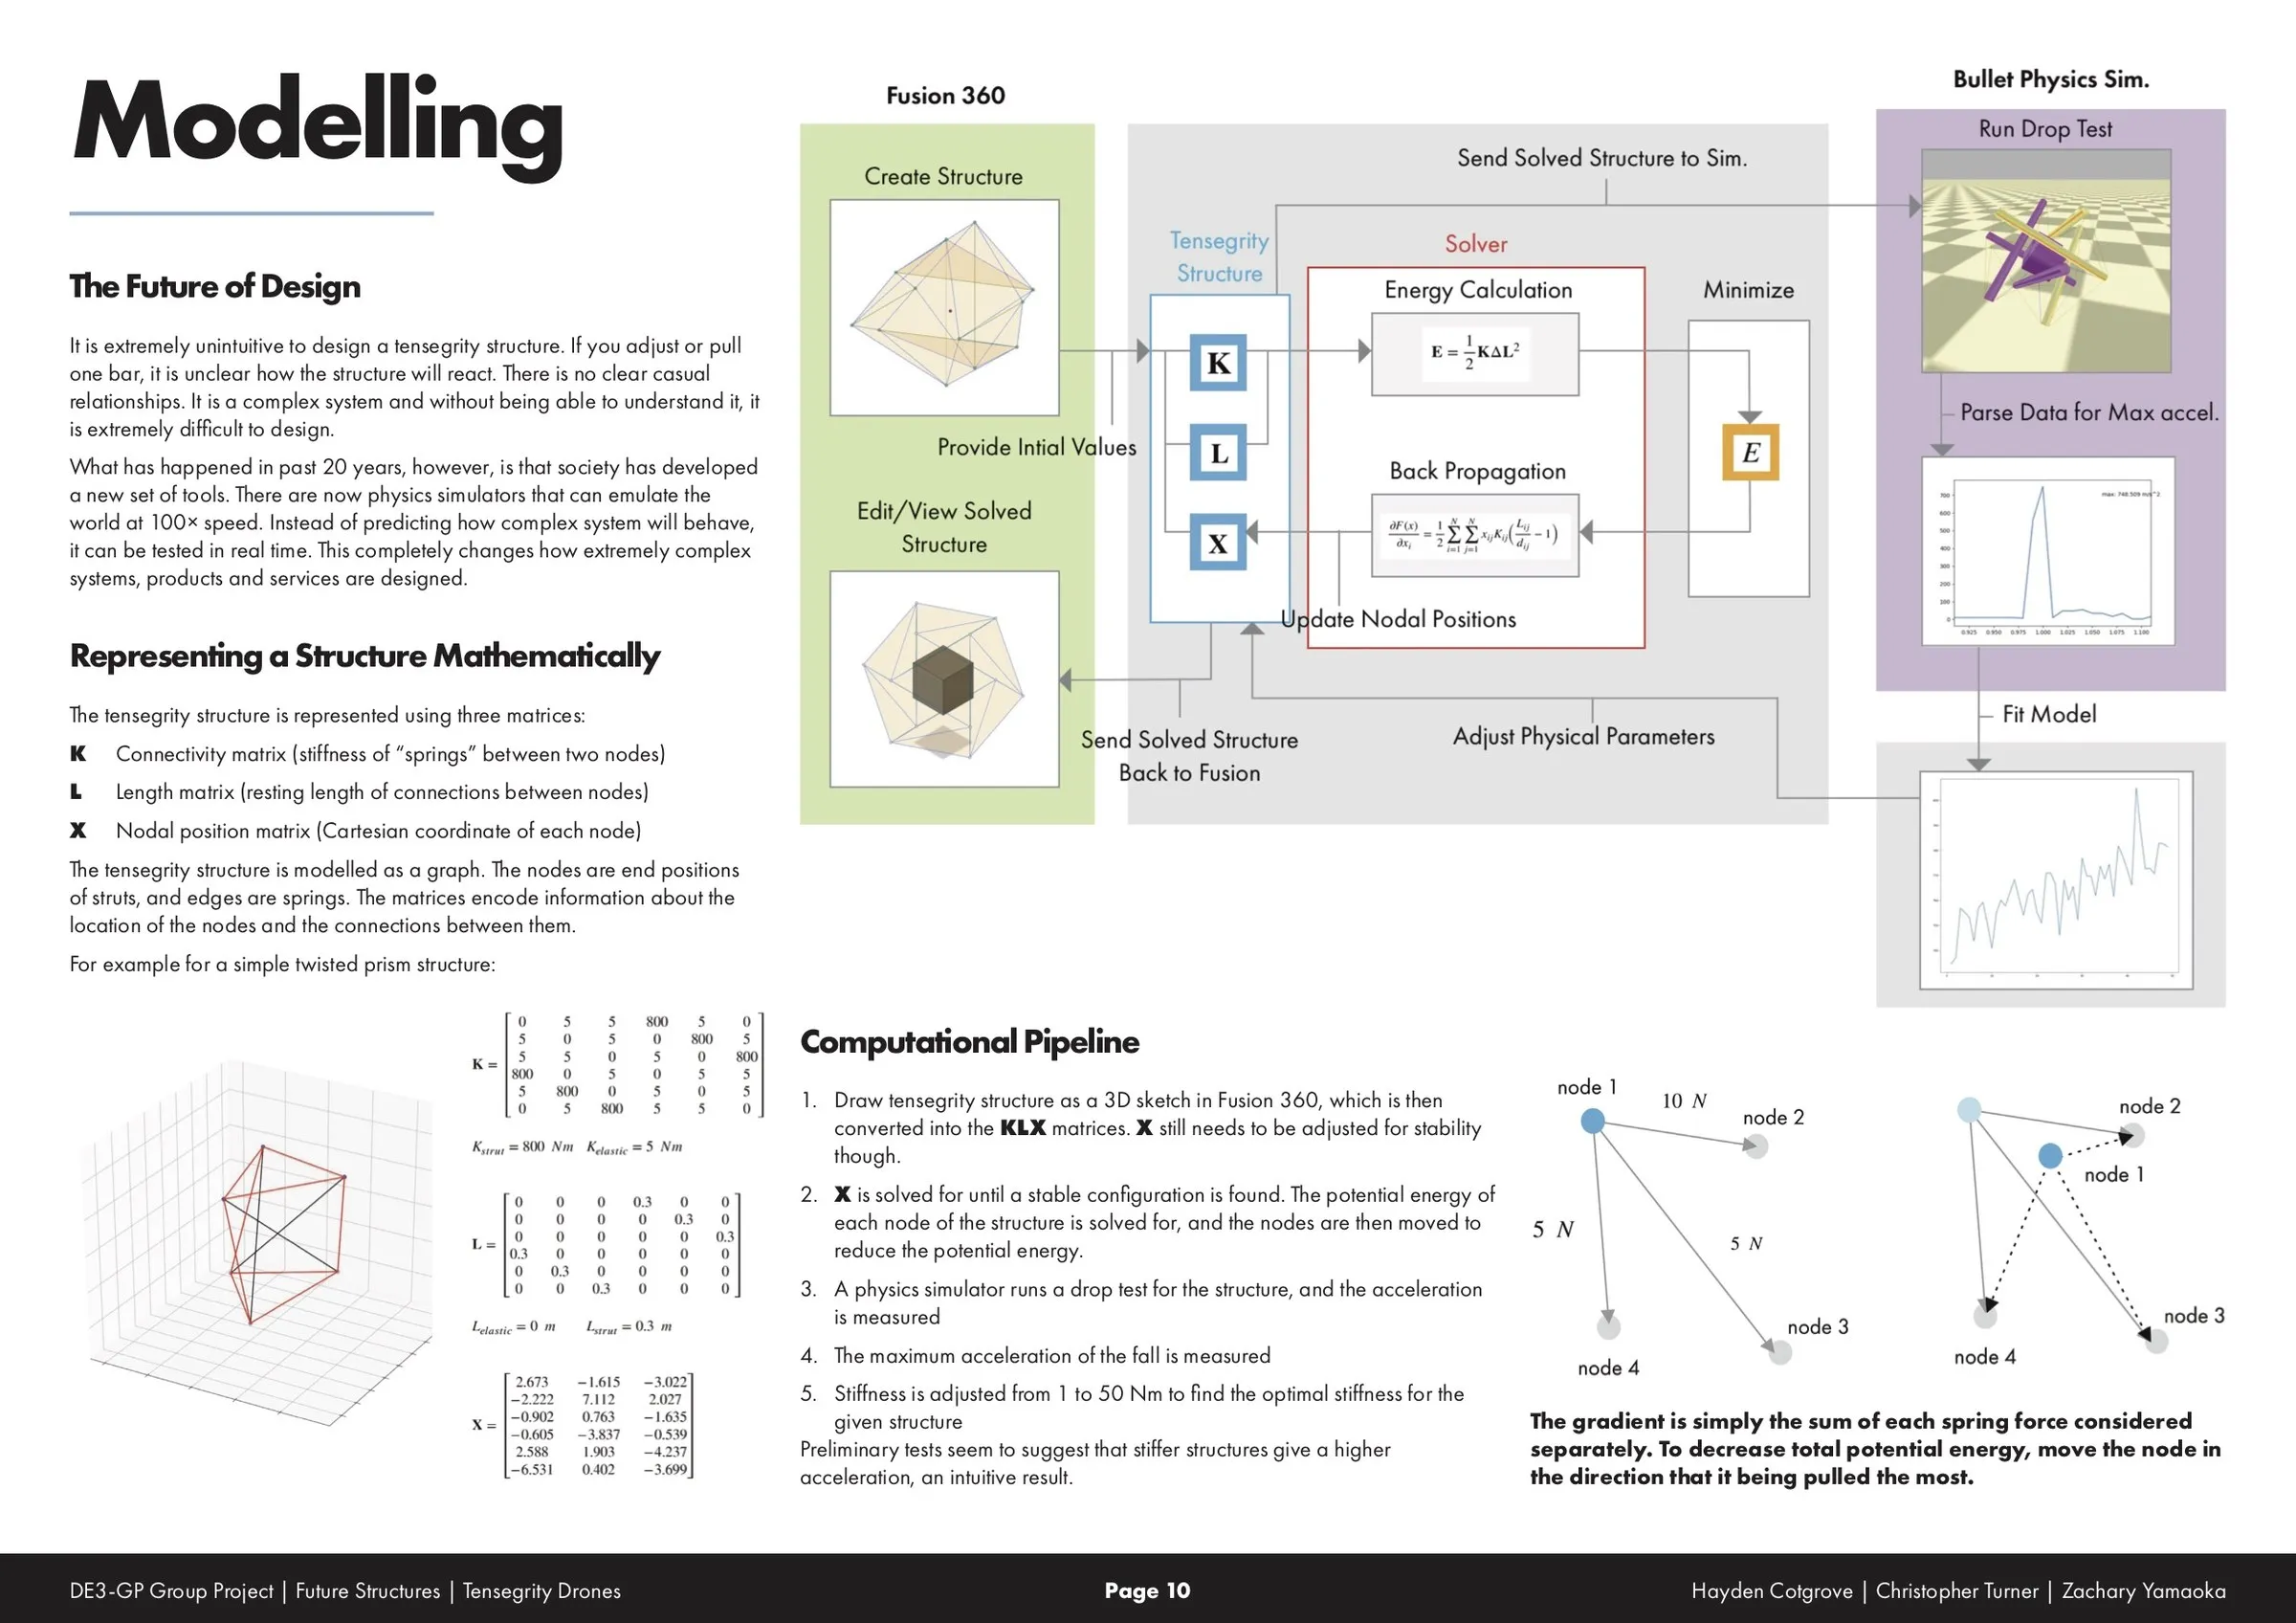
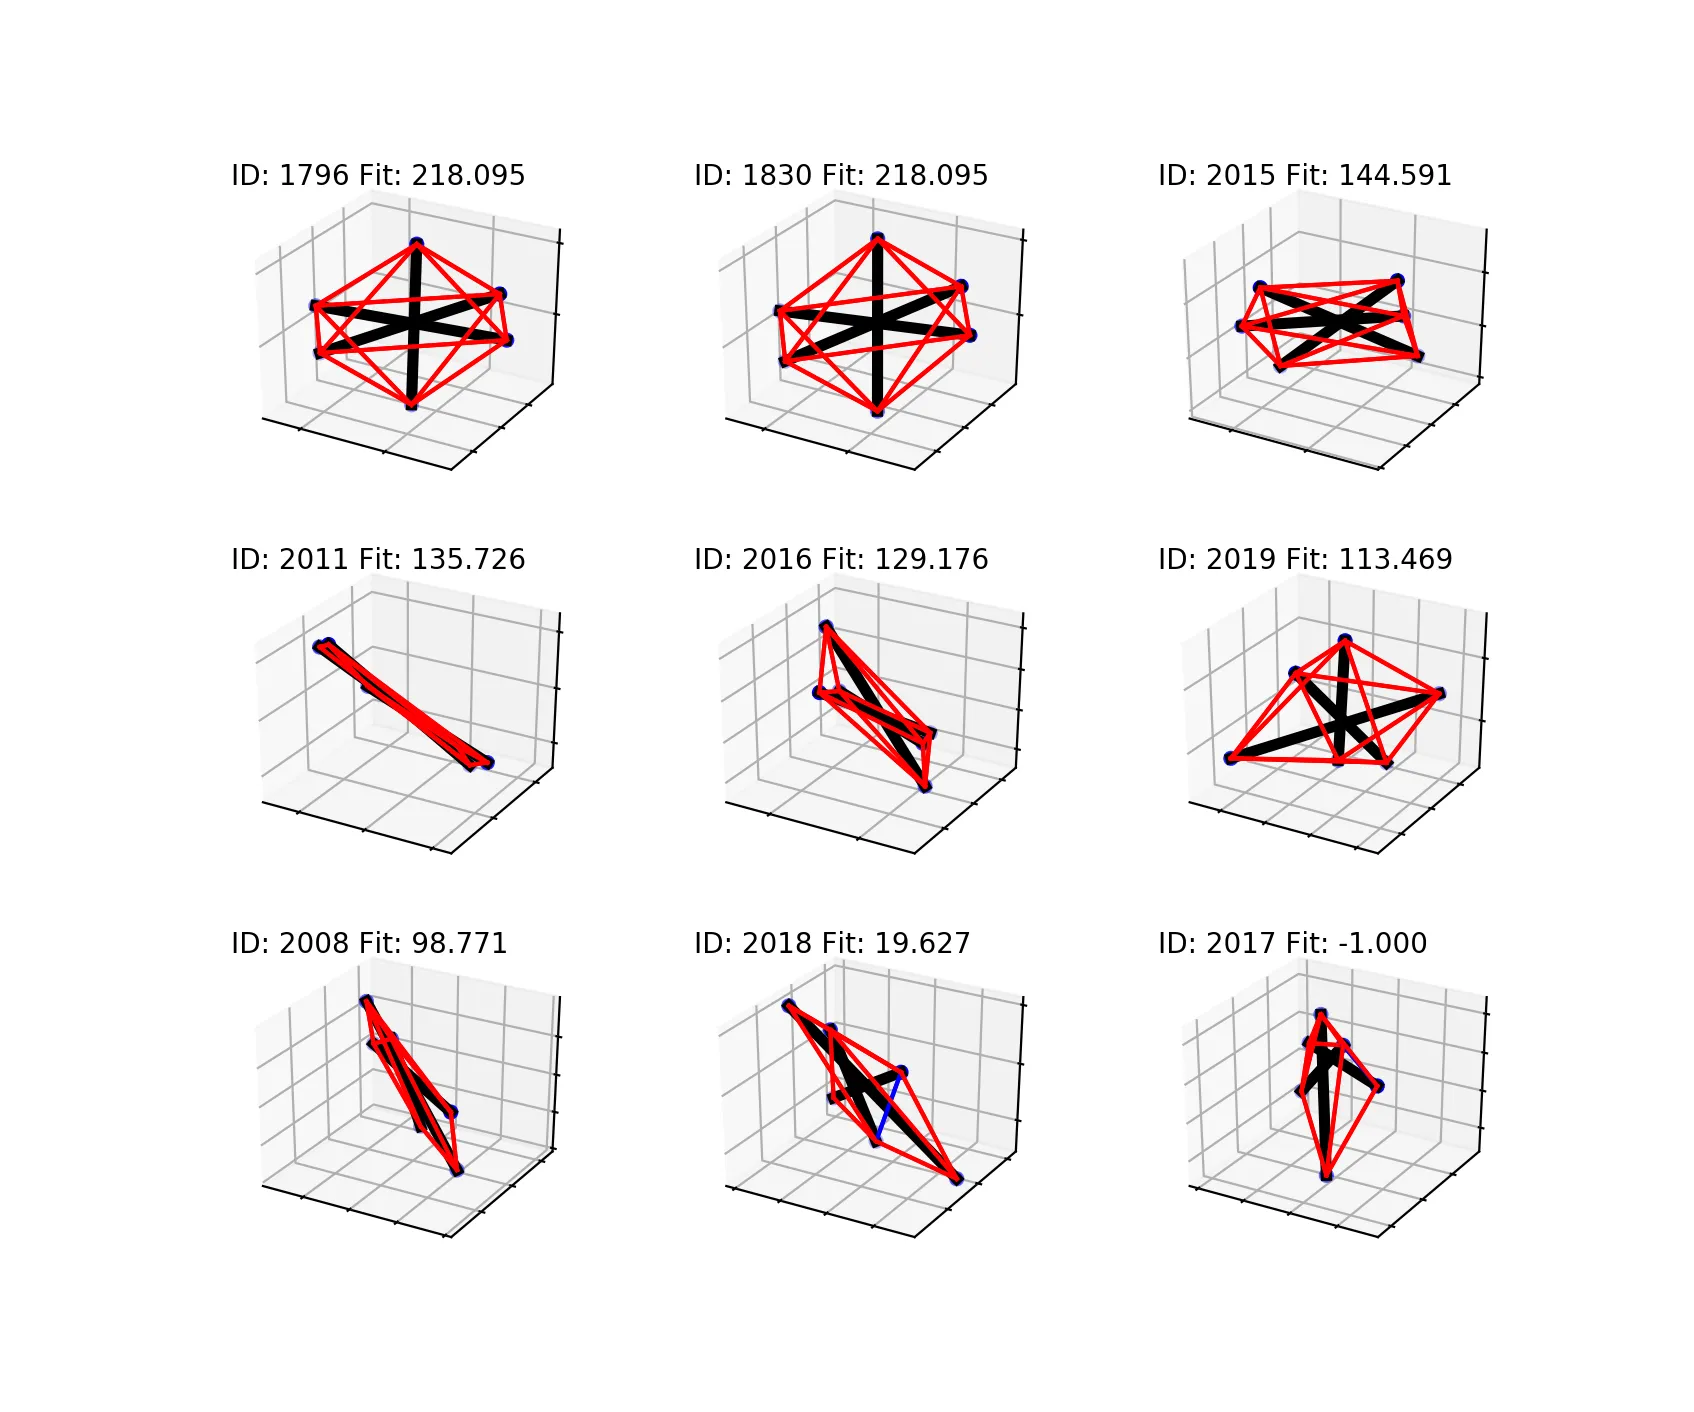
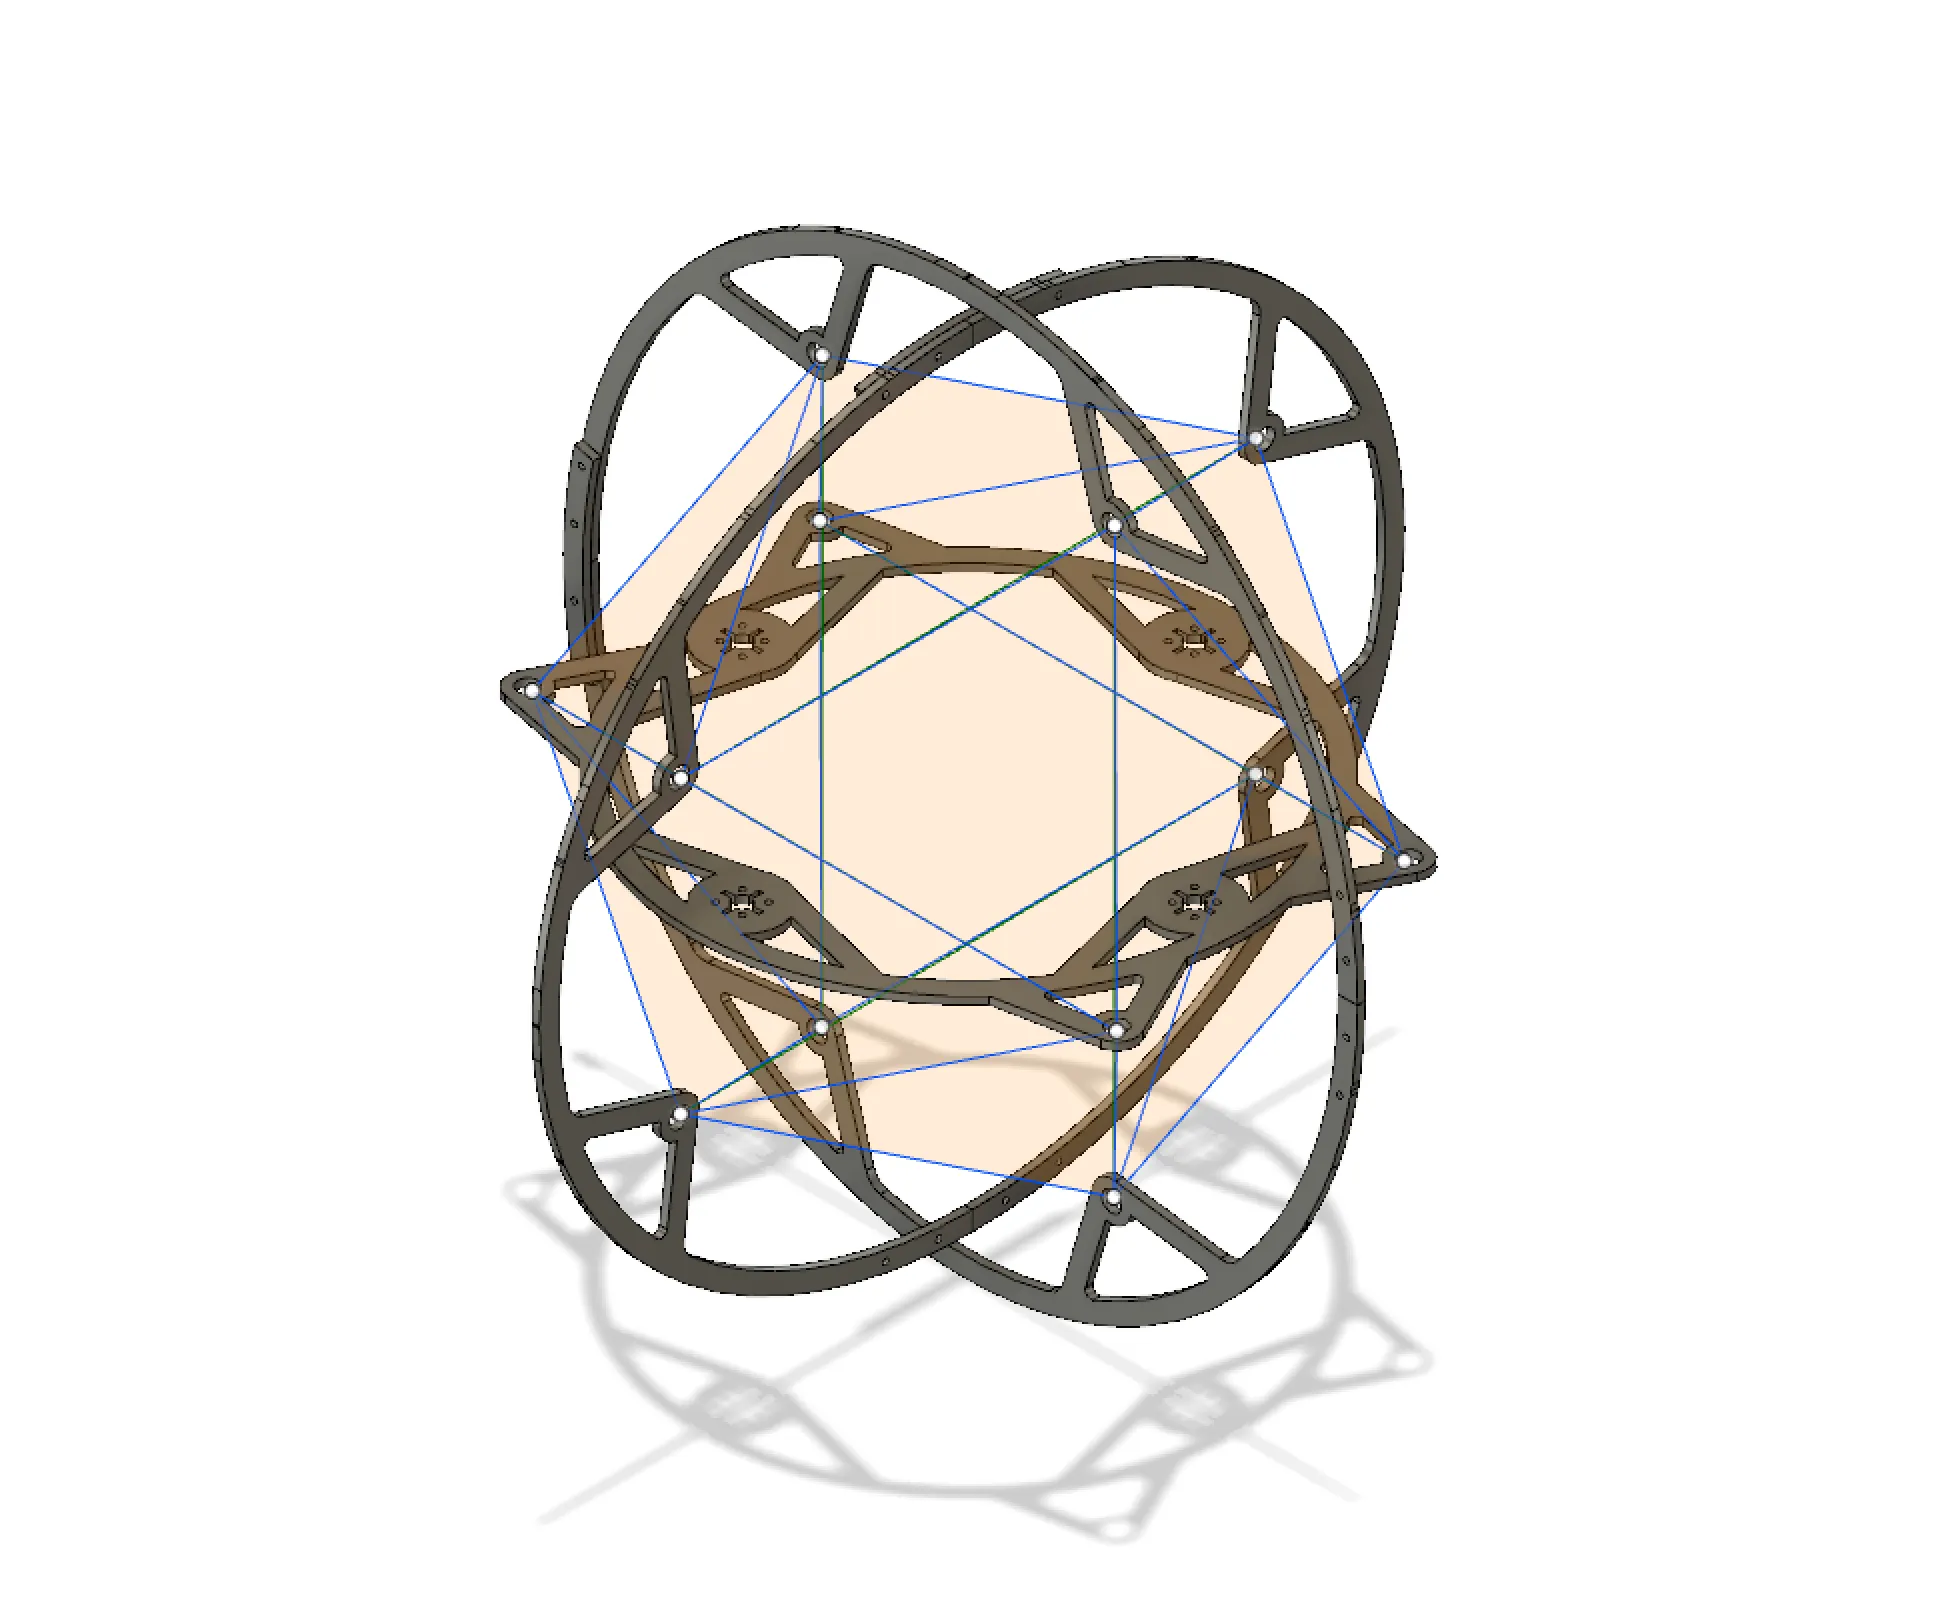
- Implementing an algorithm to find the lowest energy configuration of an arbitrary tensegrity structure
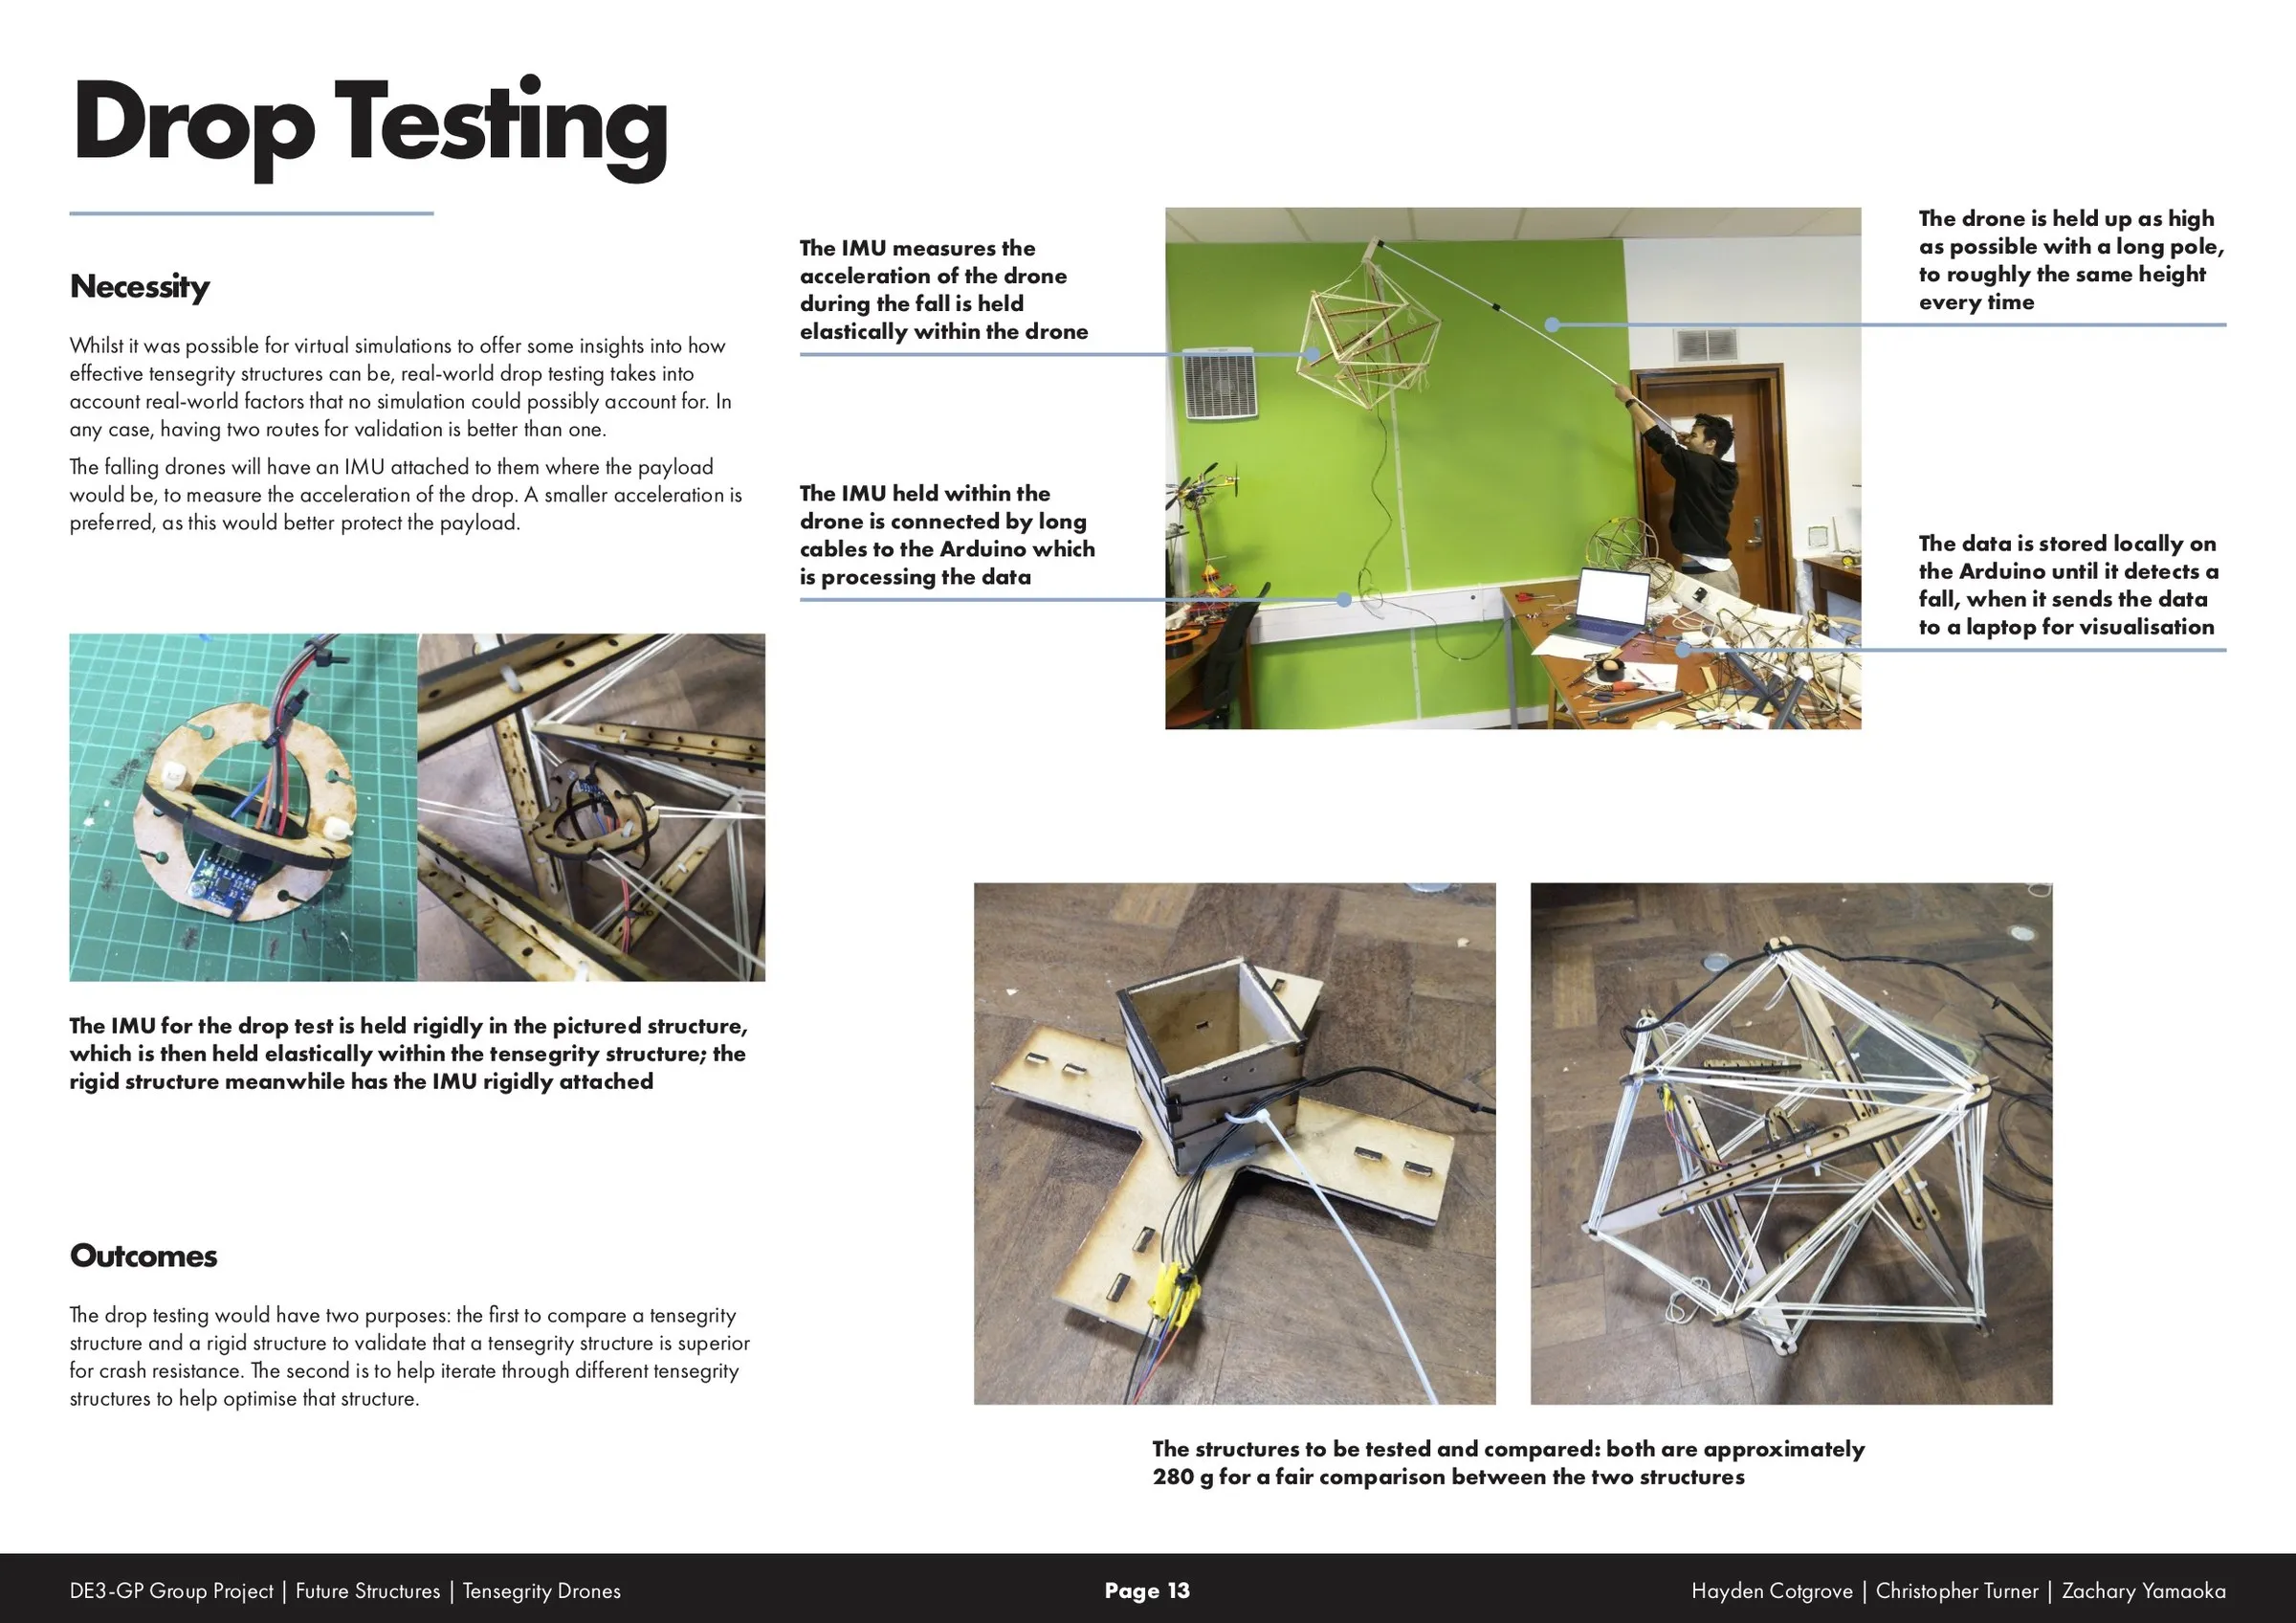
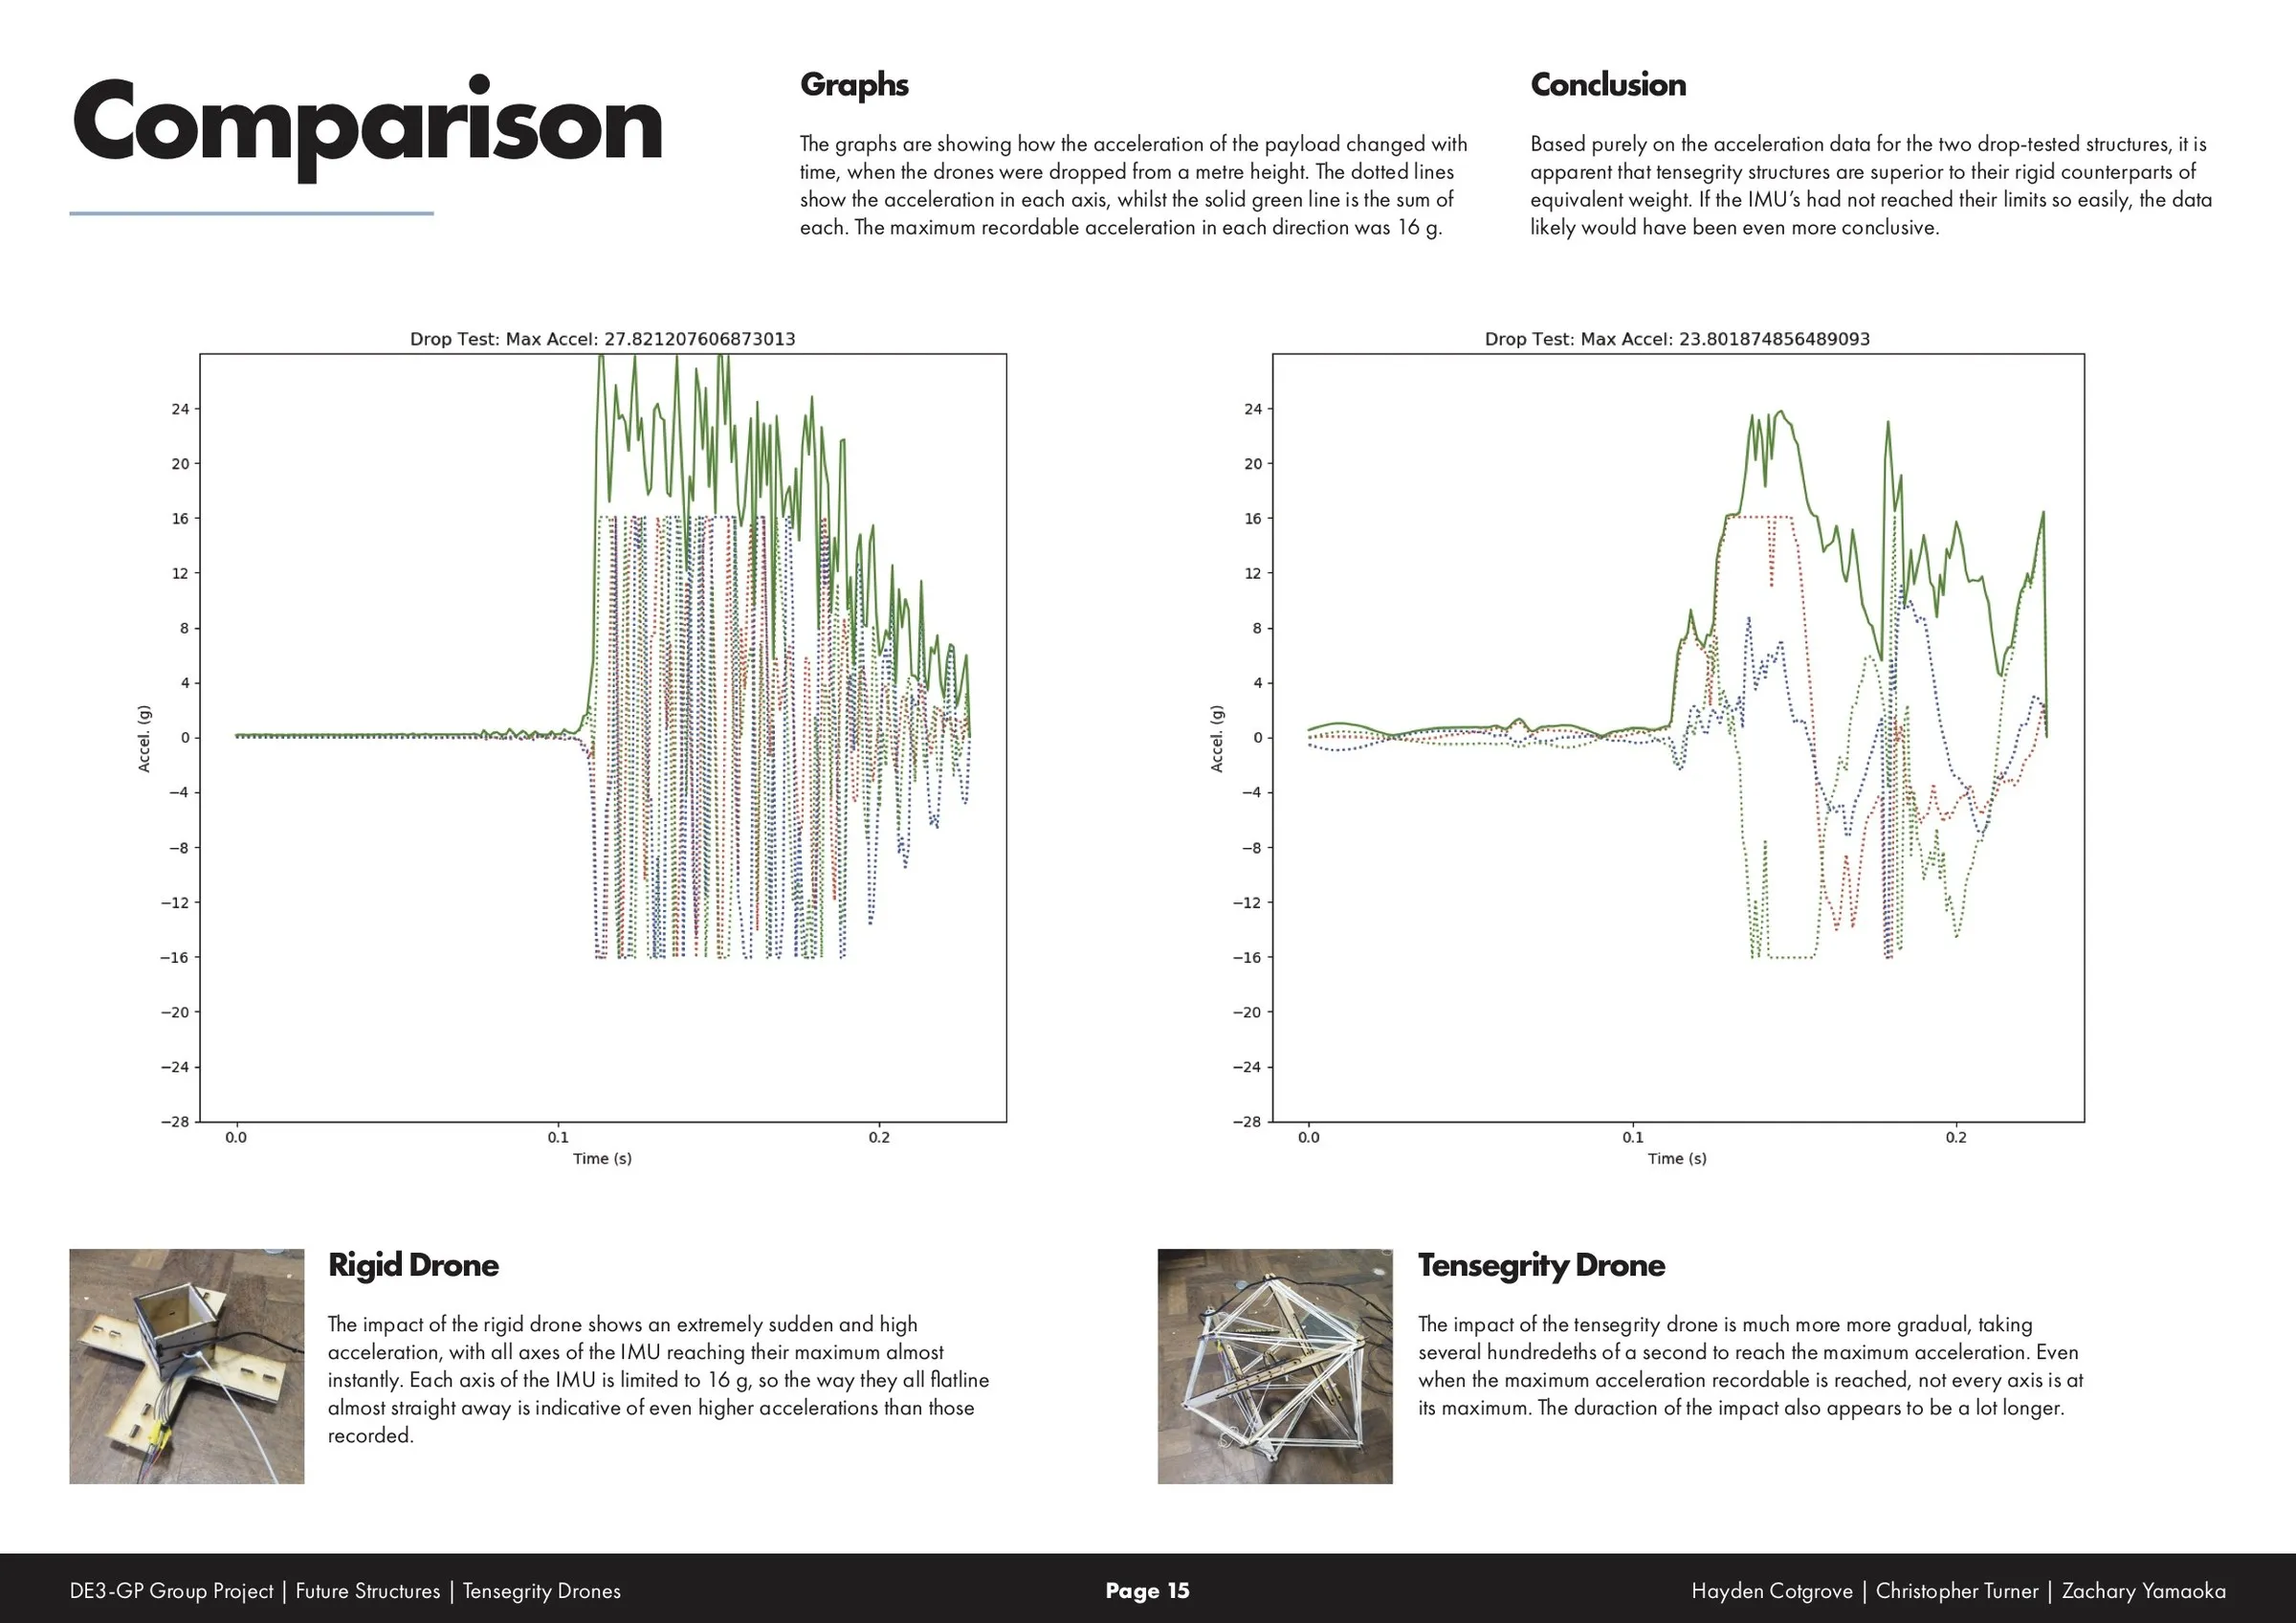
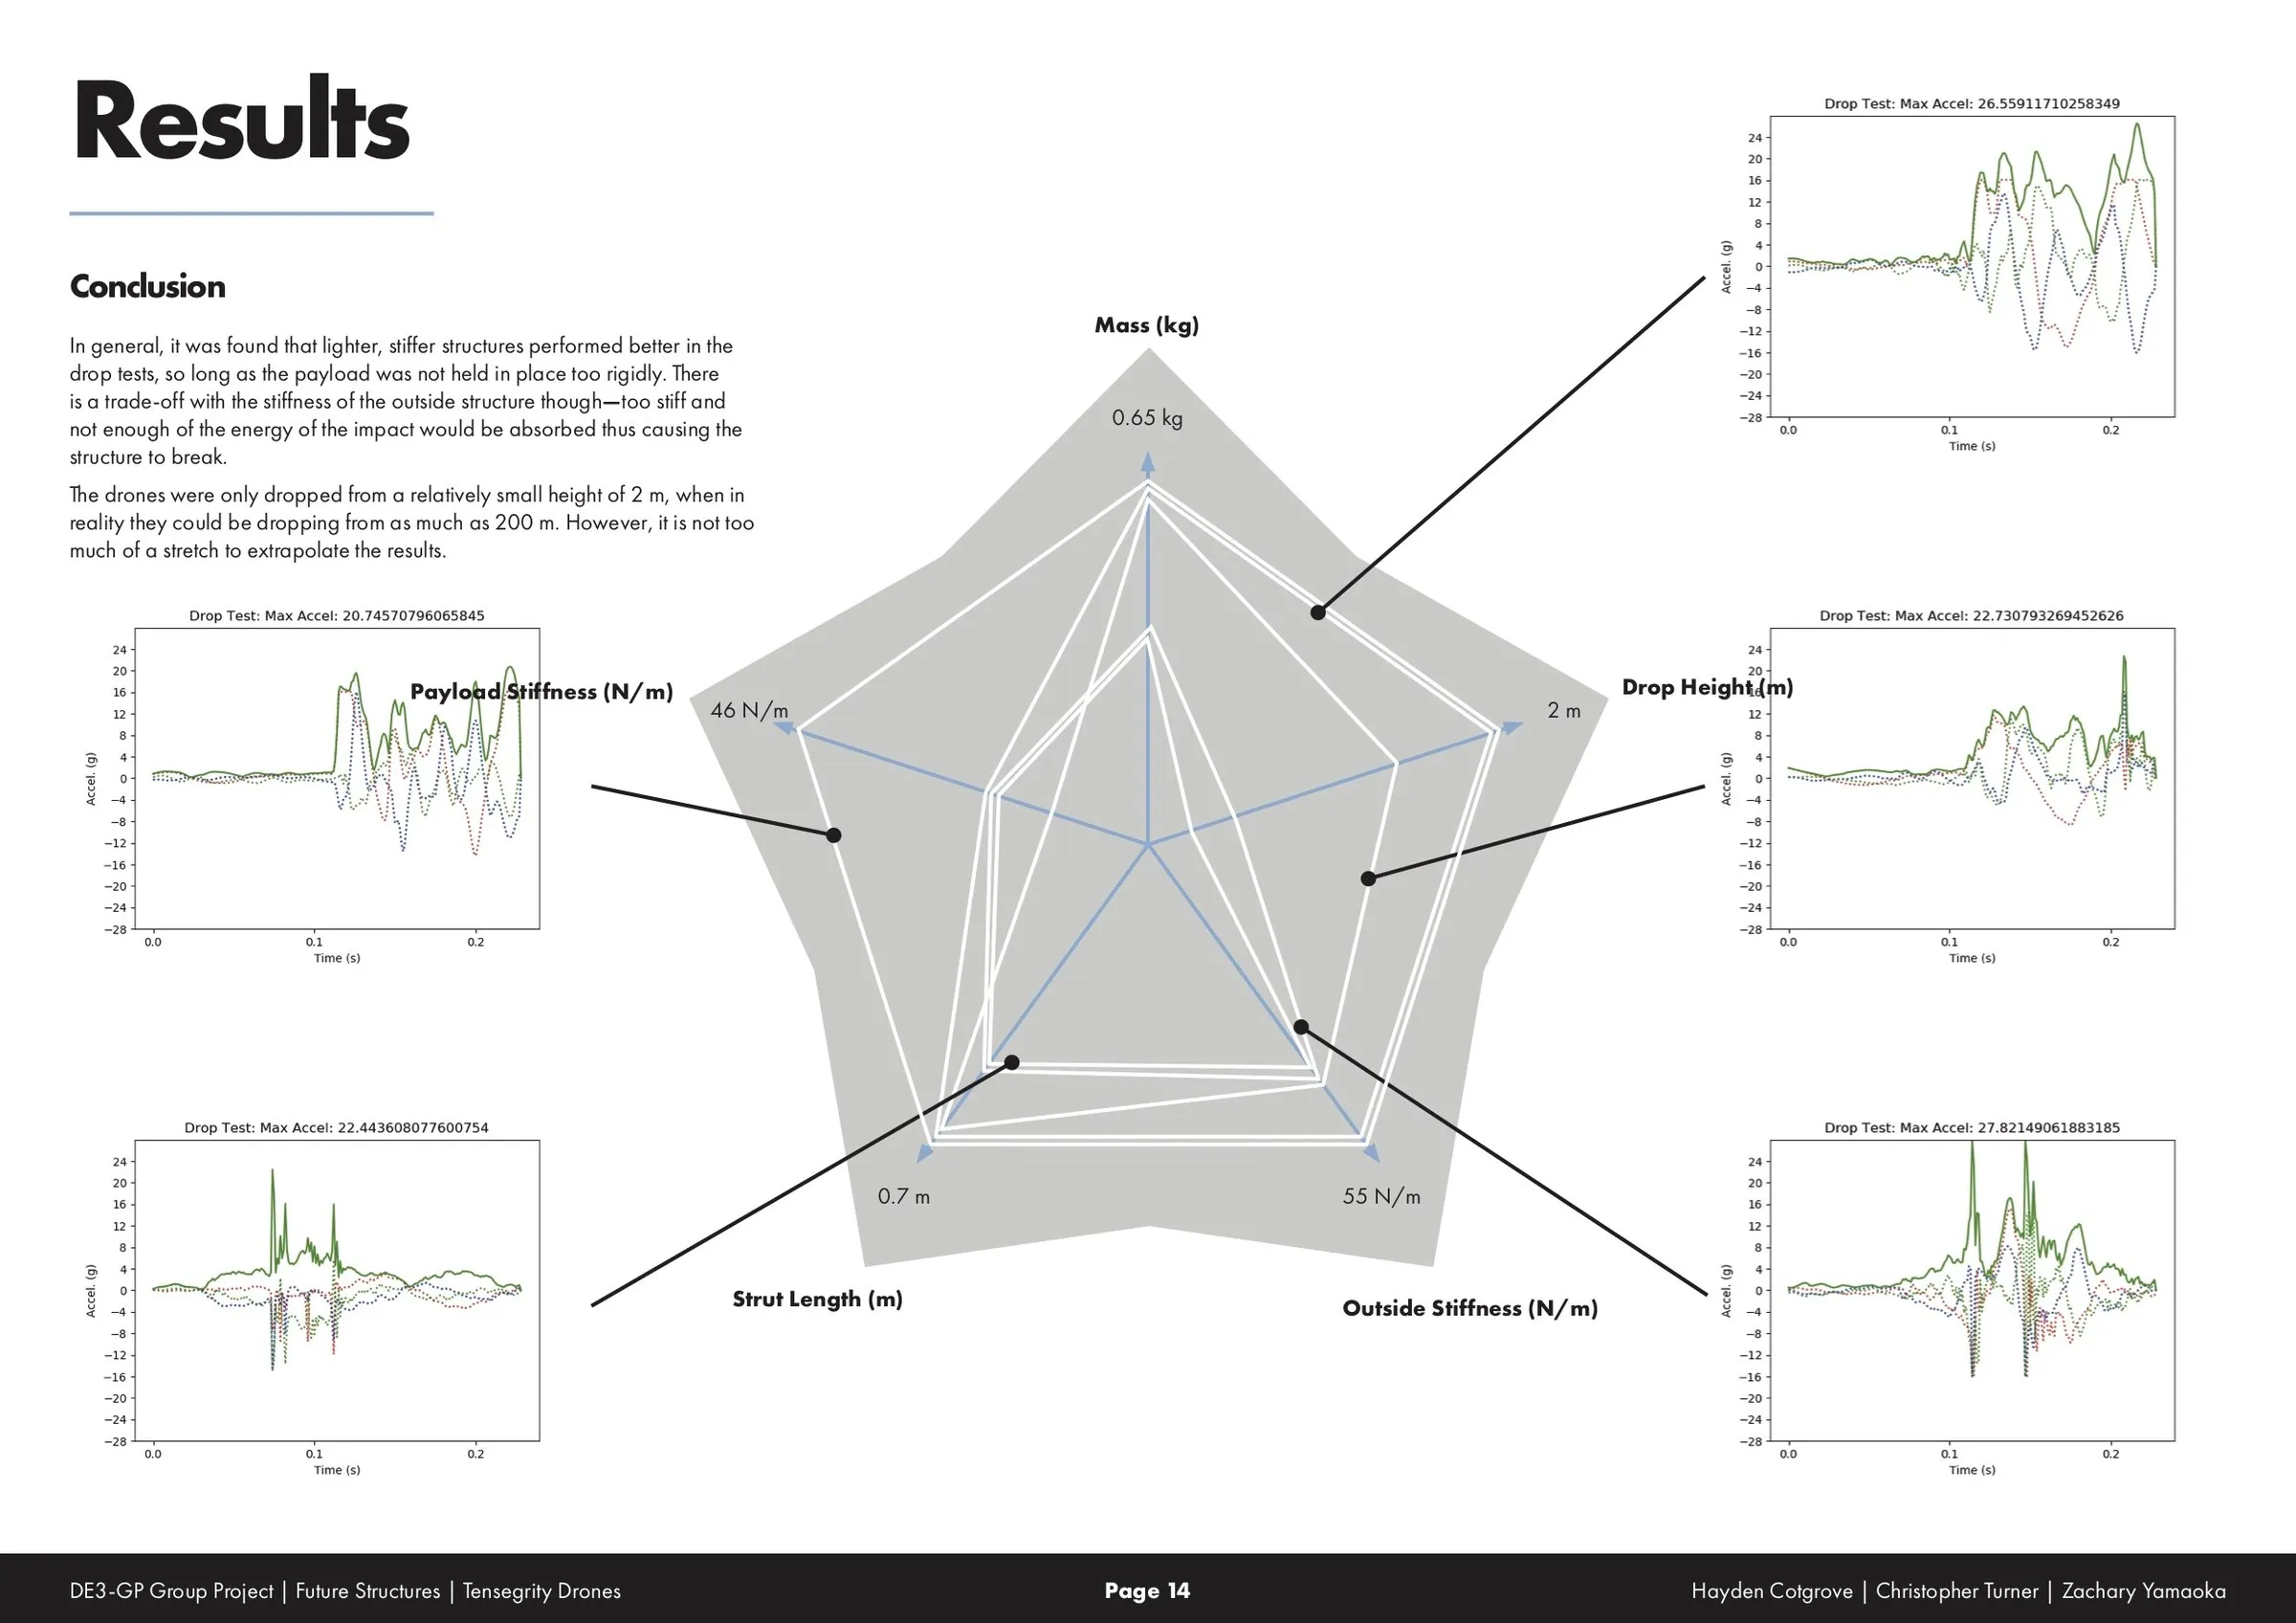
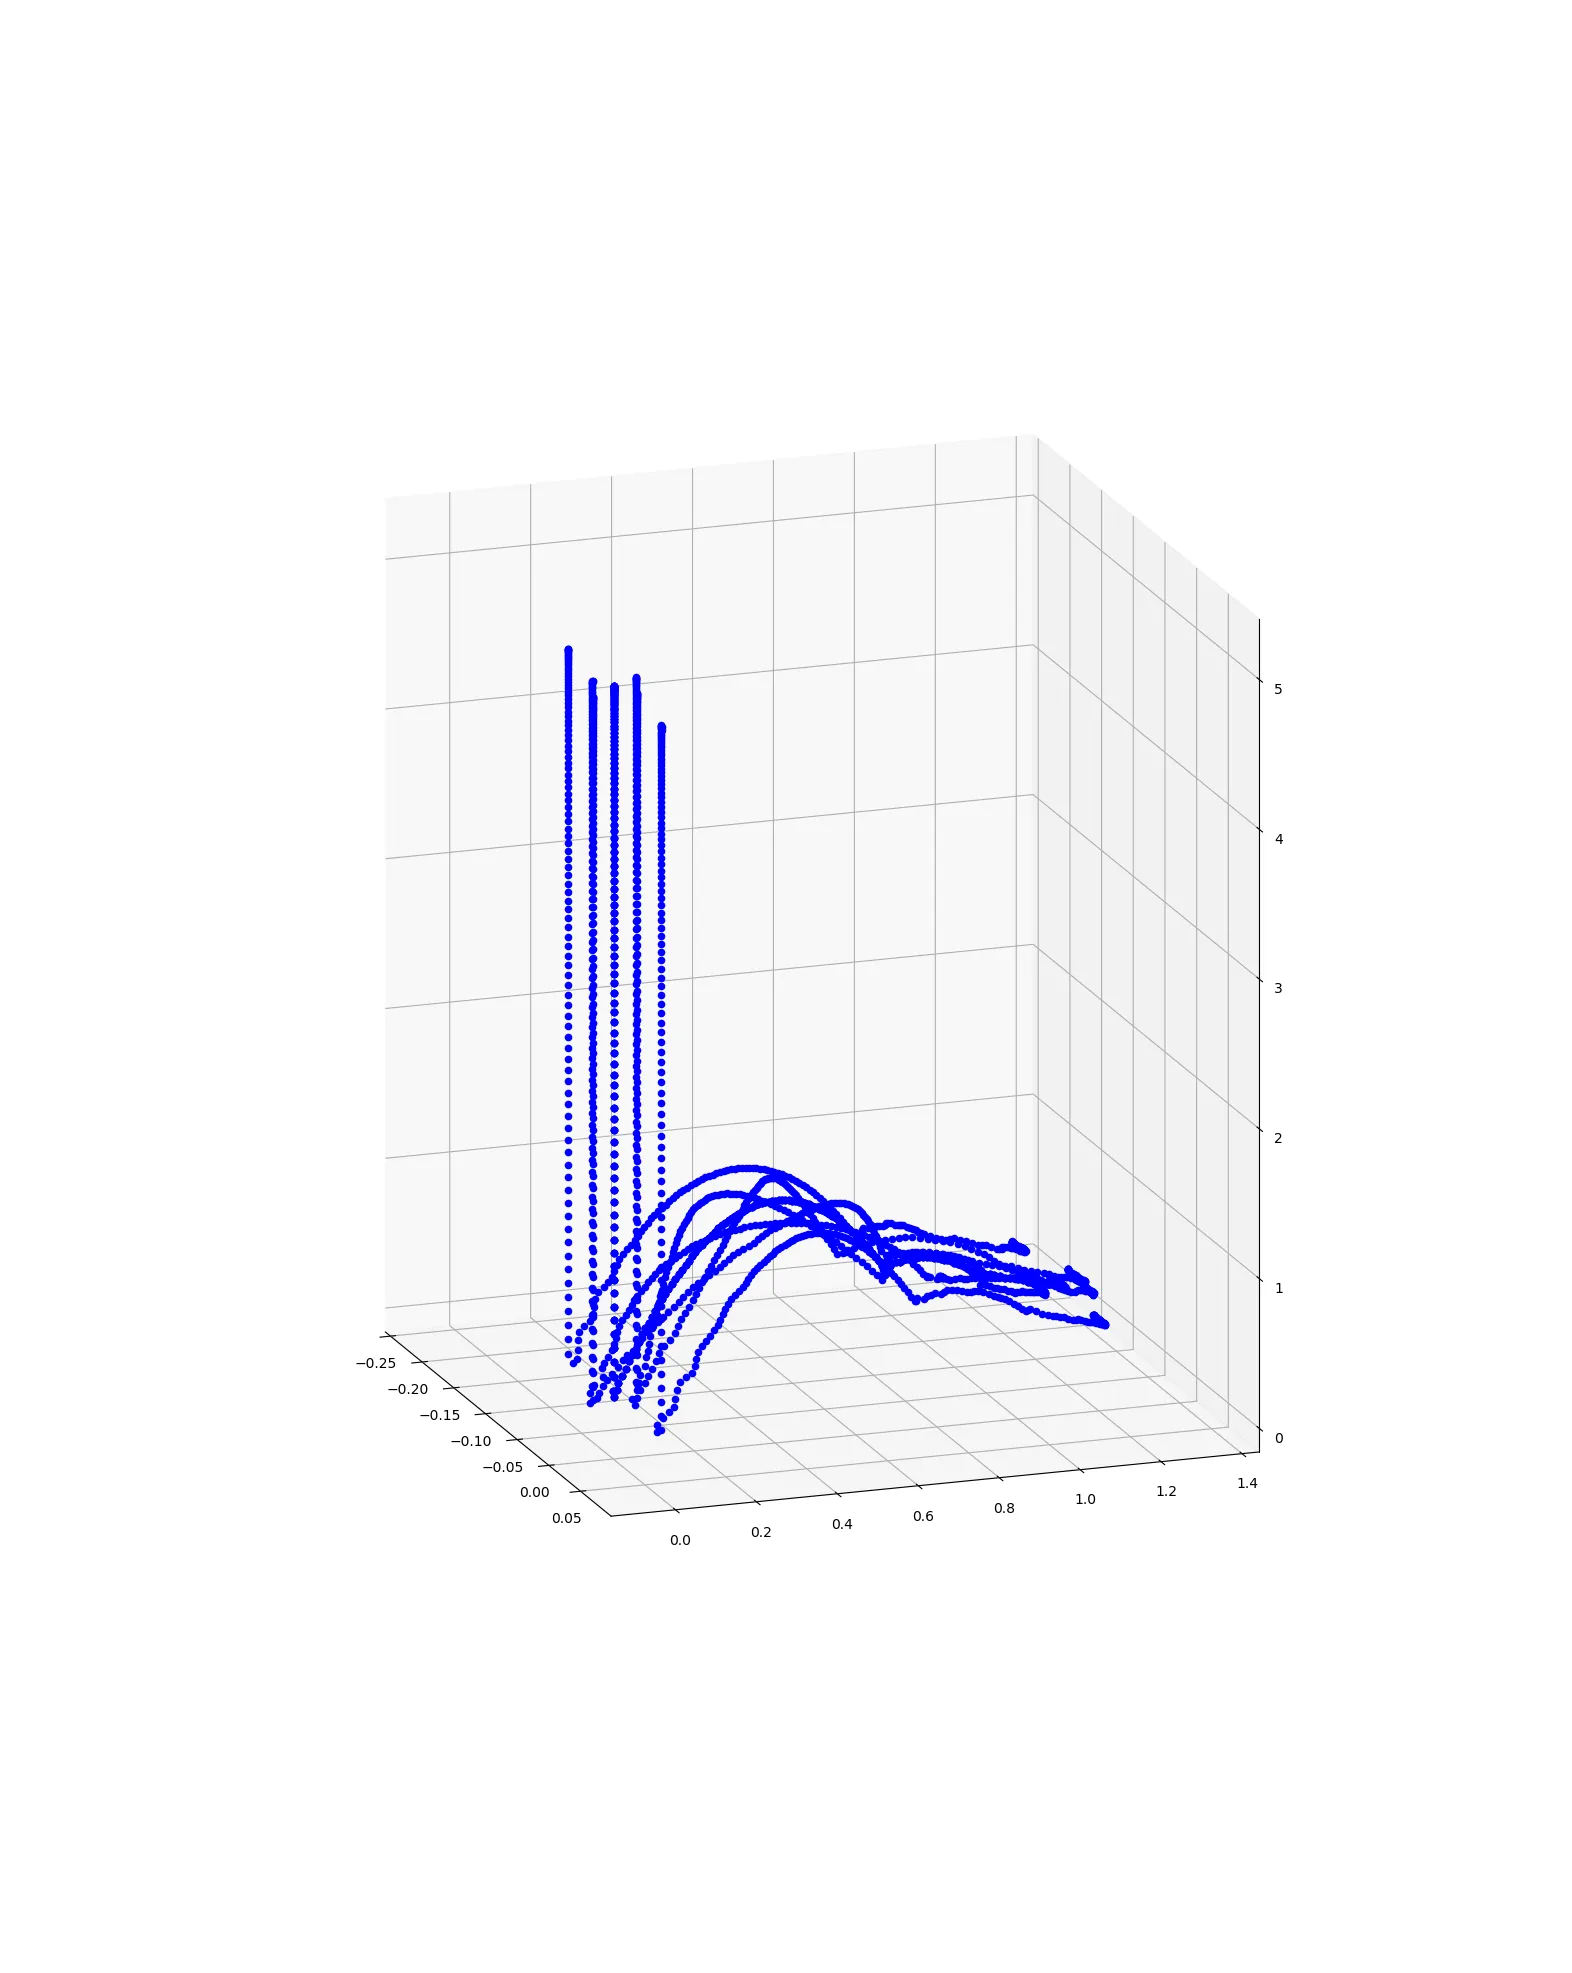
- Testing/validation the benefit of using tensegrity vs rigid drone
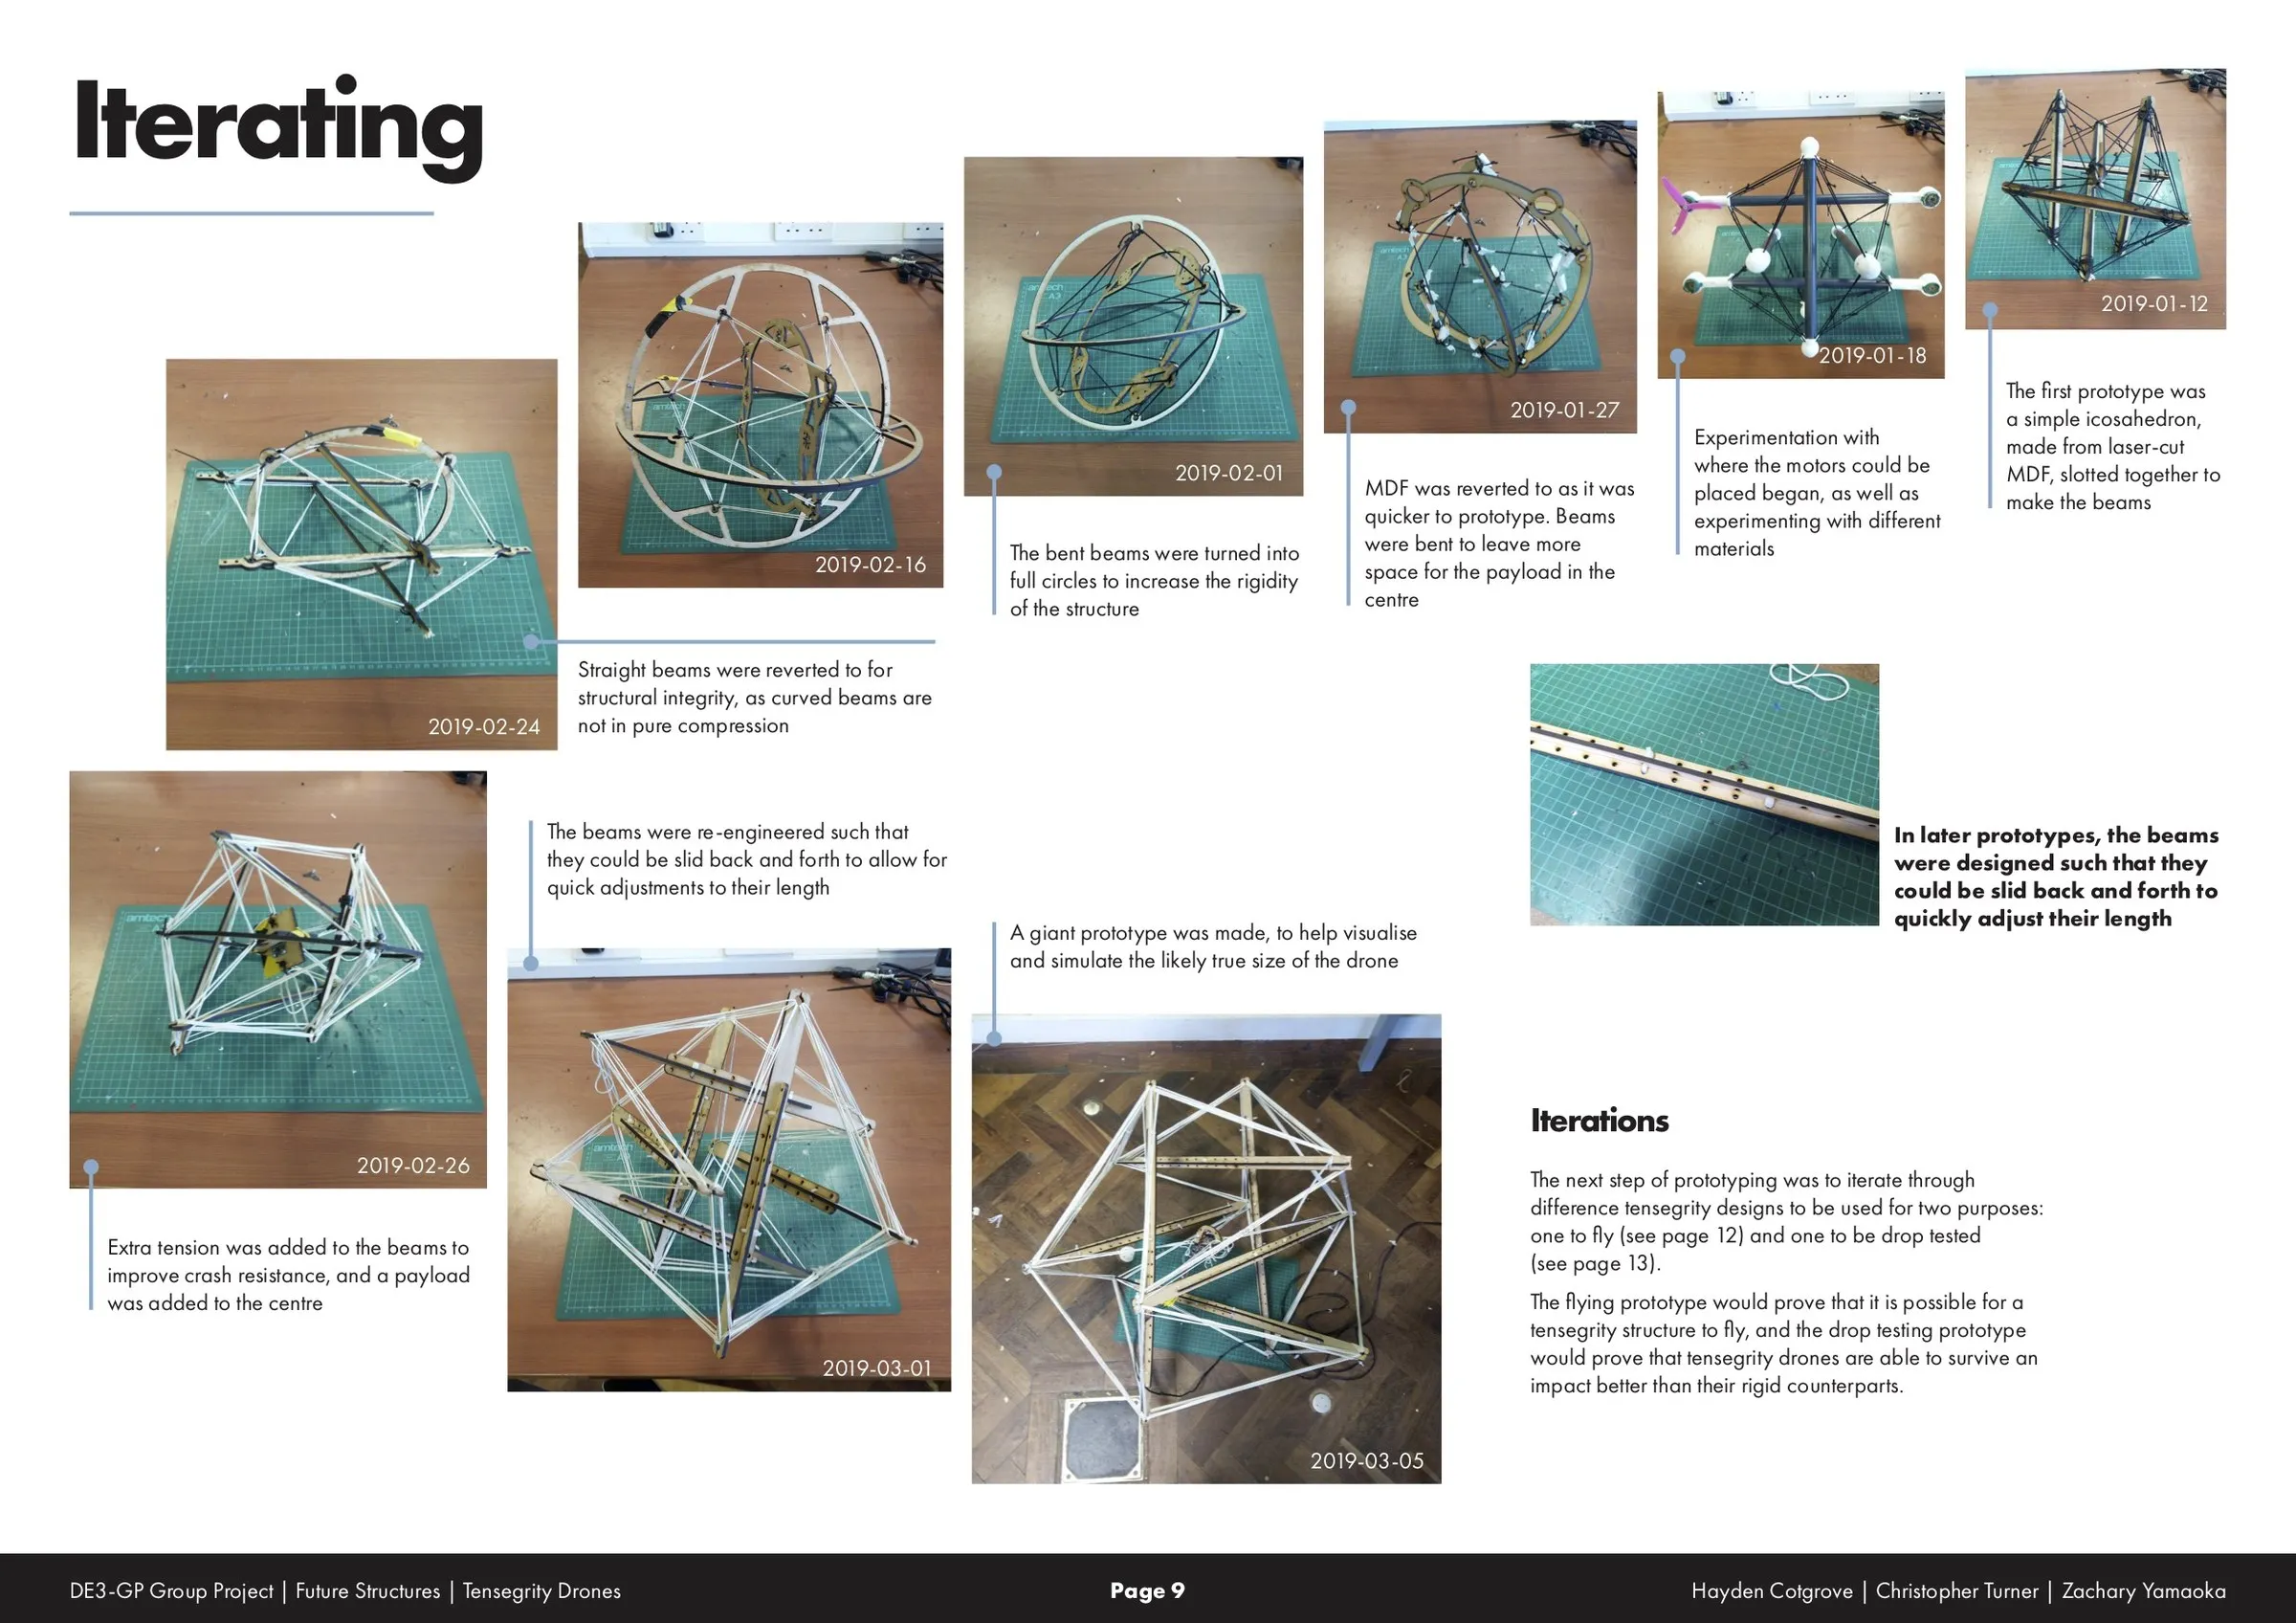
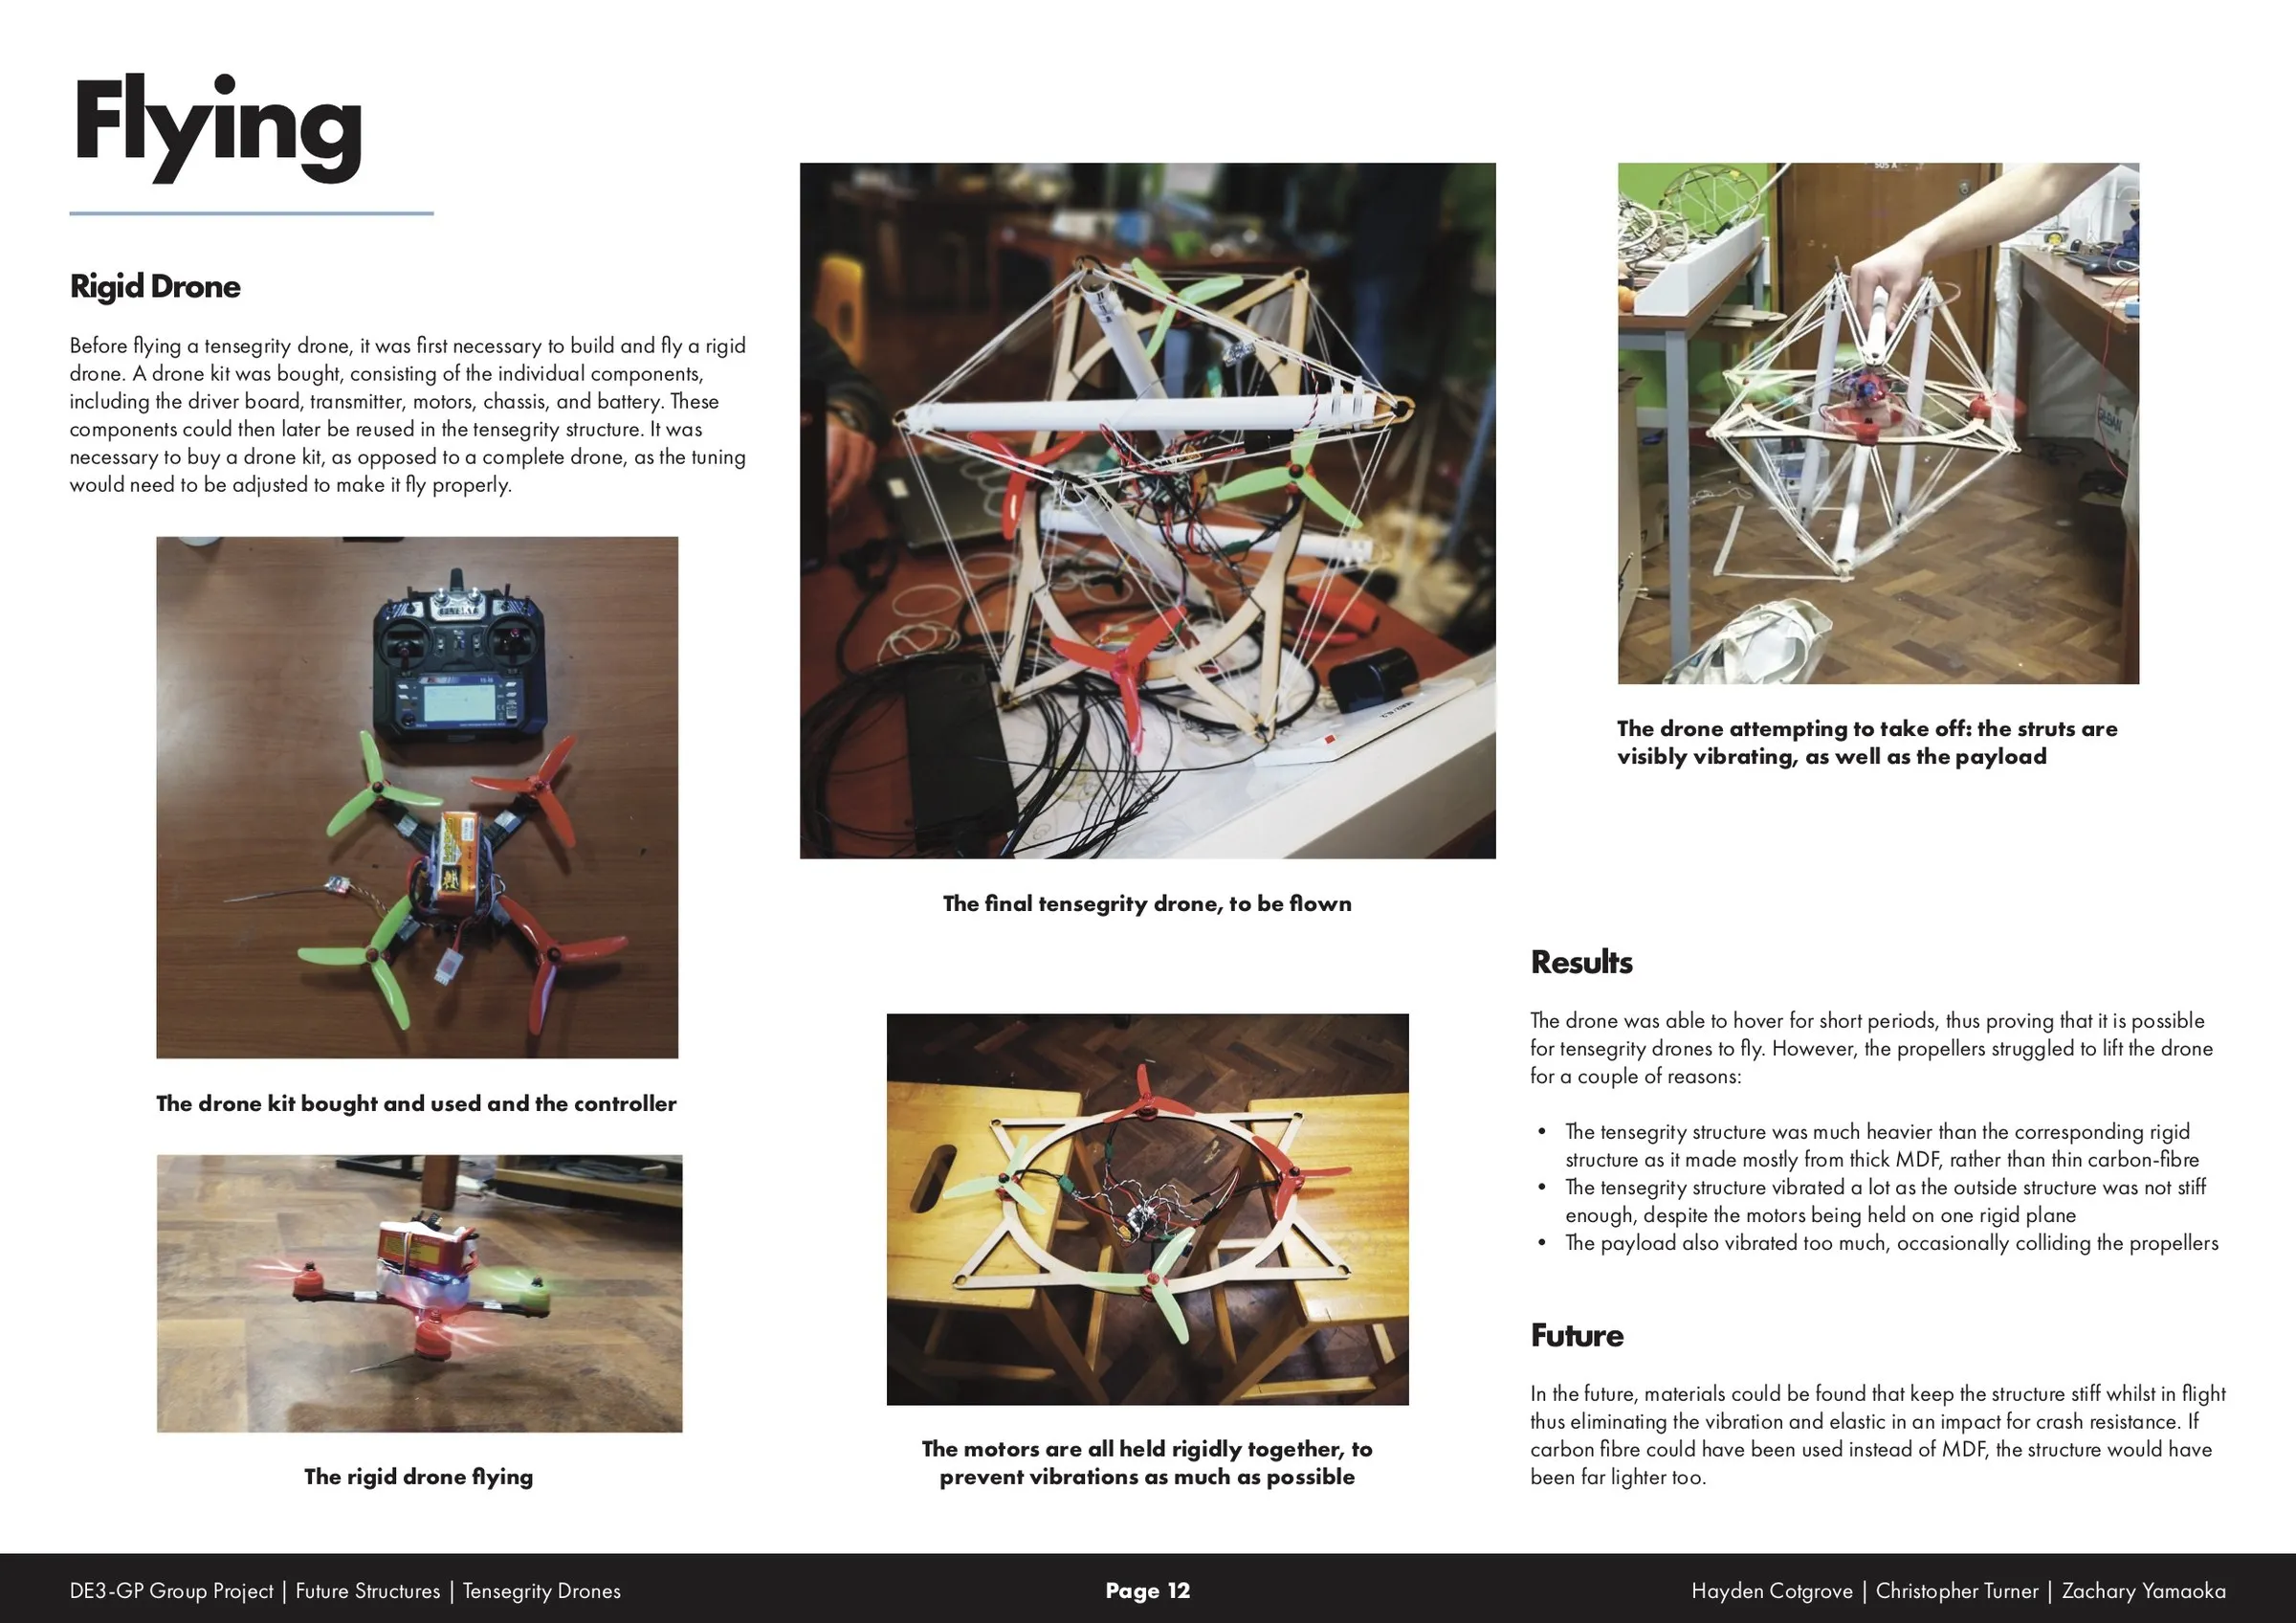
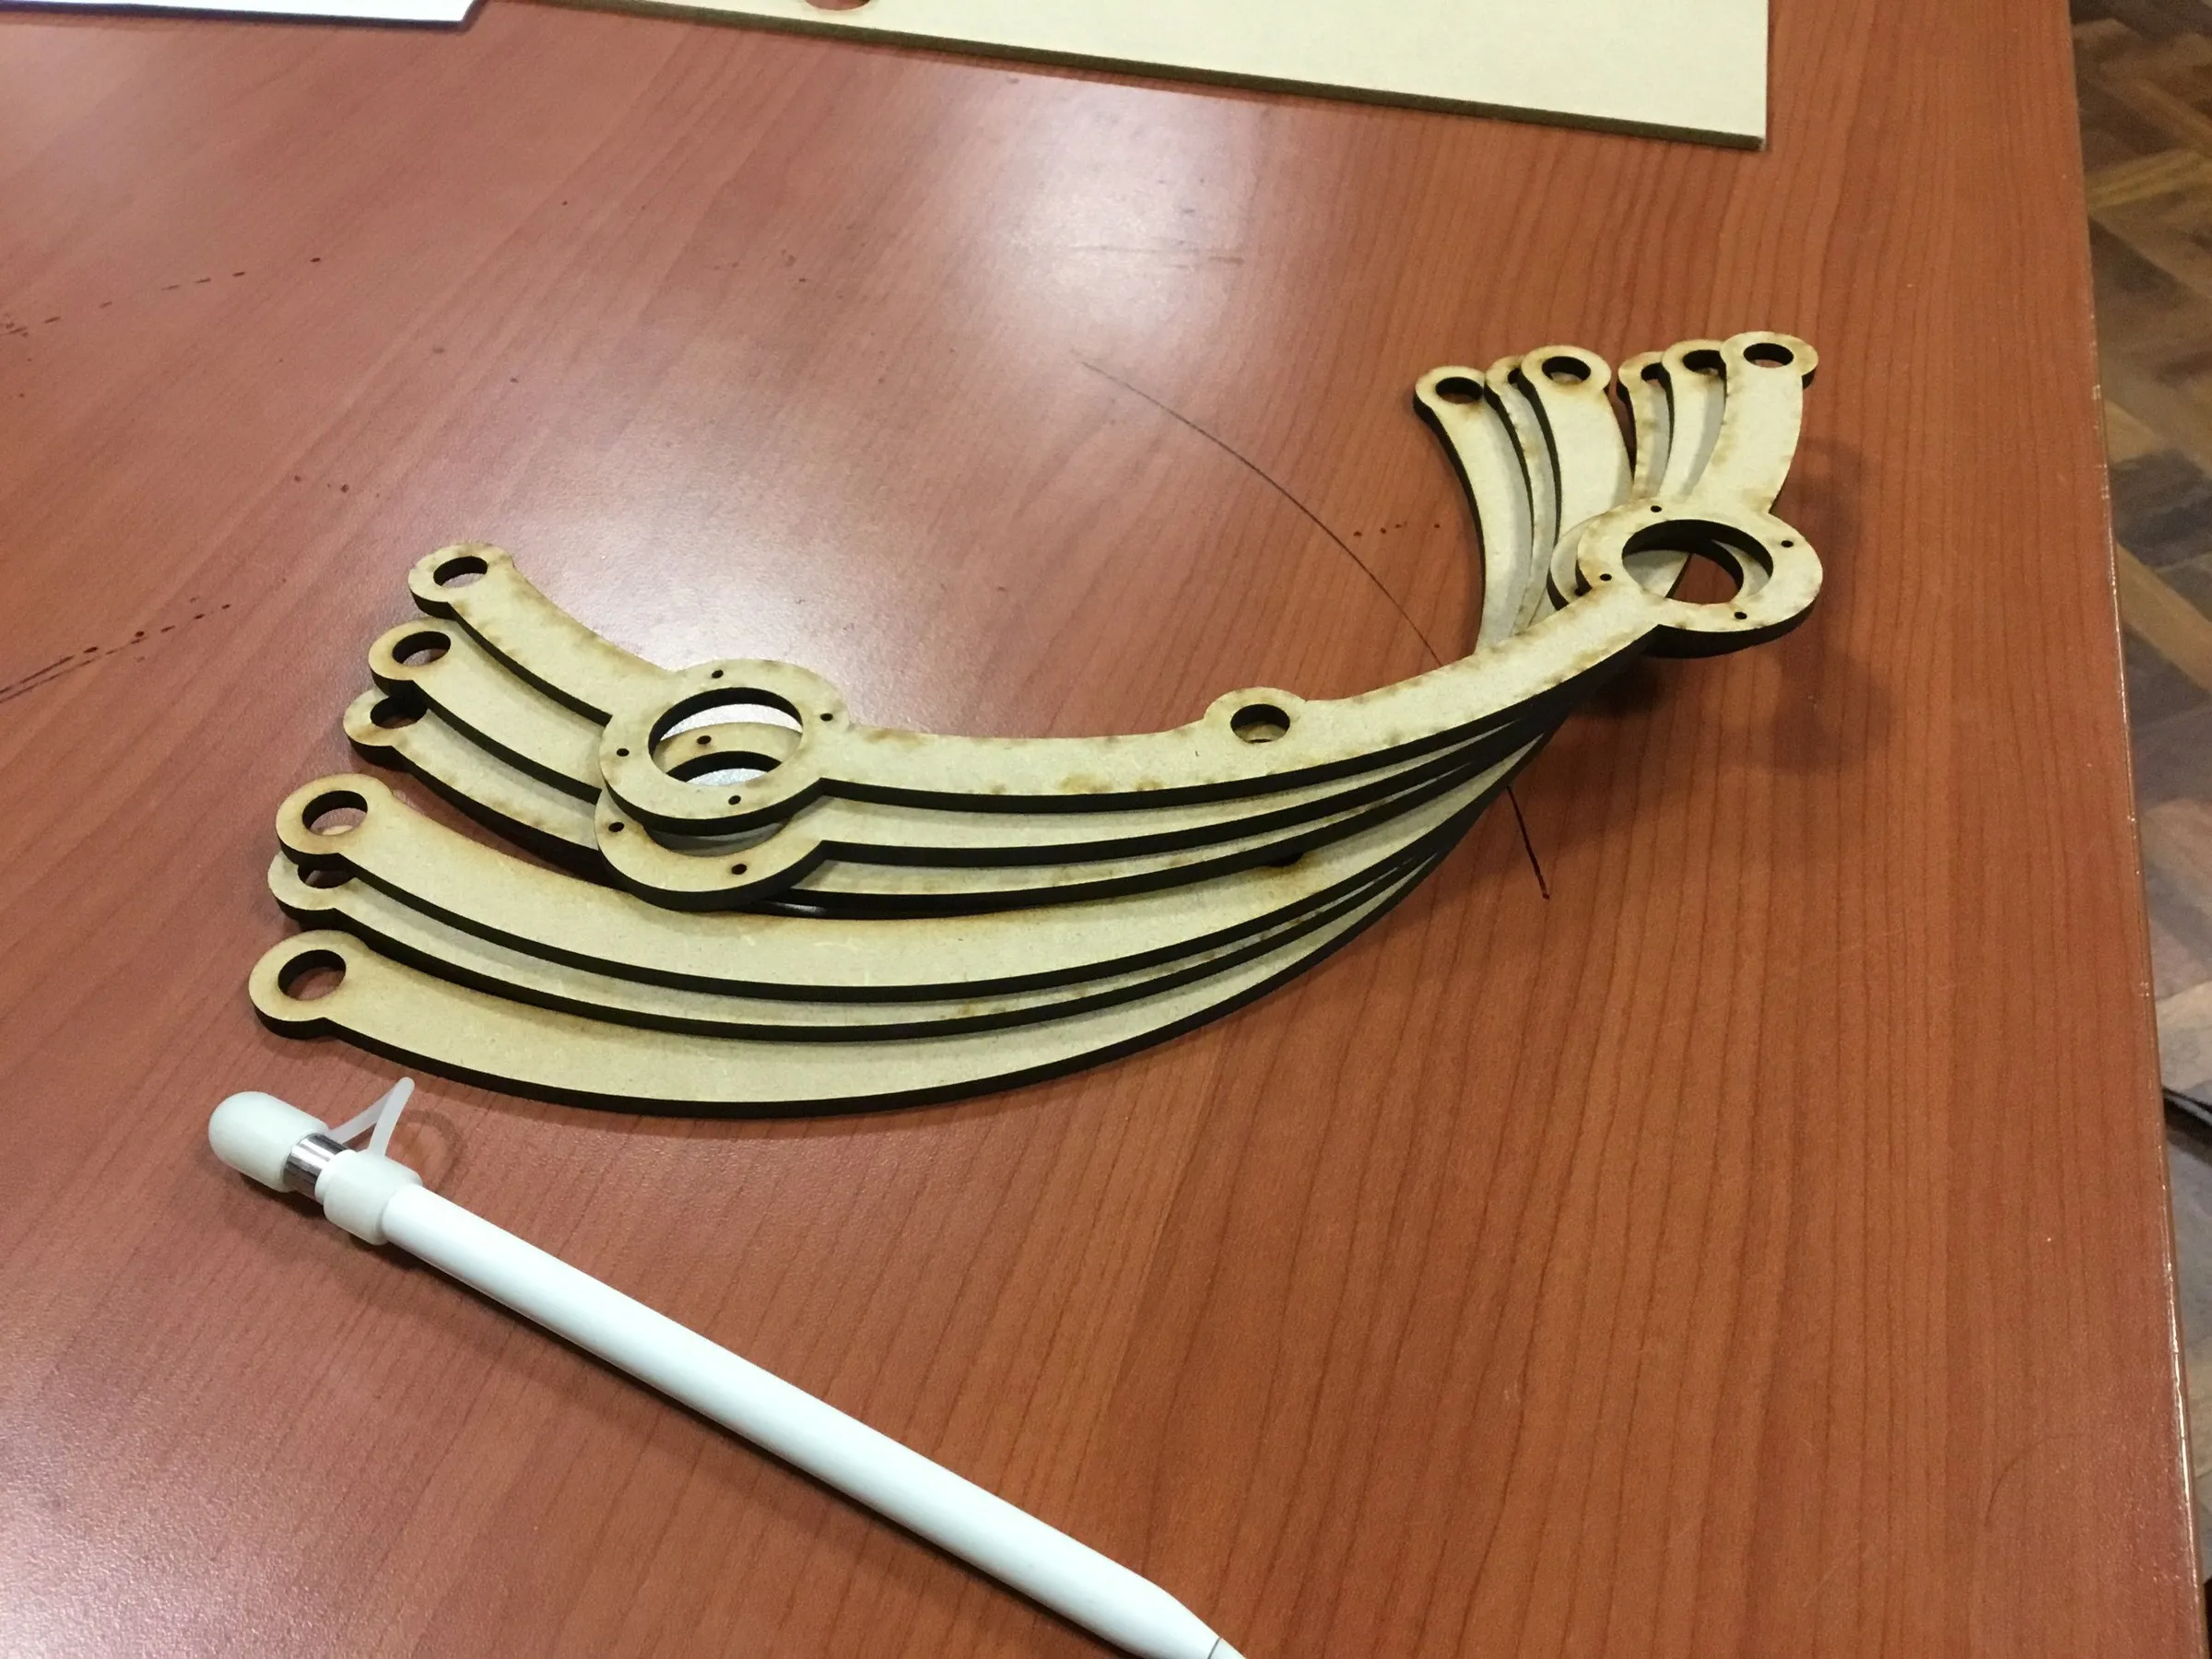
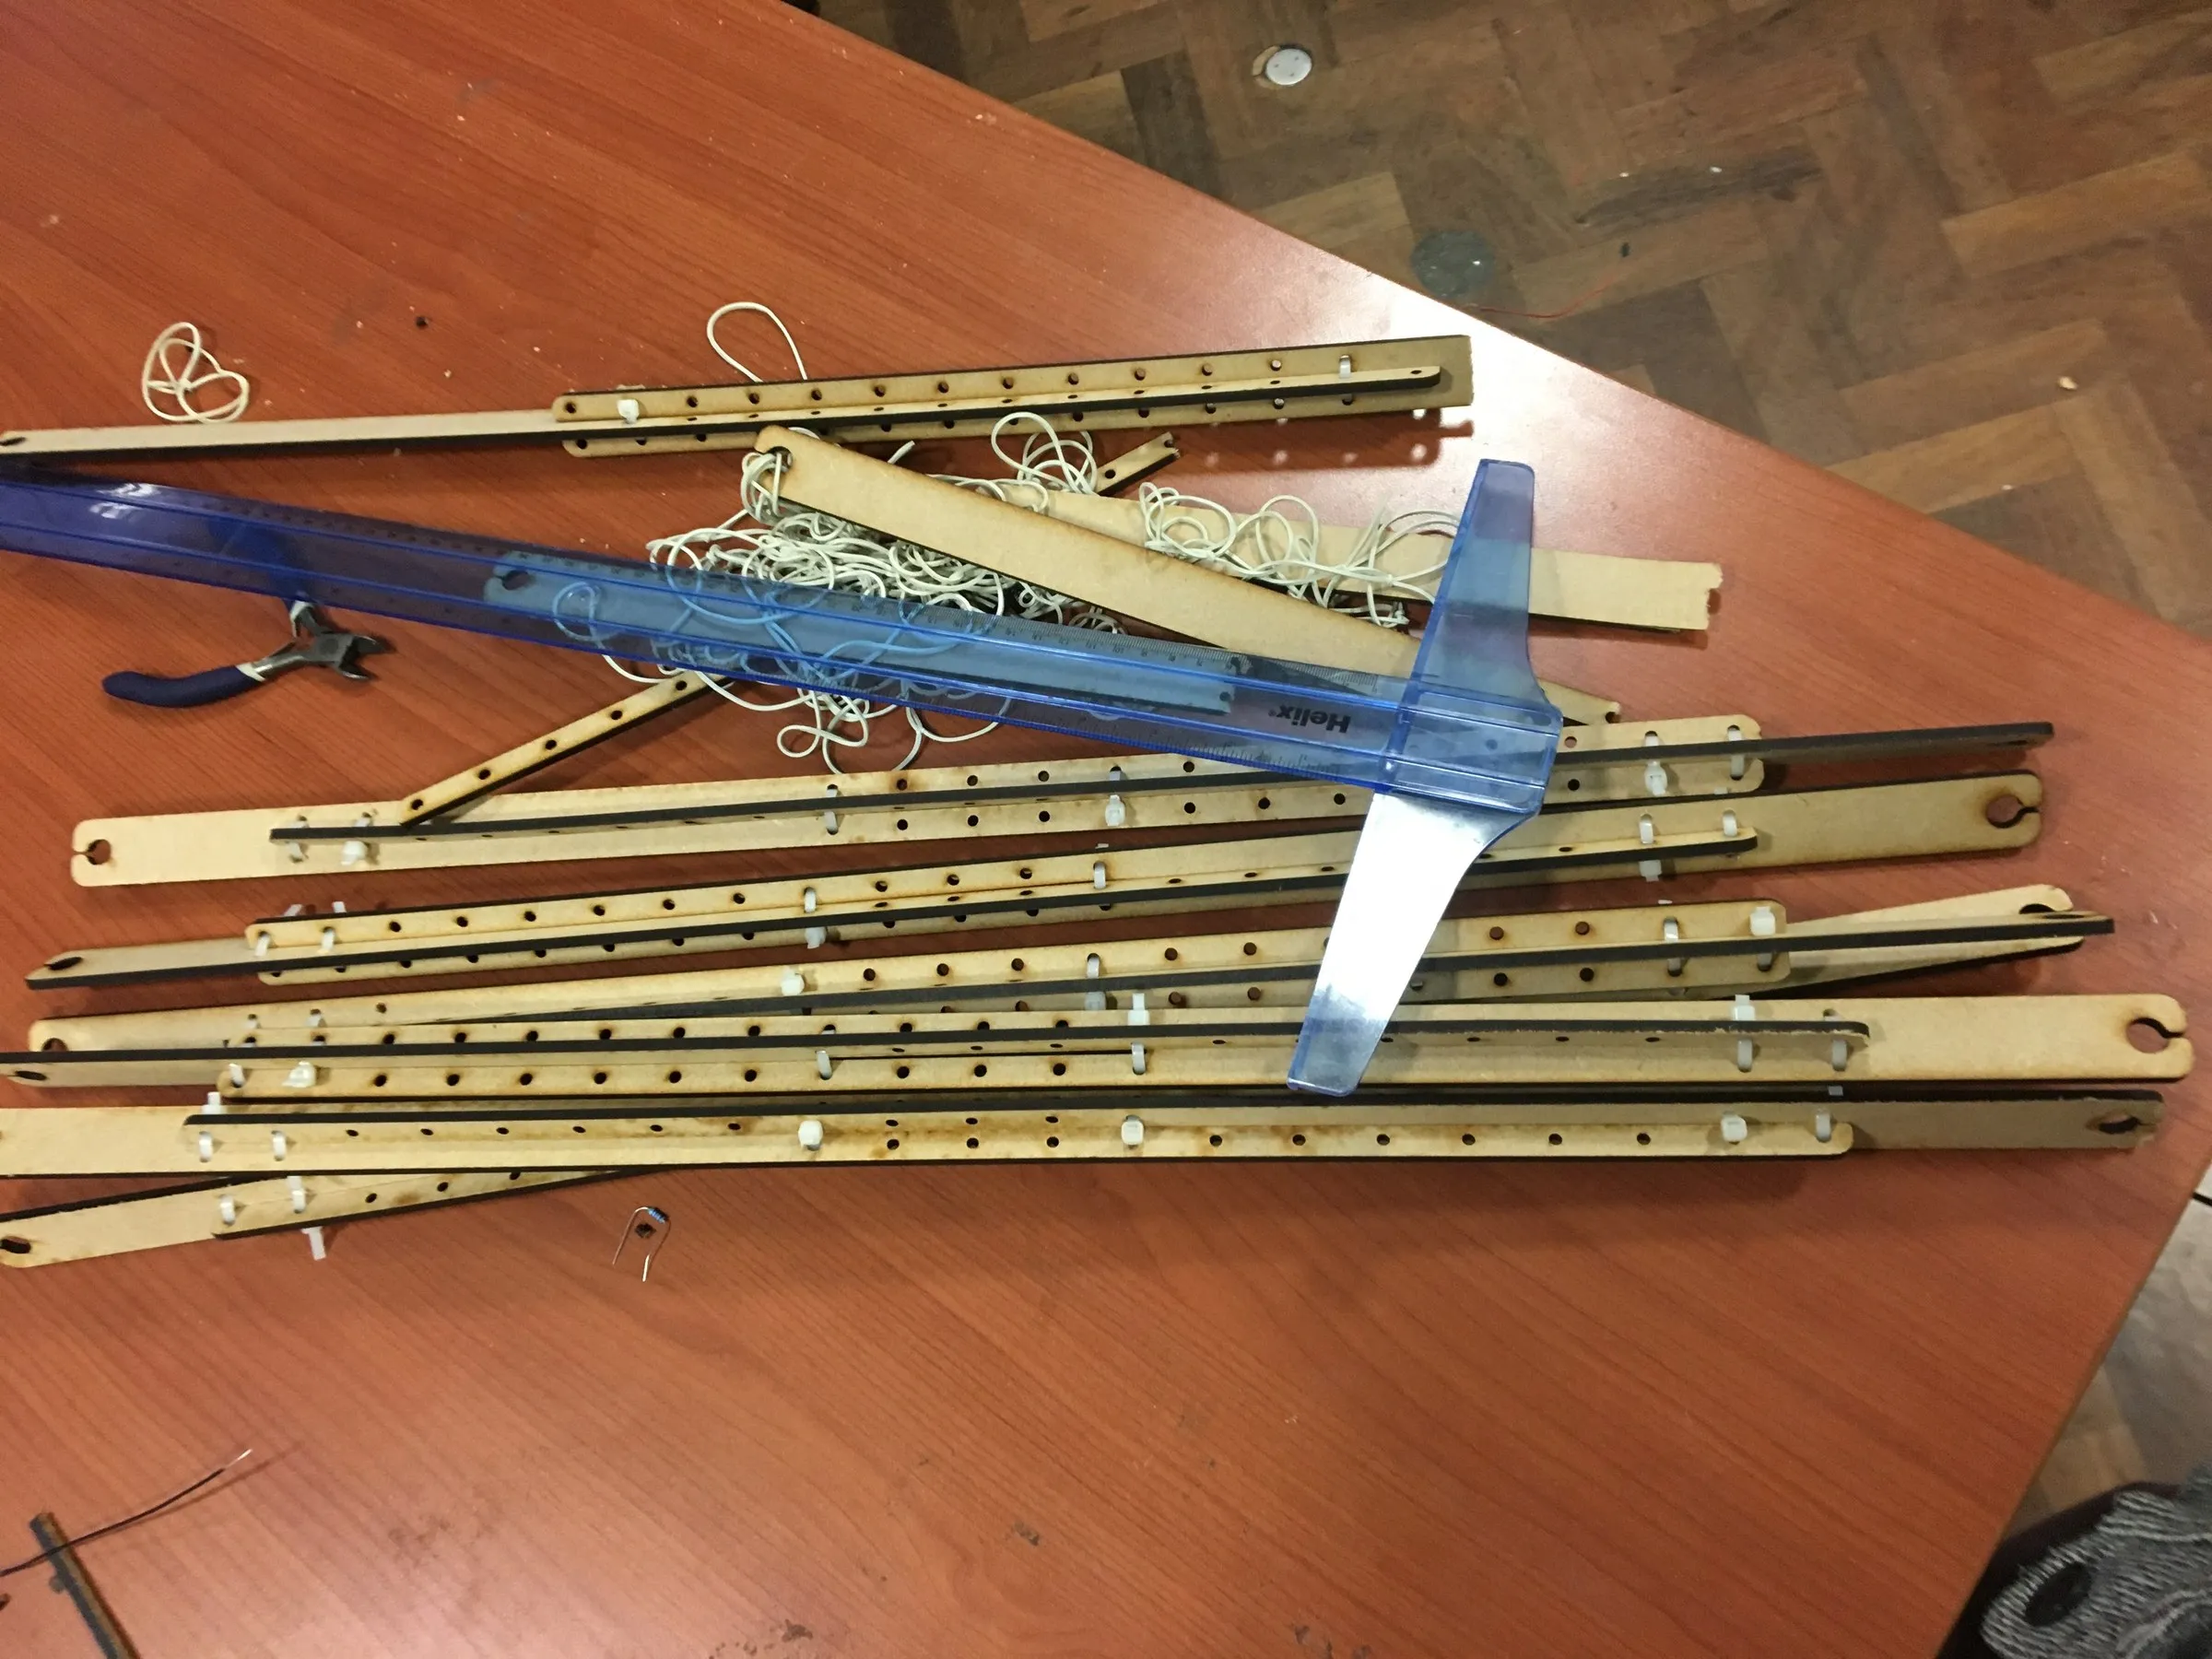
- Engineering design/development of tensegrity drone structure
Skills:
Optimization algorithms
Rapid prototyping
Tensegrity structure design