Michelangelo
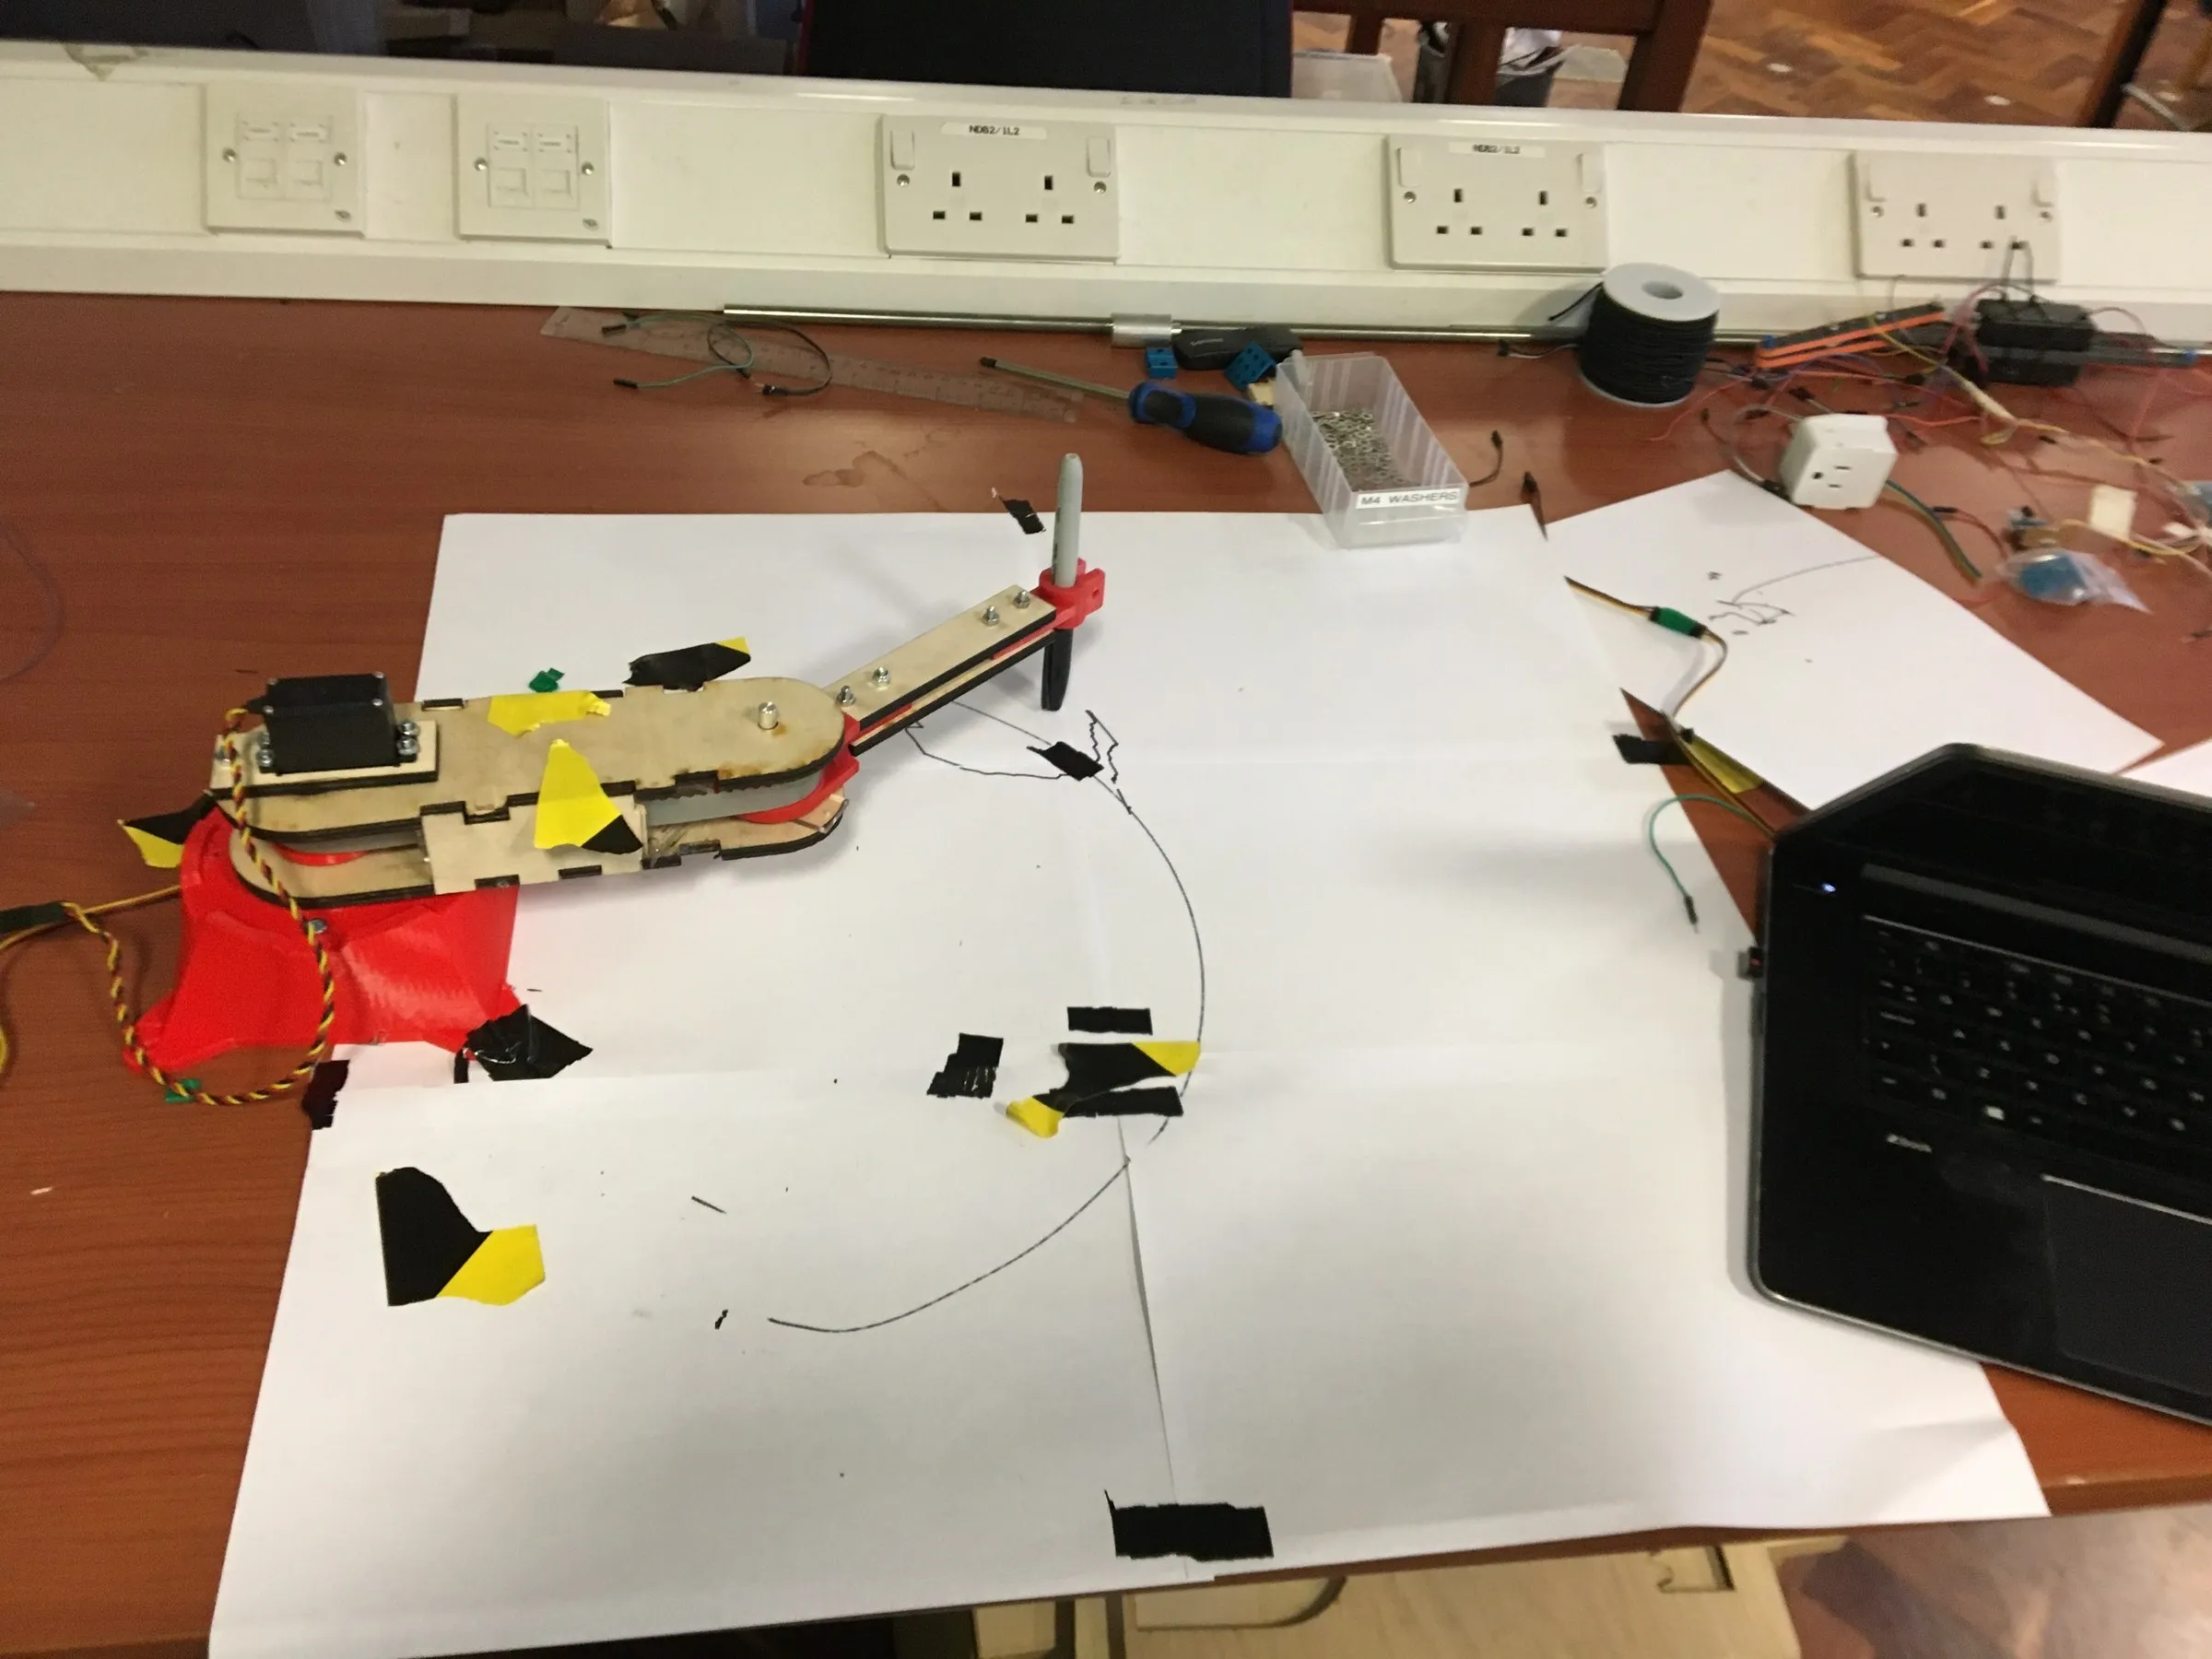
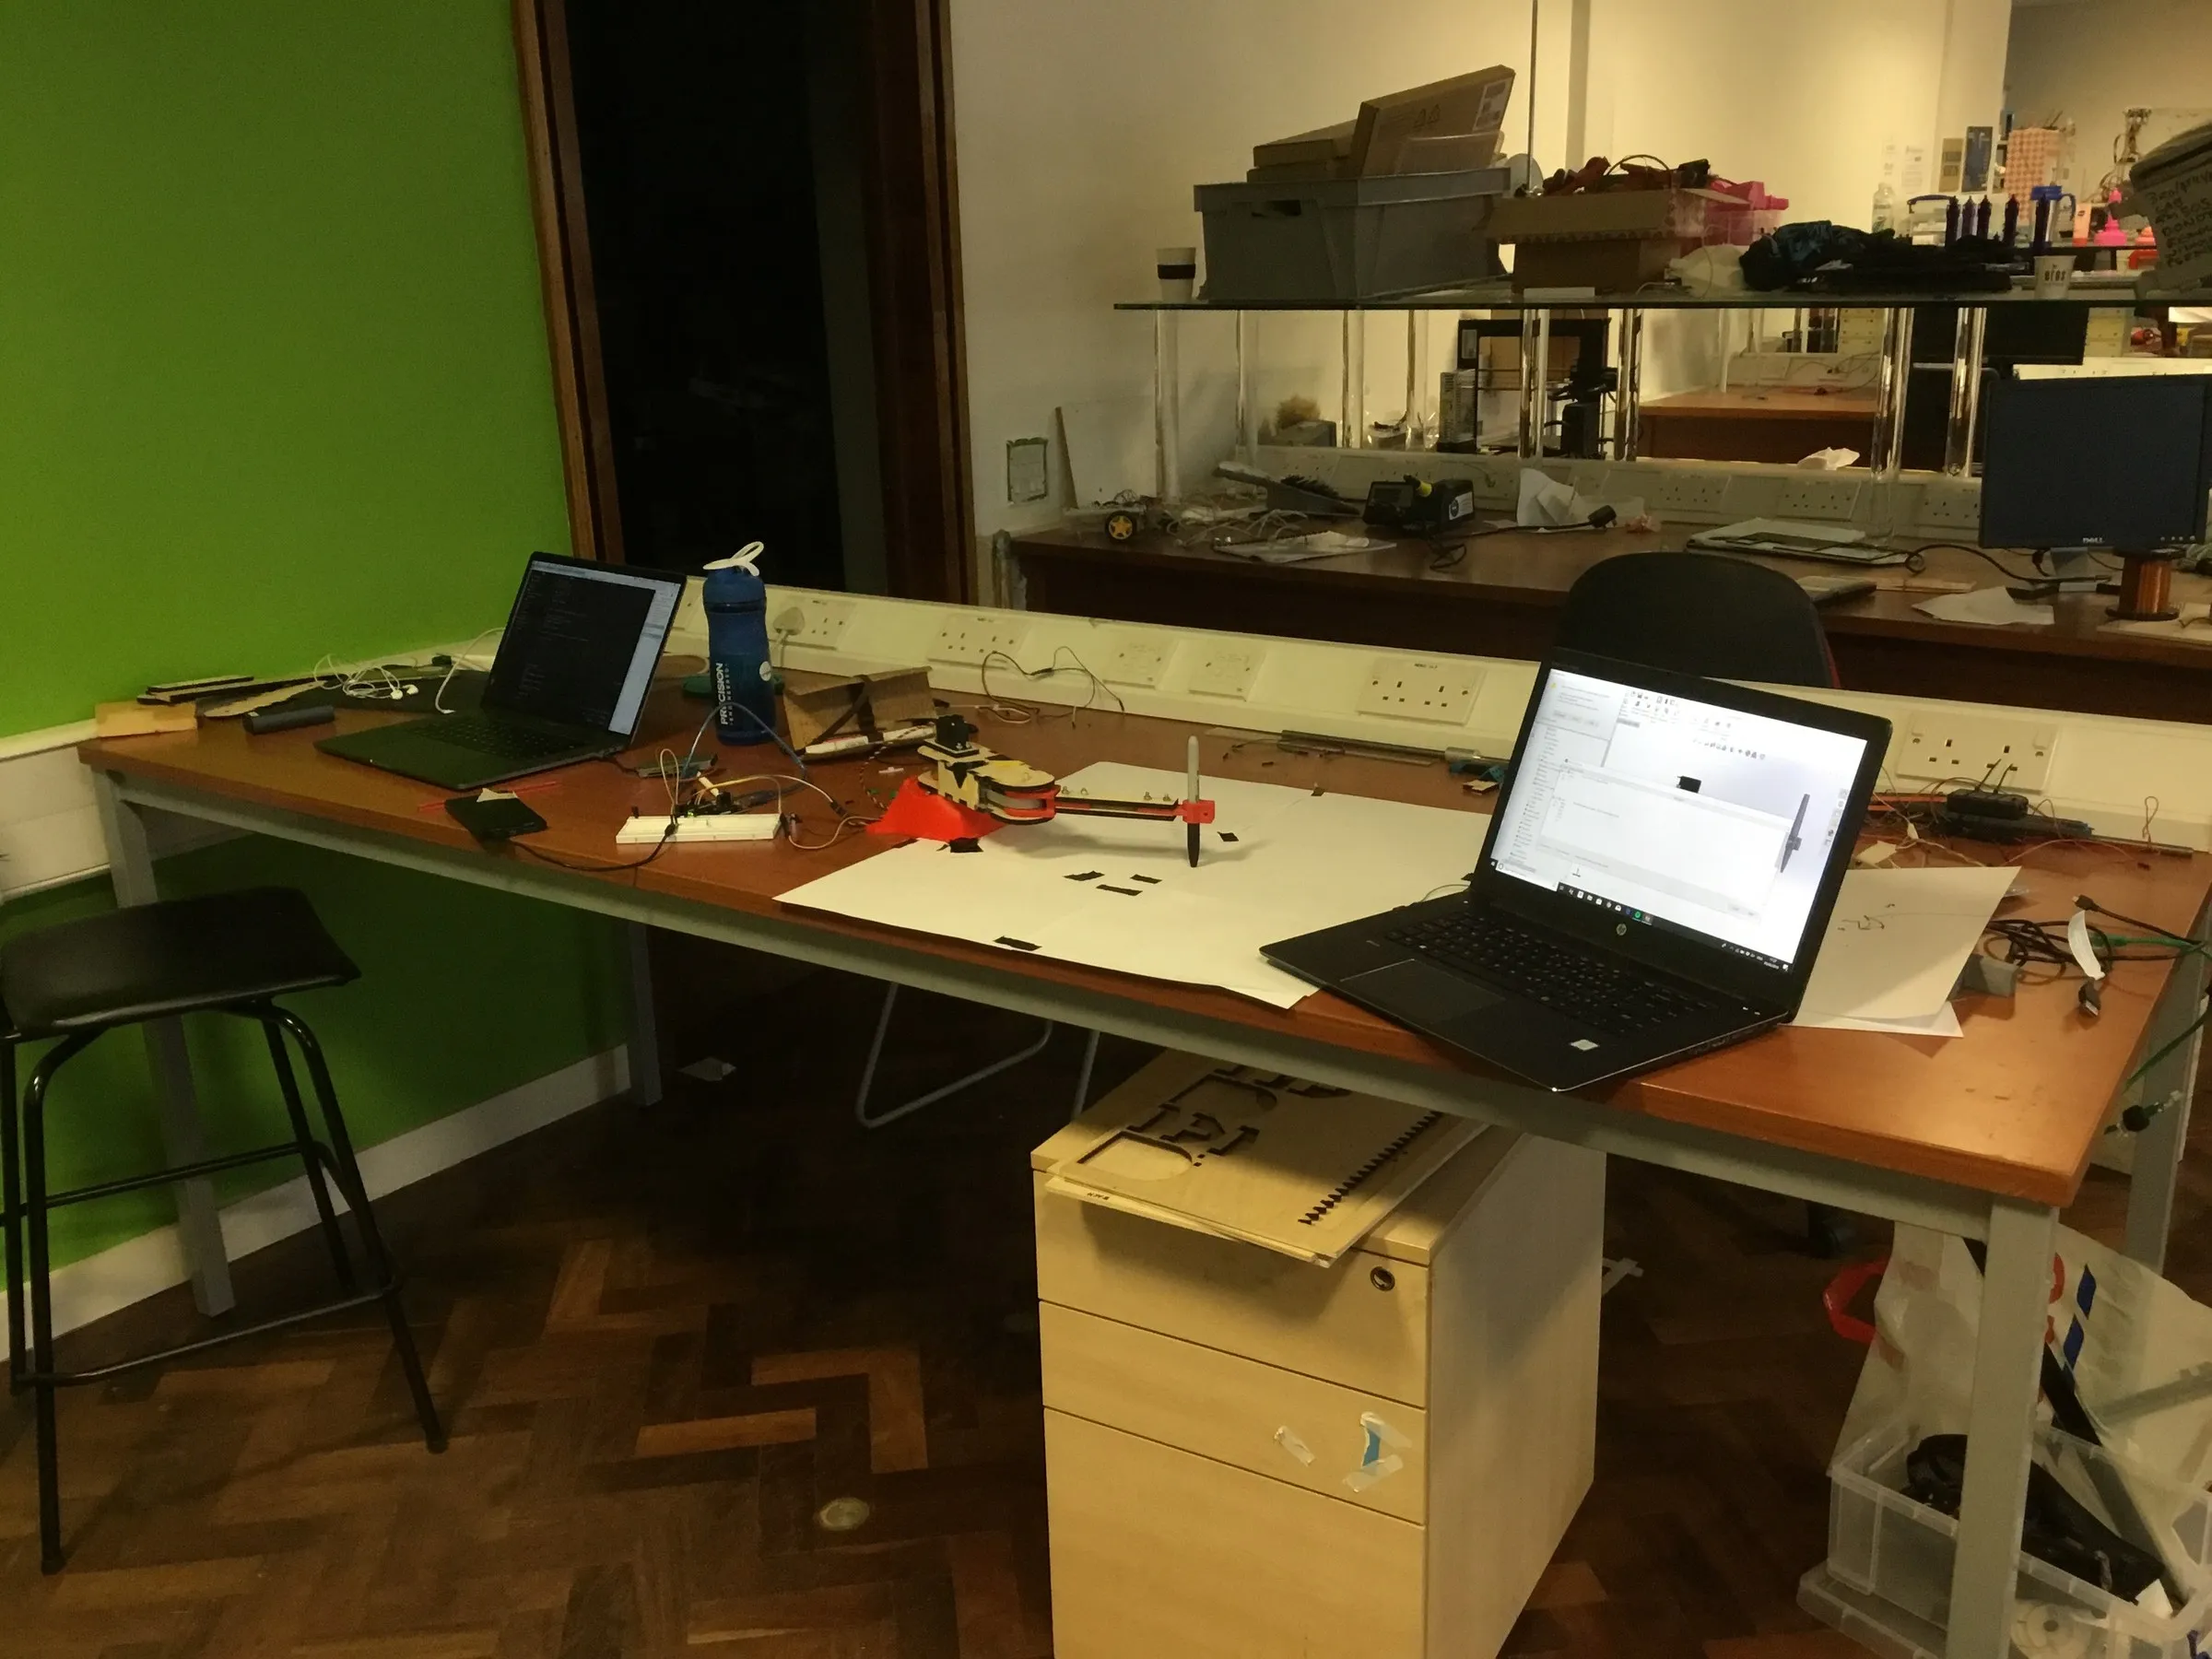
Michelangelo is a robotic artist. Building him was a personal project I worked on for a few weeks at the start of 2019.
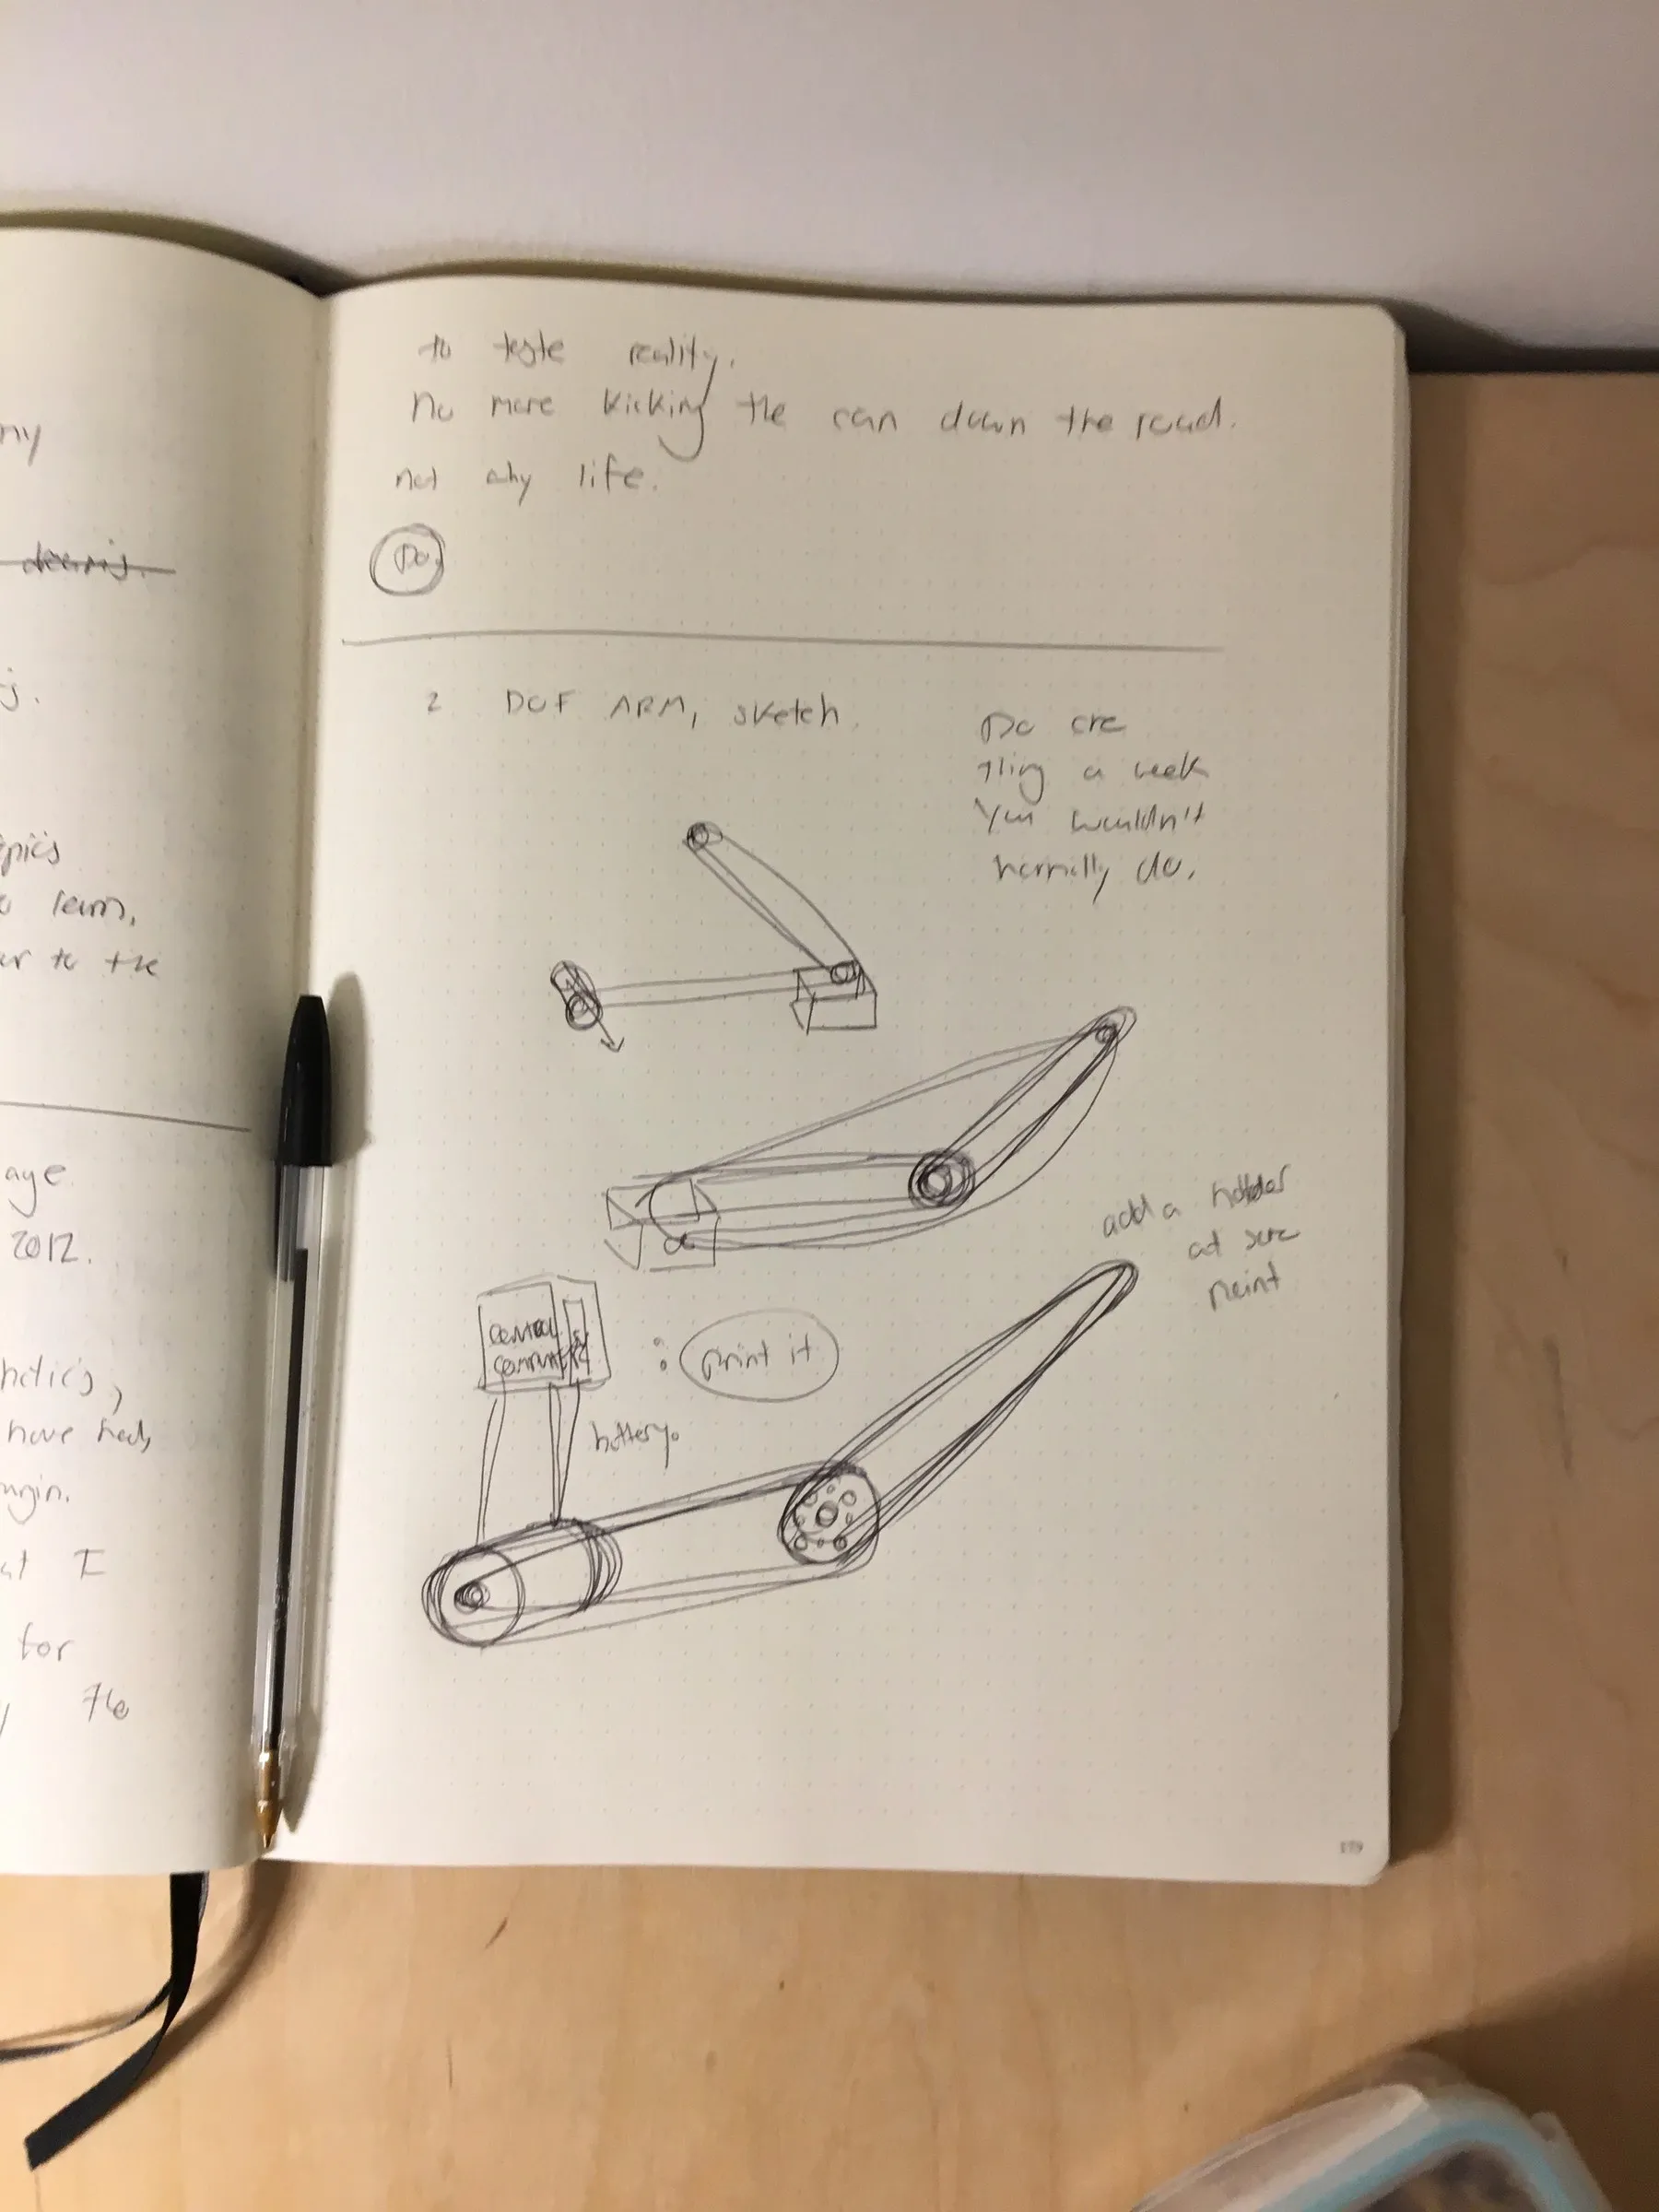
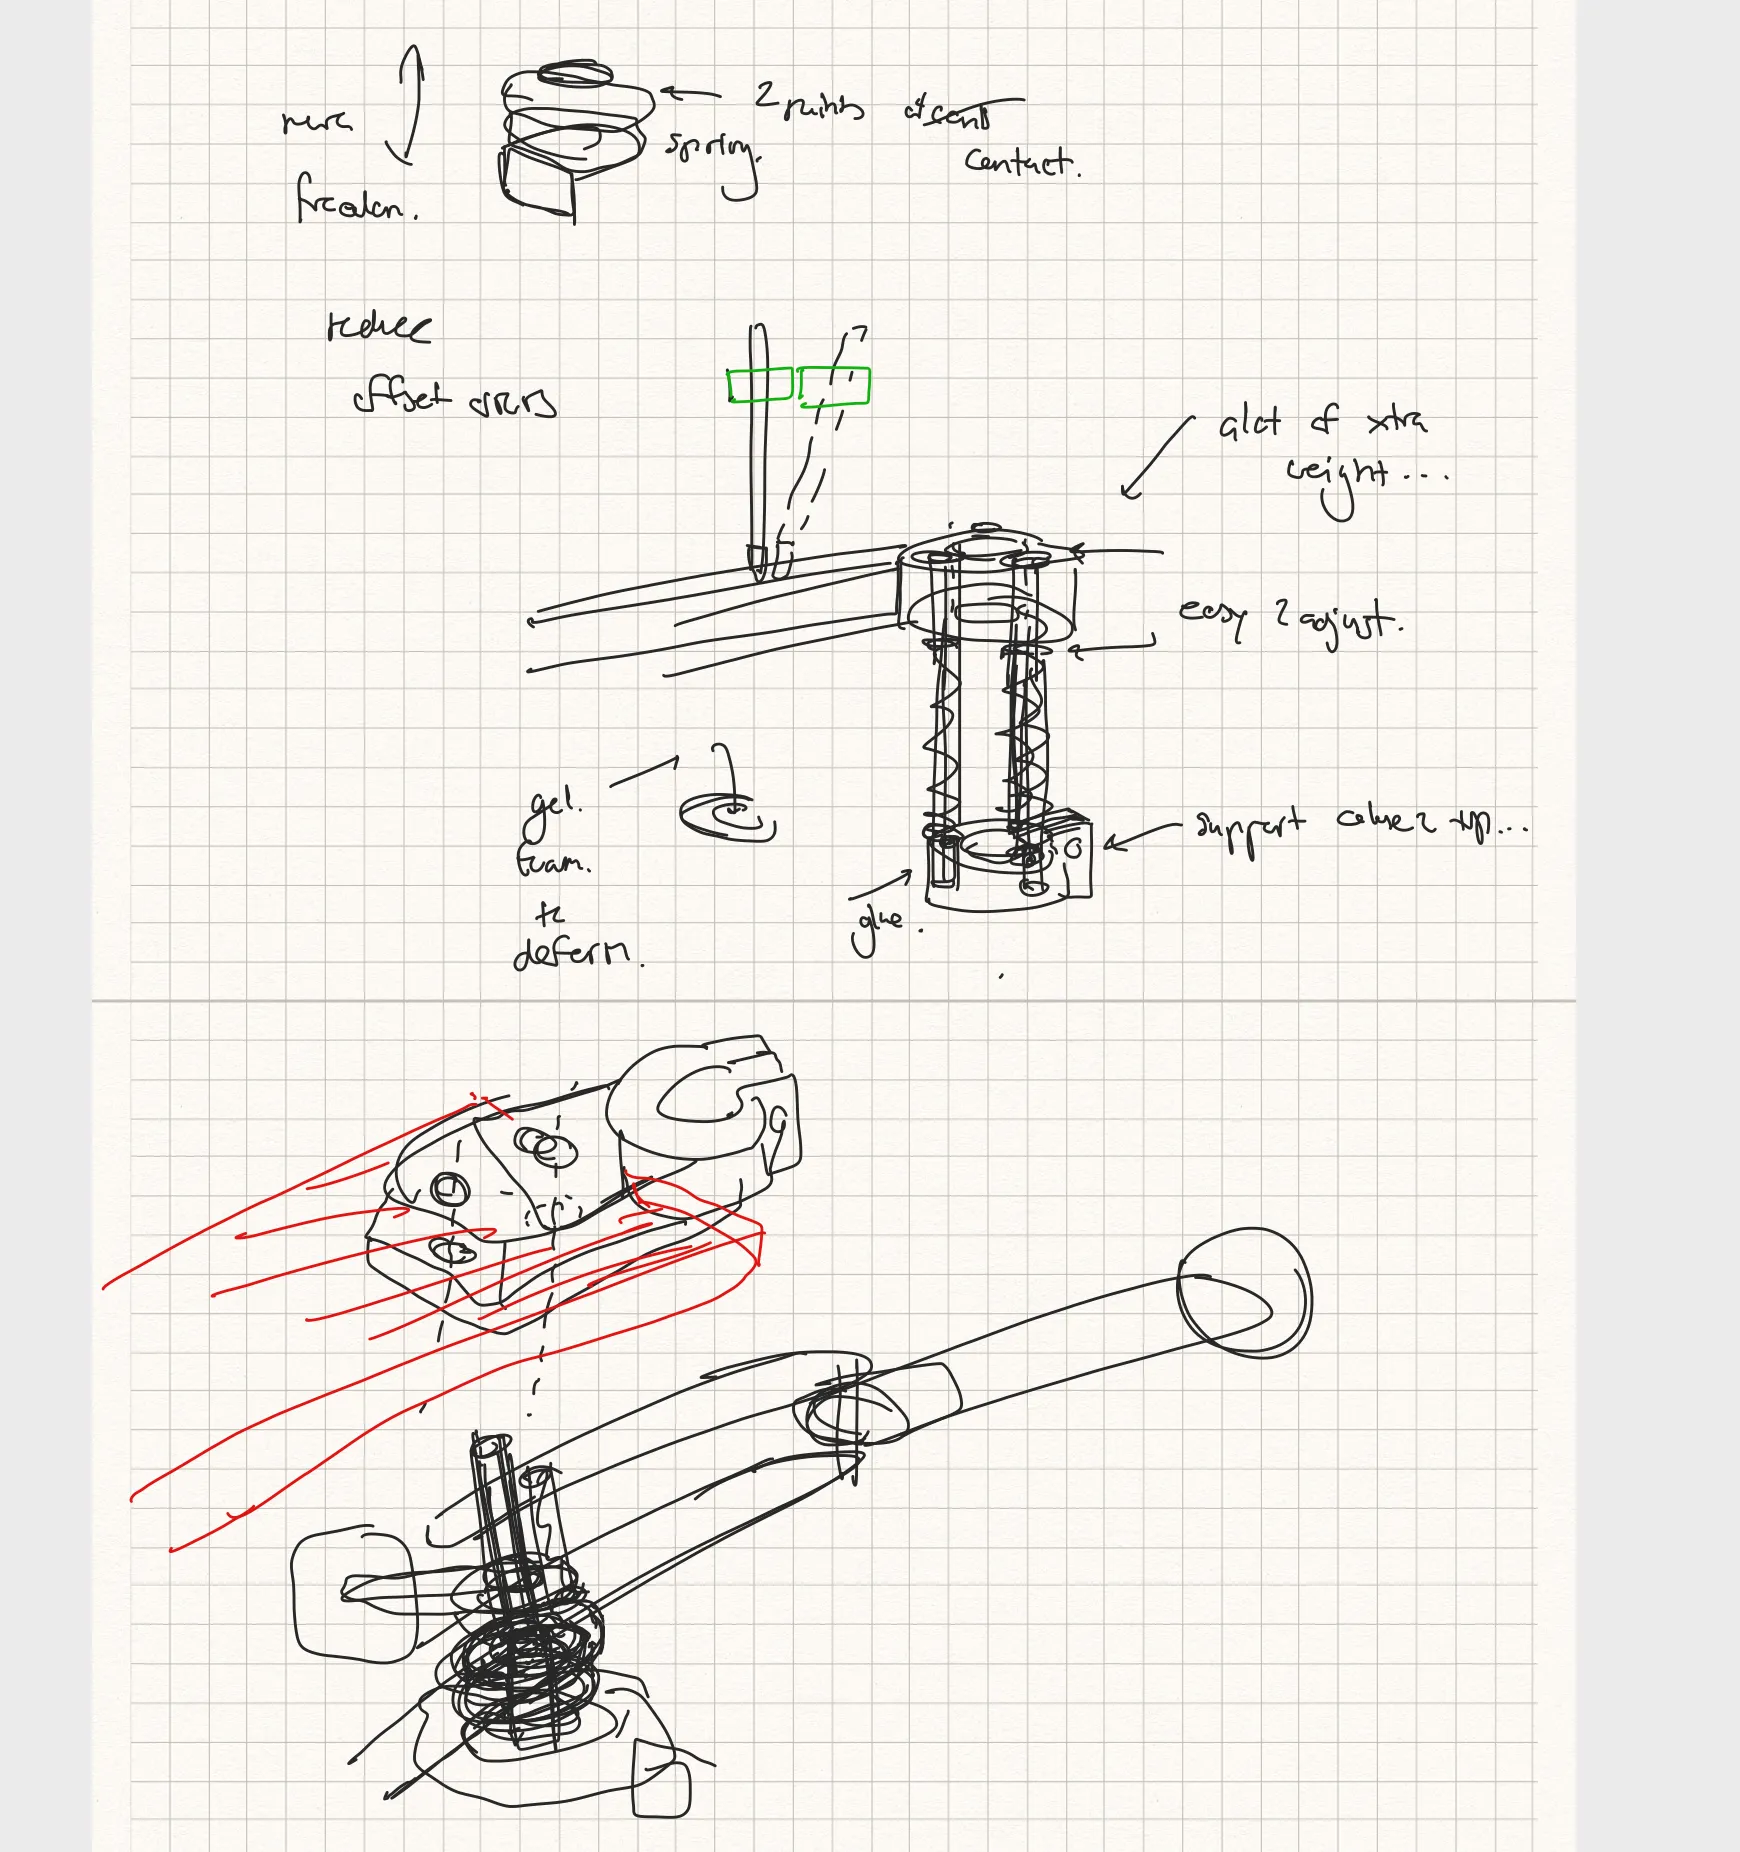
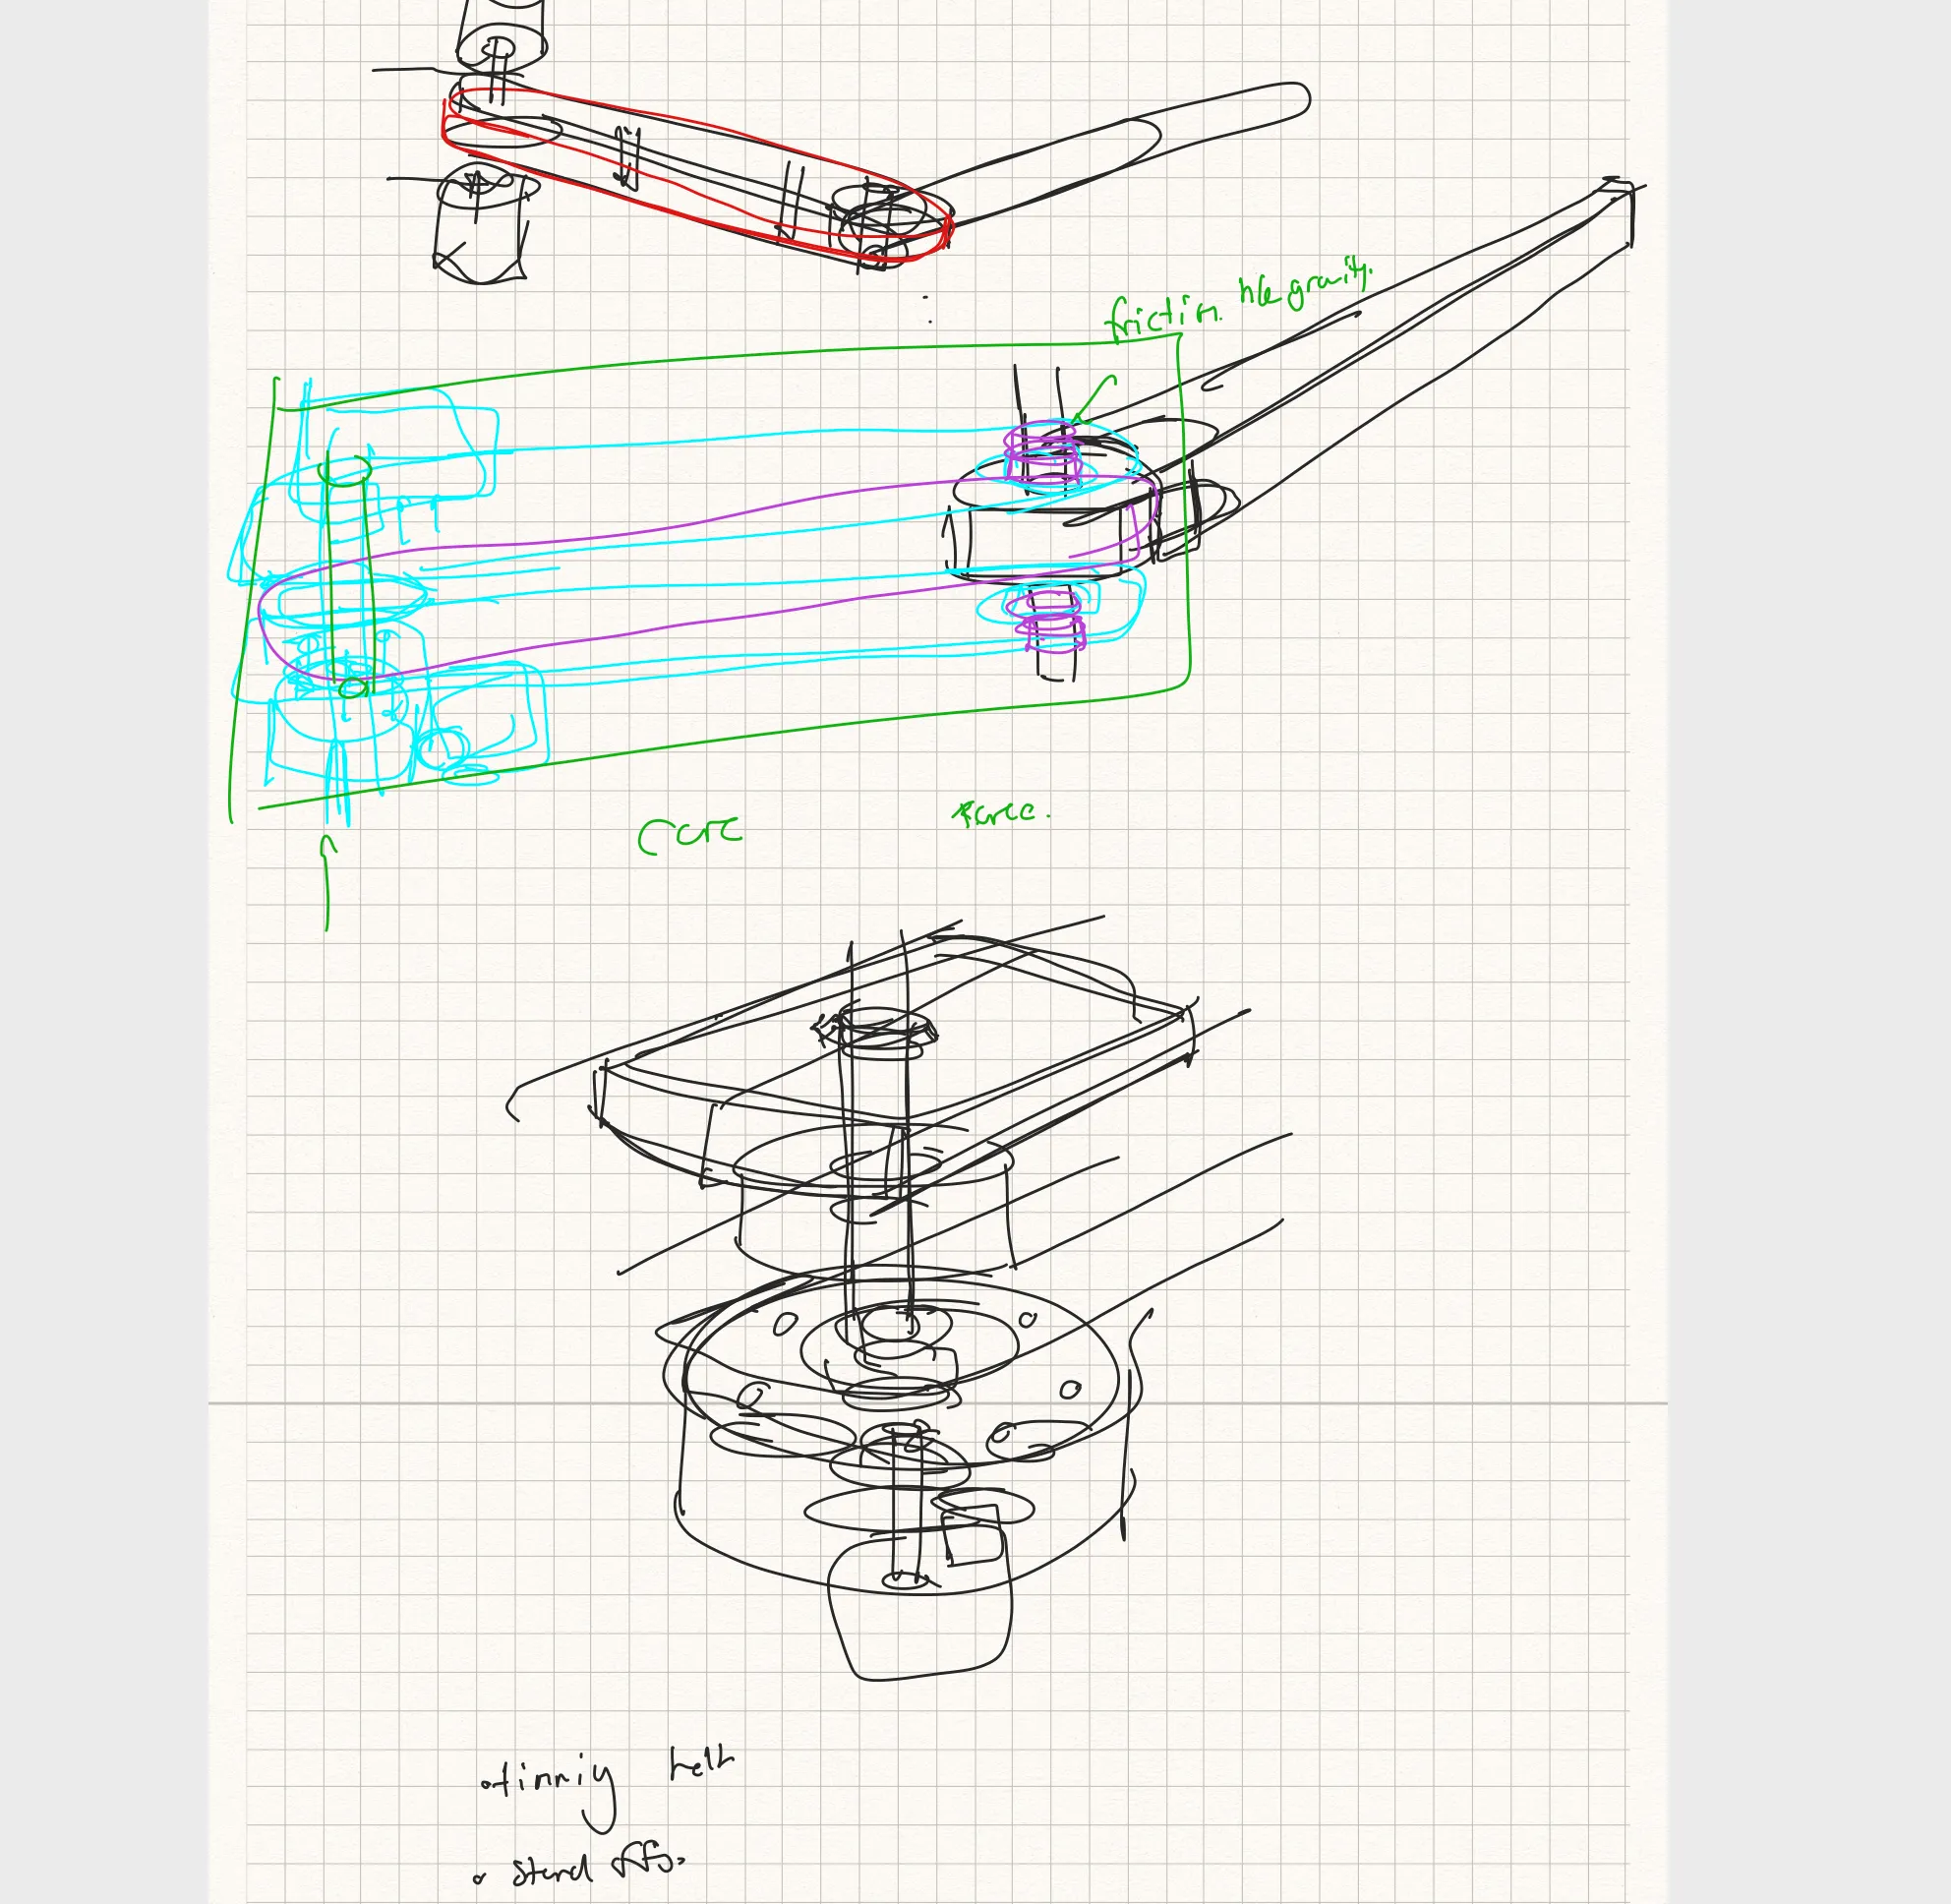
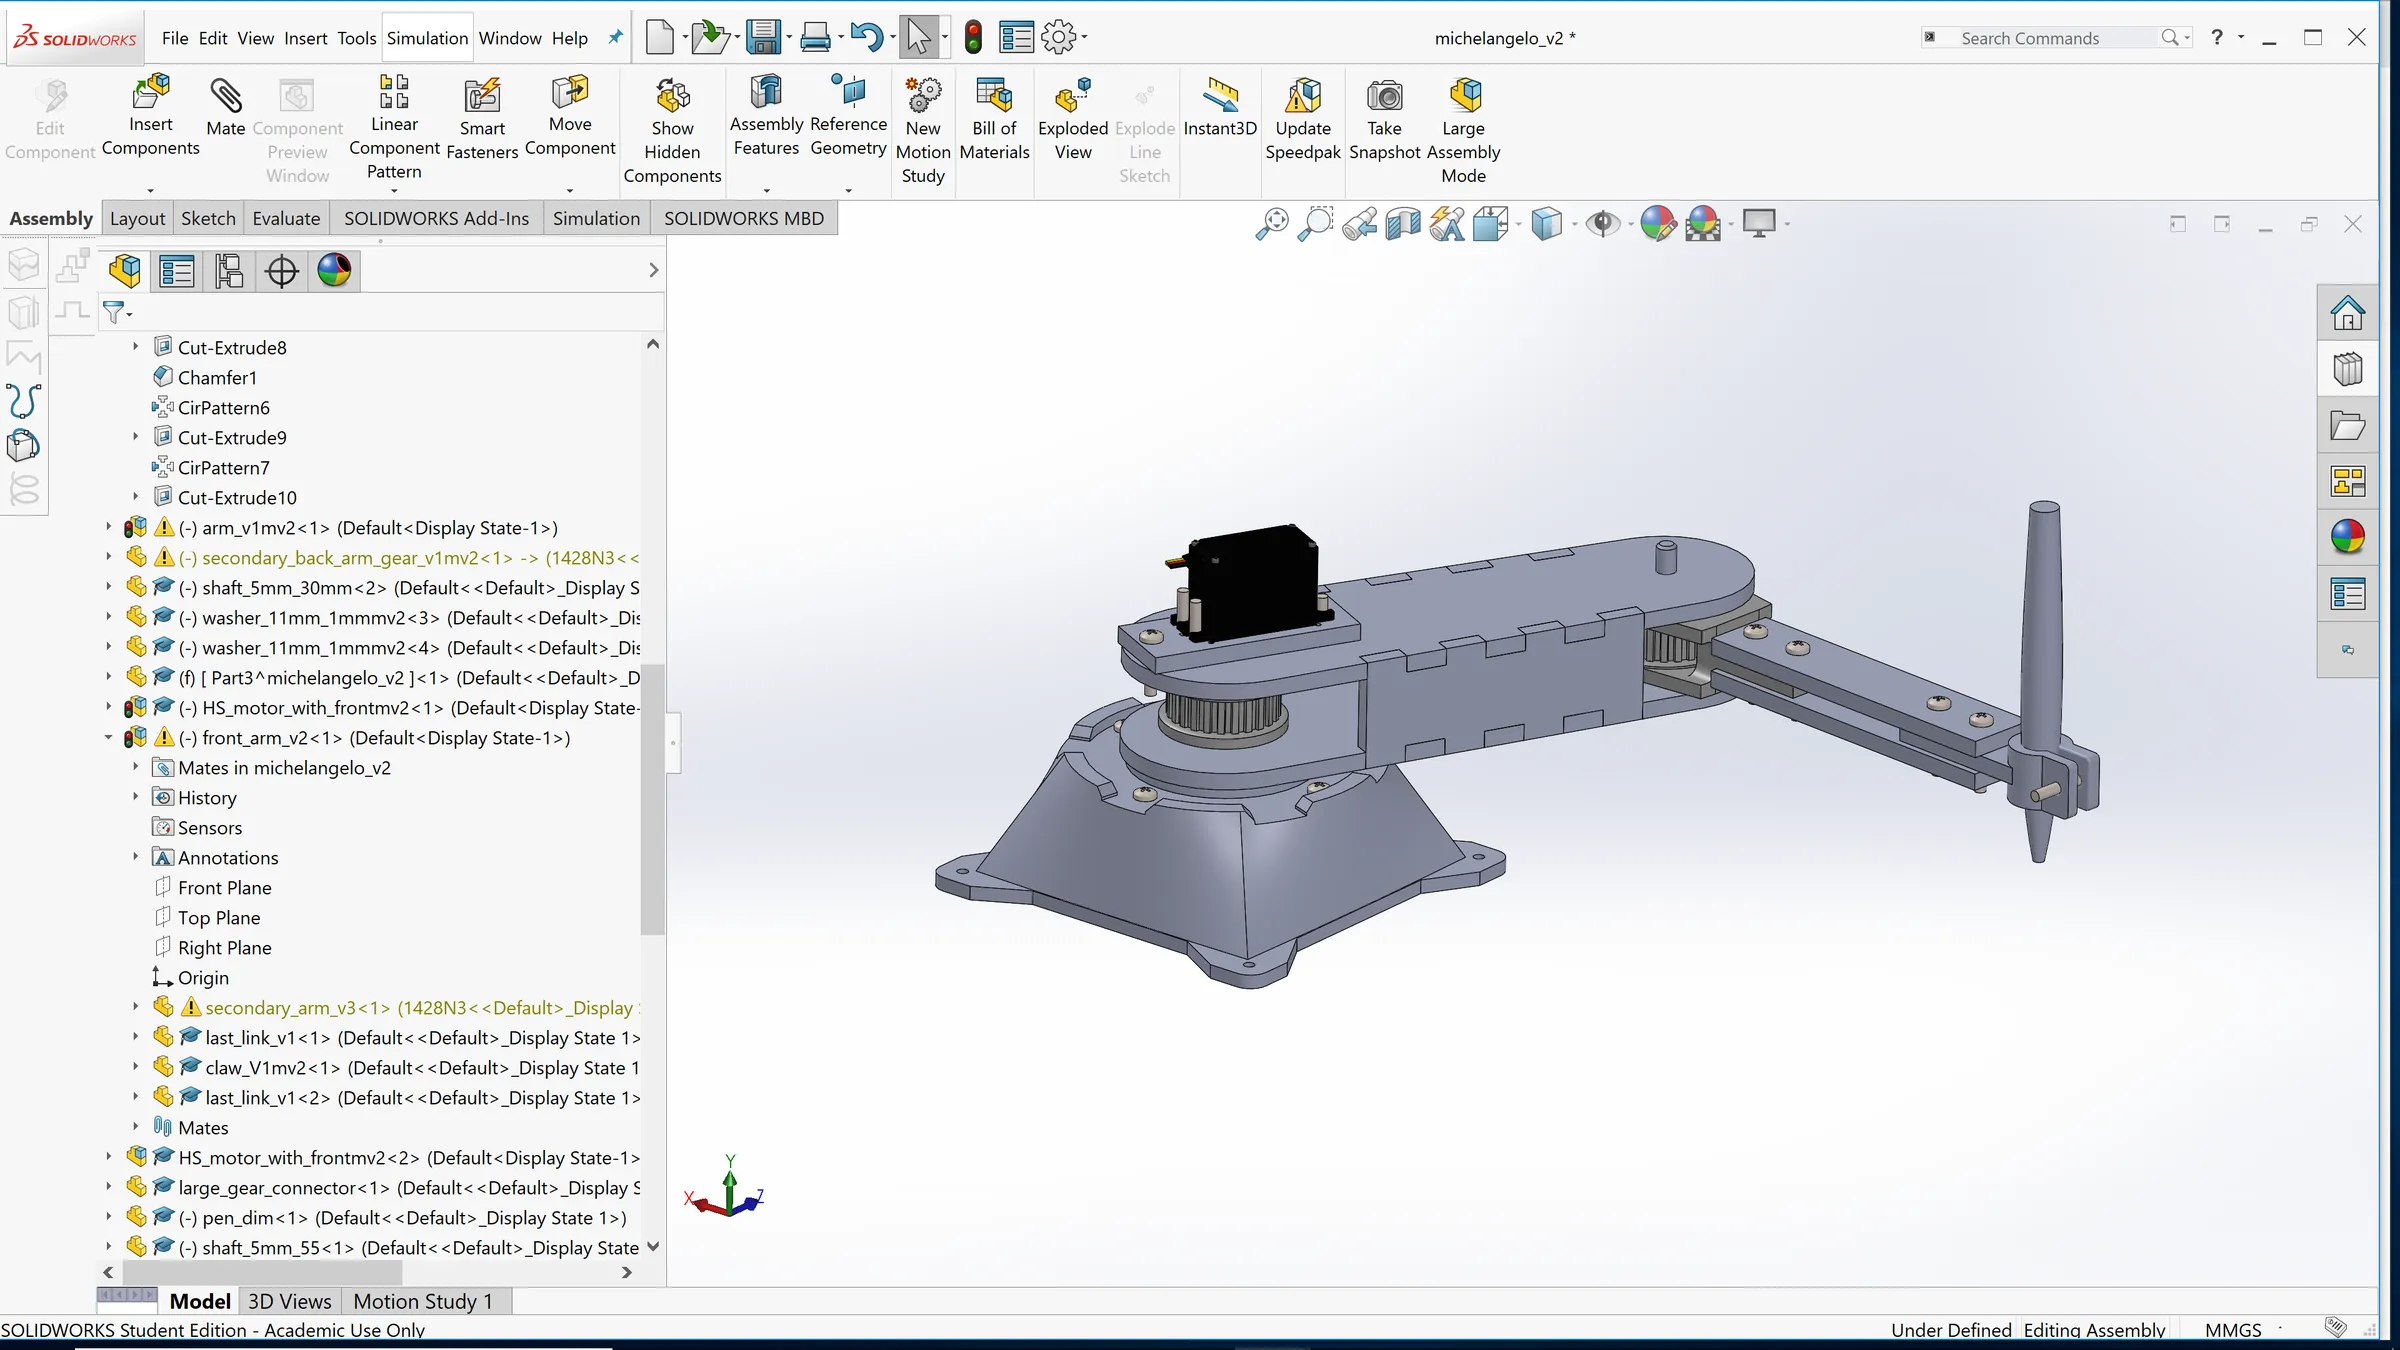
Hardware-wise, I started with started with a sketch and then moved to Solidworks for detailed part design. I milled 3 shafts, laser cut the arm, and 3D printed the timing belt gears and base. Michelangelo uses two servos with 1-degree resolution (hence the jittery lines) connected to an external power supply and controlled from an Arduino.
Software-wise, all computation is done by computer and sent to the Arduino. Downsampling and thresholding of the letter images are done using OpenCV. Pixels of the letter shapes then become x y coordinates for a DFS path planner. IK’s is used to determine joint angles for each position, which are then sent directly to the servos.
I sent this video to London robotic startup, Automata, which helped me secure a 6-month placement in 2019
Skills:
Robotics
Rapid Prototyping
Image Processing