Robo-Wall
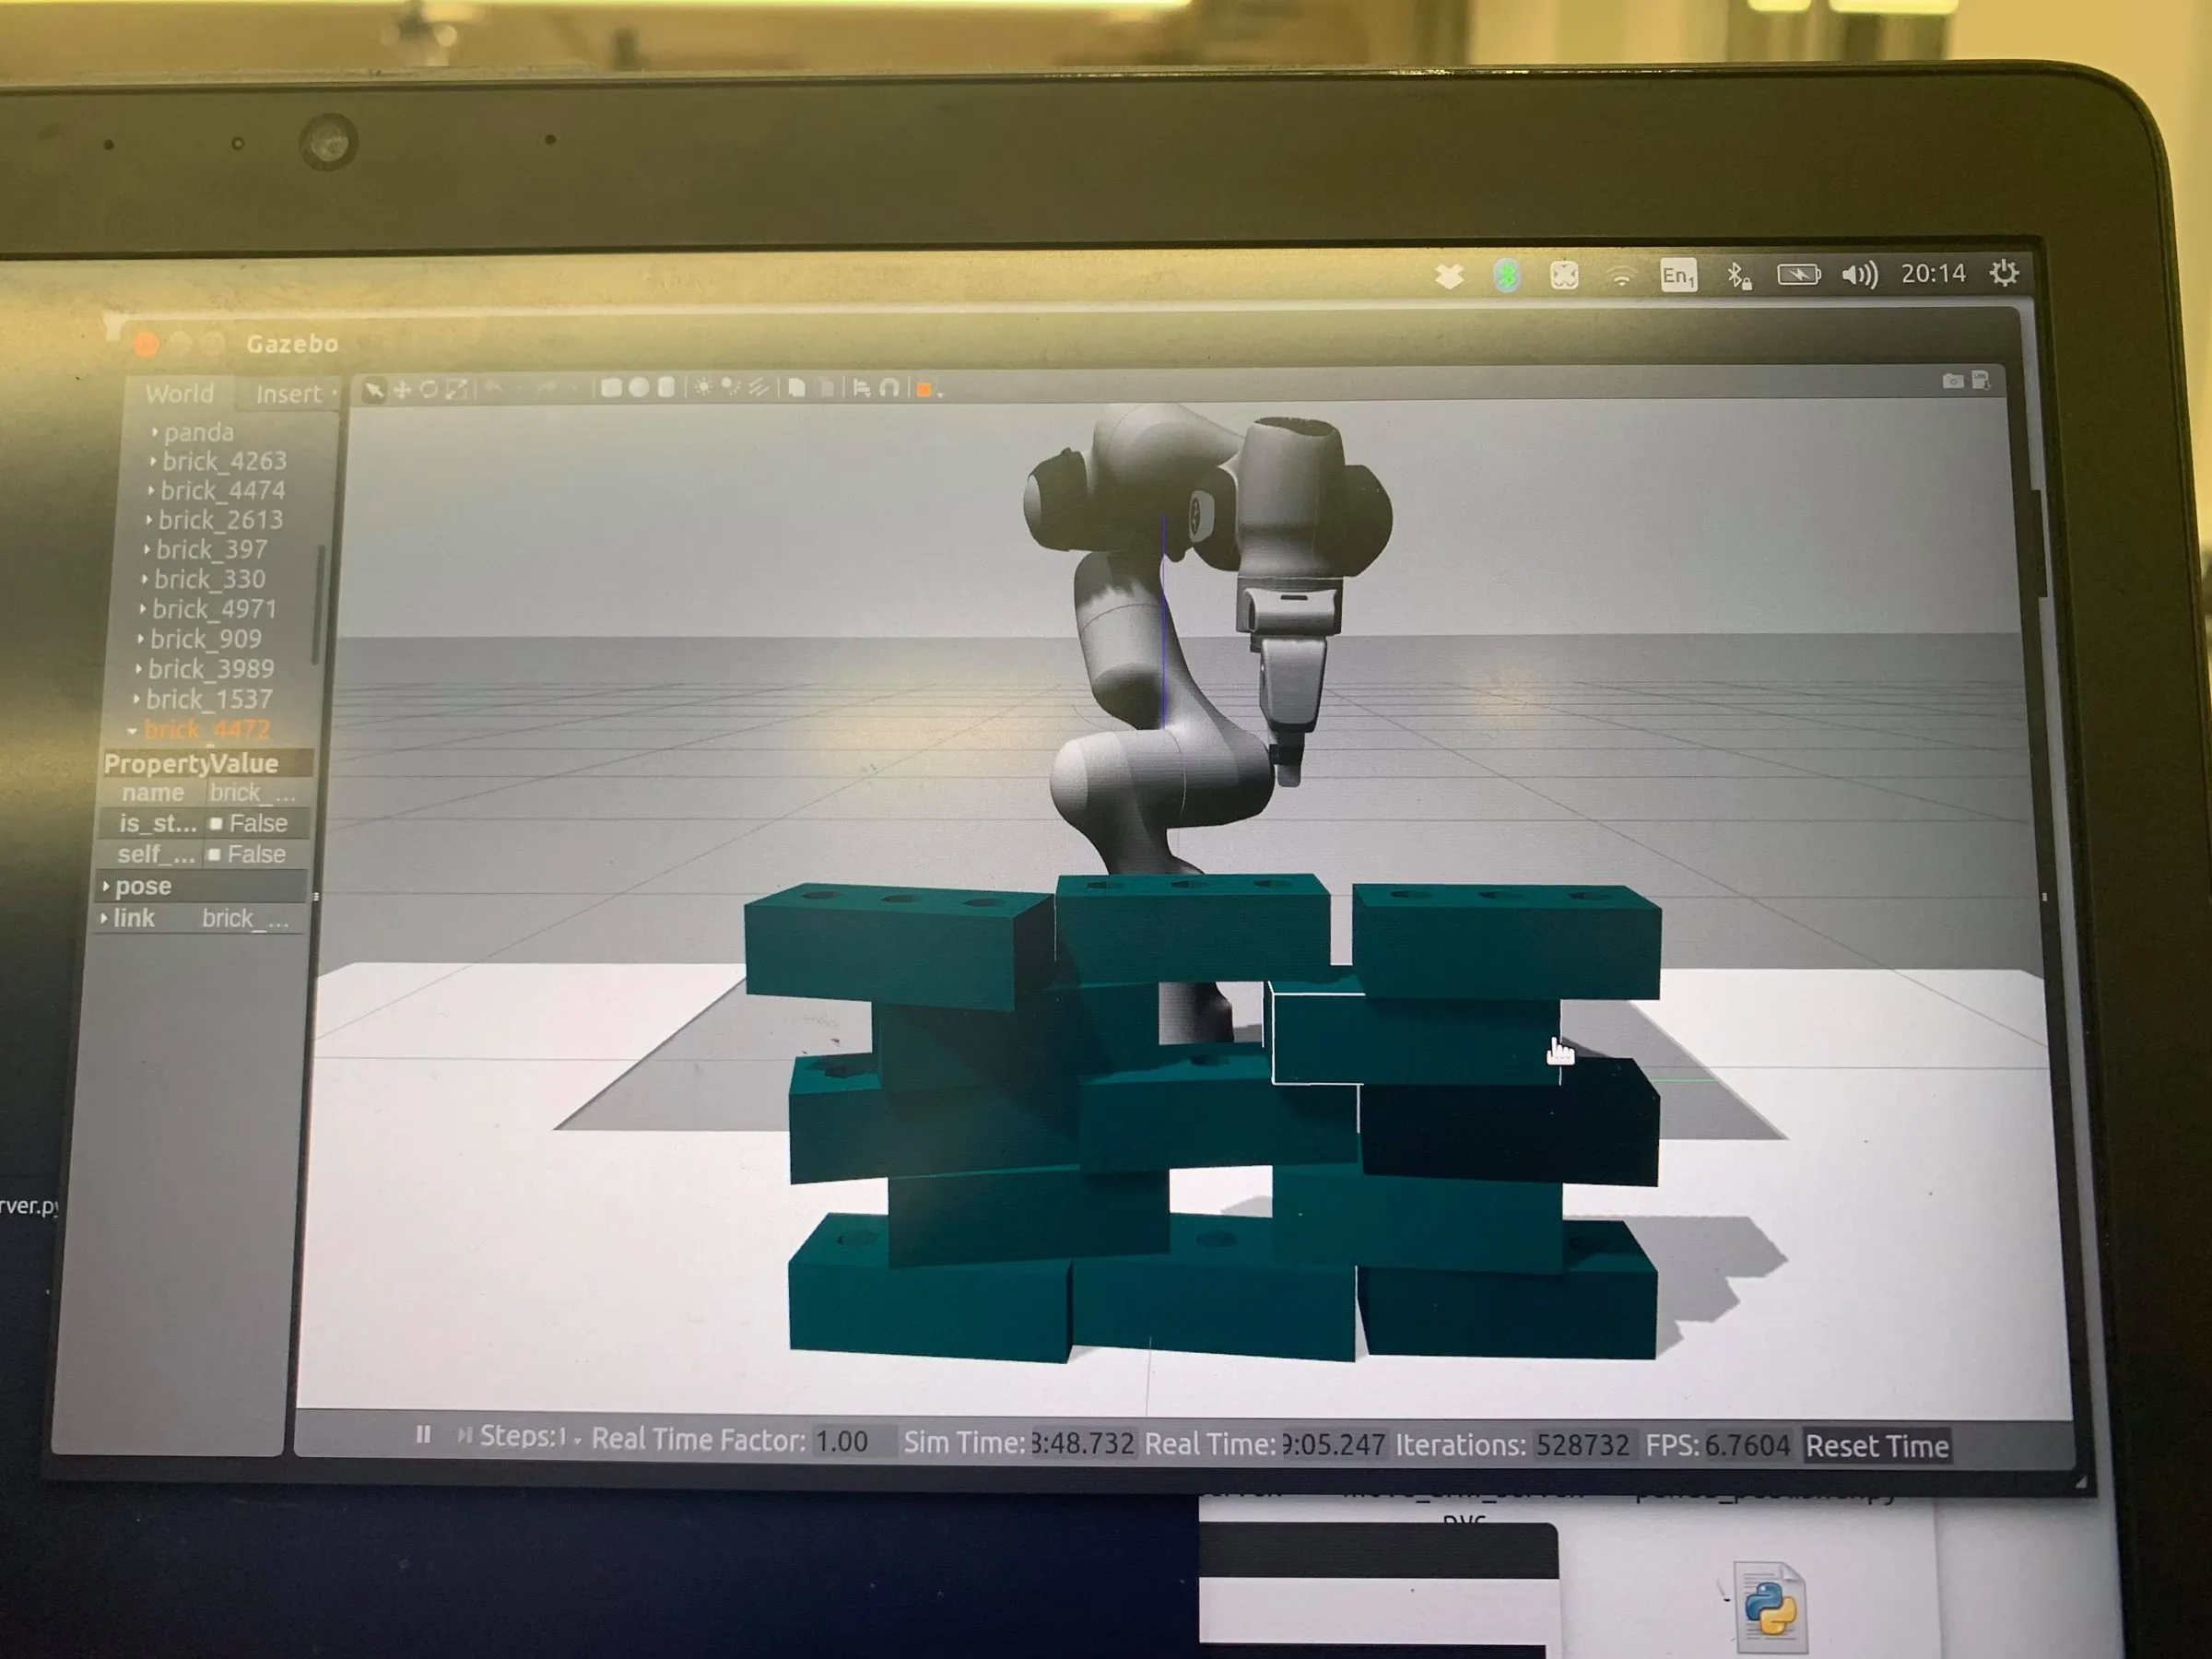
This Robotics project took place at the Dyson School of Engineering at the start of 2019. ROS was used to program an industrial Franka Panda Robot to perform pick and place task of foam bricks. My contribution involved:
- Designing/implementing path planner for brick placement
- Implementation of robot control through MoveIt!
- Interfacing code with the real robot
The ultimate outcome of this project was constructing a brick high wall using the robot.
Click for Project Documentation:
https://de3-panda-wall.readthedocs.io/en/latest/home.html
Skills:
ROS
Robot Programming