A Self-Balancing Robot
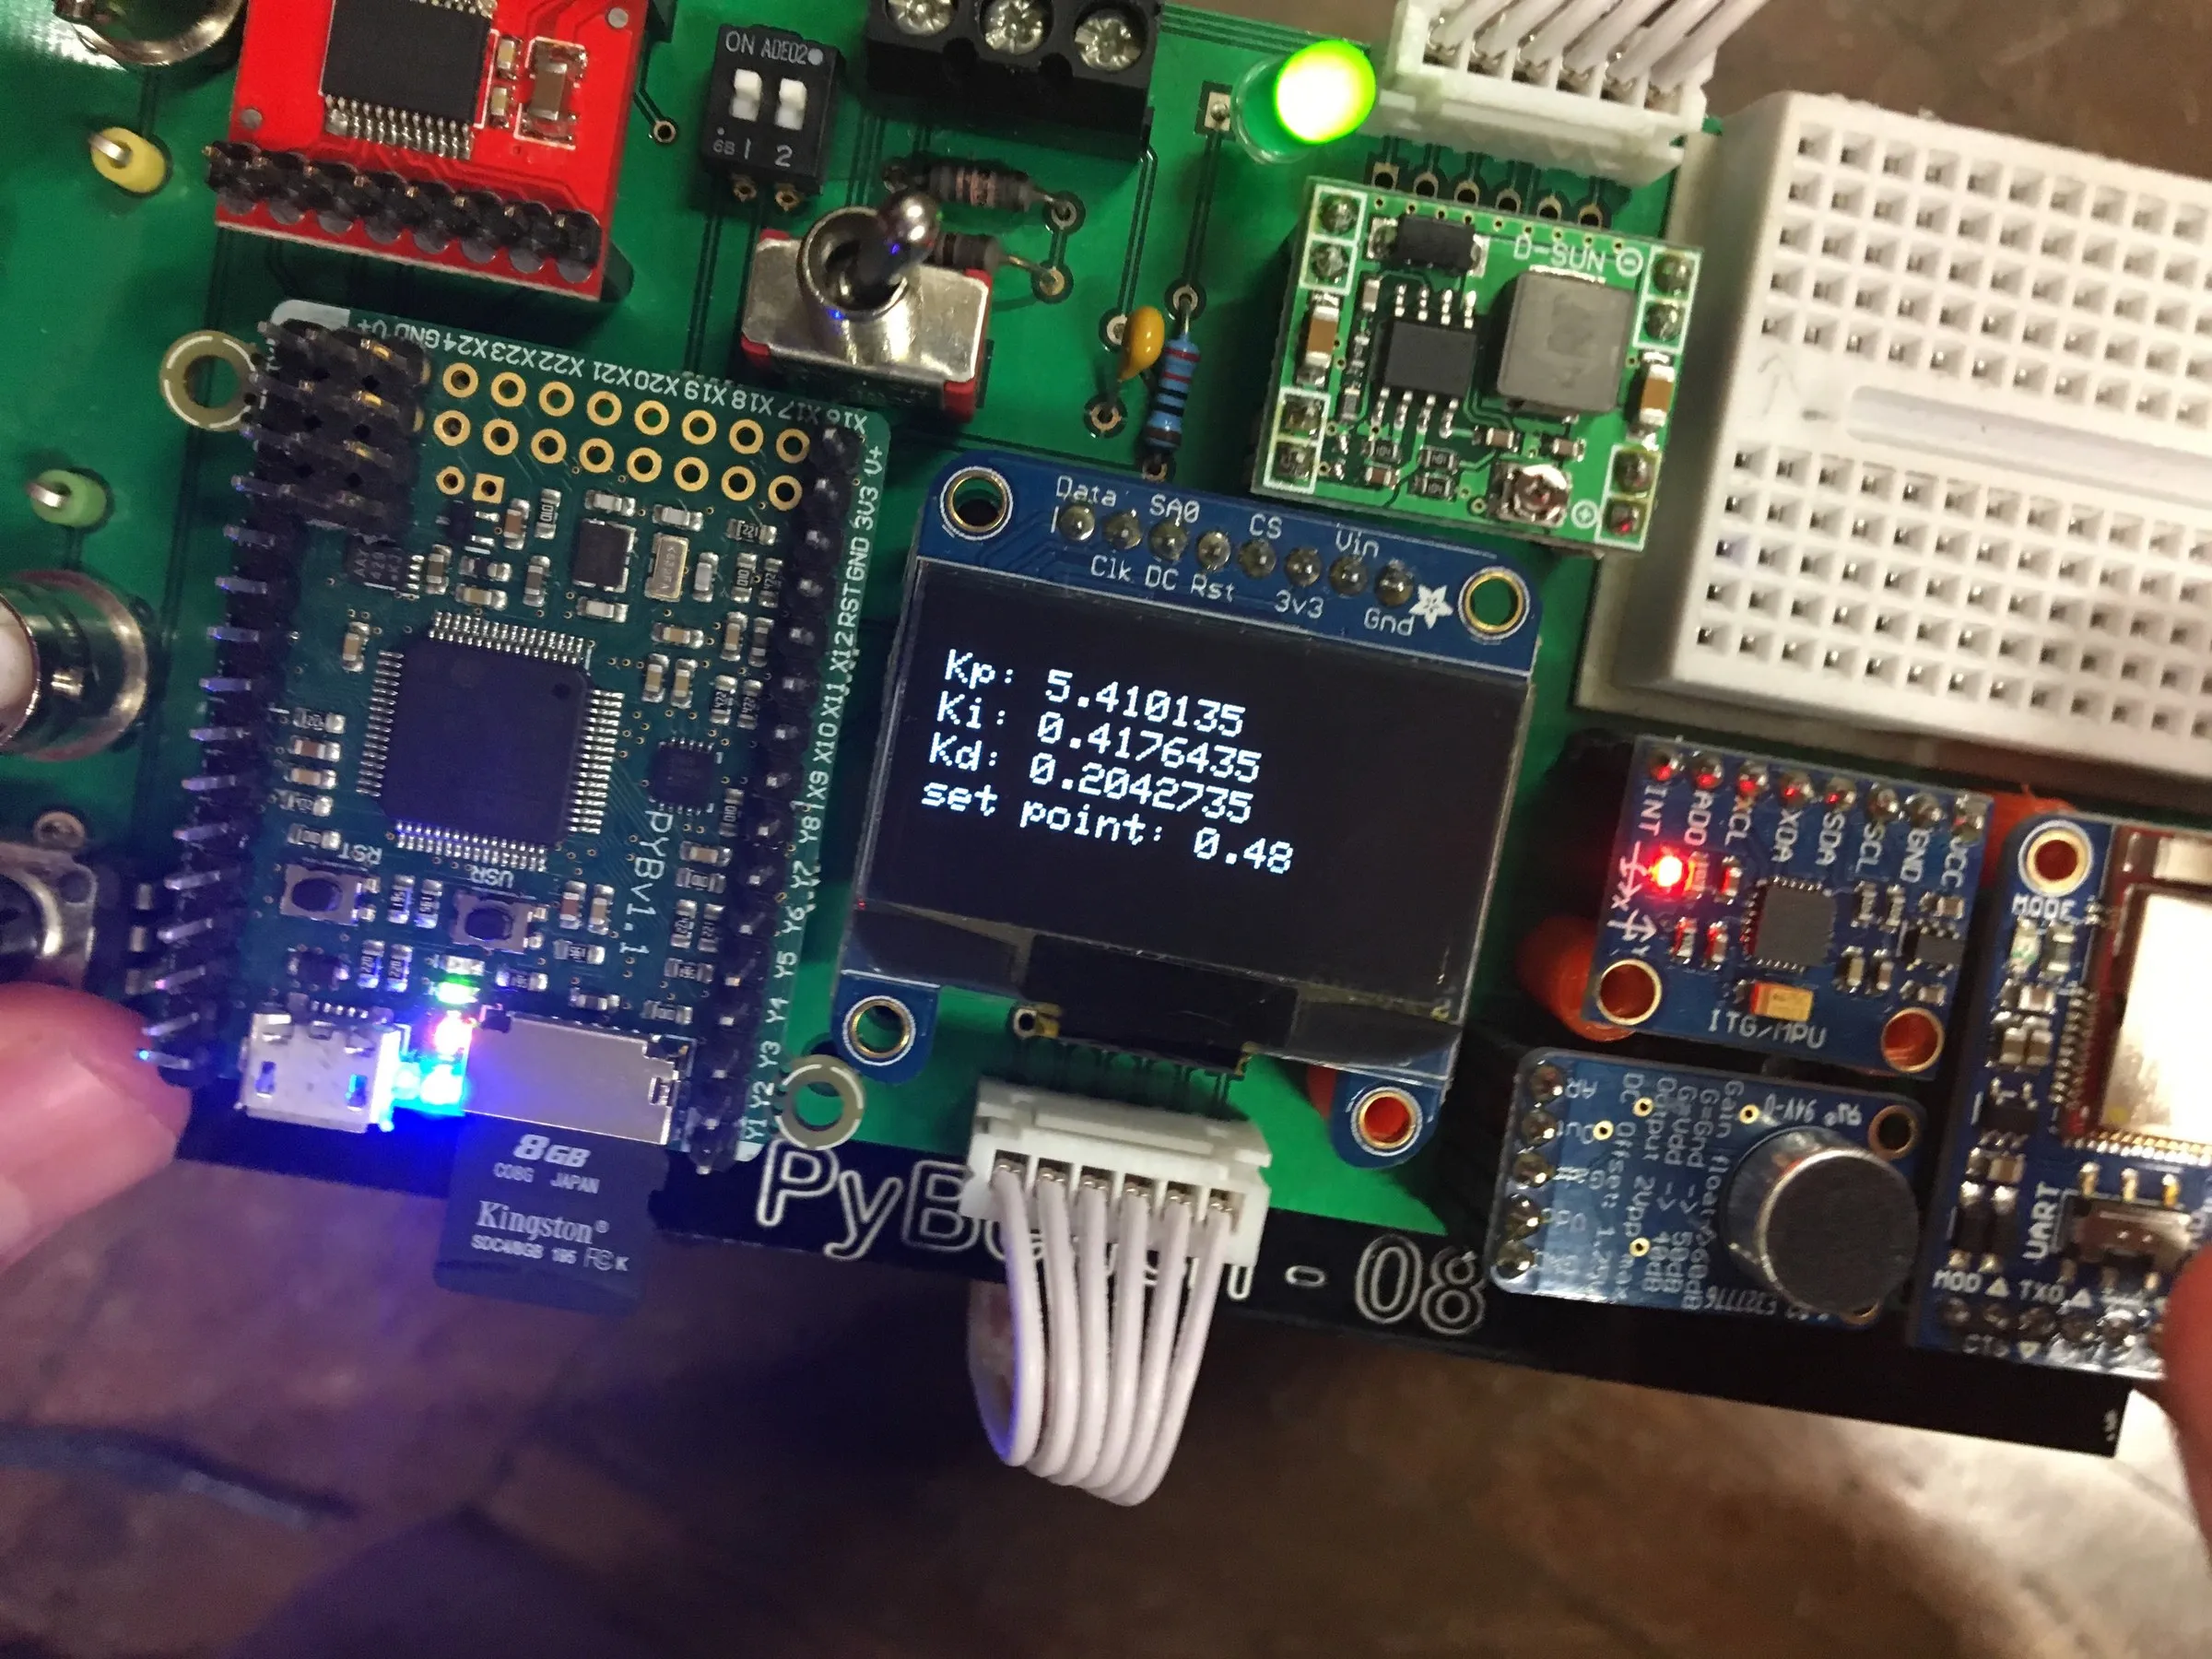
The robot needed to balance like a Segway, and dance like Elvis. Balancing was accomplished by controlling the yaw position of the robot with a PID. My teammates designed an energy-based beat detection algorithm. We combined the two to make a simple dance routine.
My Role:
I was responsible for balancing the robot. This required implementing a PID controller and a complementary filter to utilize both accelerator and gyro data.
Skills:
Signal Processing
Control Theory
Embedded Systems Programming